Produkte
Hauptlinien: Unitree, AgiBot, ENGINEAI — Humanoide, Vierbeiner, Radroboter und Roboterarme, neu und gebraucht. Gelenkmotoren, Gelenkmodule und geschickte Hände sind auch für Teams verfügbar, die eigene Roboter bauen.
Preise werden auf Anfrage bestätigt — fordern Sie ein Angebot an, und wir bestätigen Preis, Bestand und Lieferzeit, in der Regel innerhalb von 24 Stunden. Über die hier gelisteten Modelle hinaus können wir auch jeden anderen in China hergestellten Roboter liefern: Wenn Sie ein Modell suchen, sagen Sie uns Bescheid, und wir prüfen es für Sie.
Hinweis für US-Besucher: Für die USA bieten wir nur die für diesen Markt freigegebenen Modelle an — fragen Sie uns nach der US-Version dieser Liste.
Welchen Typ brauchen Sie?
Humanoide Roboter
Wählen Sie einen Humanoiden, wenn Menschen im Mittelpunkt stehen: Forschung zu zweibeiniger Fortbewegung und Manipulation, Unterricht, Demonstrationen, Empfang und Events. Wenn Ihr Team ihn programmieren muss, prüfen Sie zuerst die Zeile Entwicklung und SDK auf der Modellseite.
Vierbeinige Roboter
Wählen Sie einen Vierbeiner, wenn der Boden das Problem ist — Treppen, Kies, Gras und zerbrochene Oberflächen — für Inspektionsarbeit, Forschung und Feldrobotik.
Rad- und Rad-Bein-Roboter
Wählen Sie Rad-Beine, wenn Ihr Gelände überwiegend Böden, Höfe und Gehwege sind, aber Stufen oder Rampen hat: schneller und ausdauernder auf hartem Boden, und er überwindet weiterhin Hindernisse.
Teile & geschickte Hände
Bauen Sie Ihren eigenen Roboter? Beginnen Sie mit Gelenkmotoren, Gelenkmodulen und geschickten Händen, kalkuliert pro Spezifikation — und fragen Sie uns nach passenden Armen, Akkus und Steuerungen.
Humanoide Roboter
Zweibeinige Humanoide für Forschung, Bildung, Ausstellungen und Events — neu und gebraucht. Wichtige technische Daten aus dem vollständigen Katalog unten; fragen Sie uns nach der Version, die zu Ihrem Projekt passt.
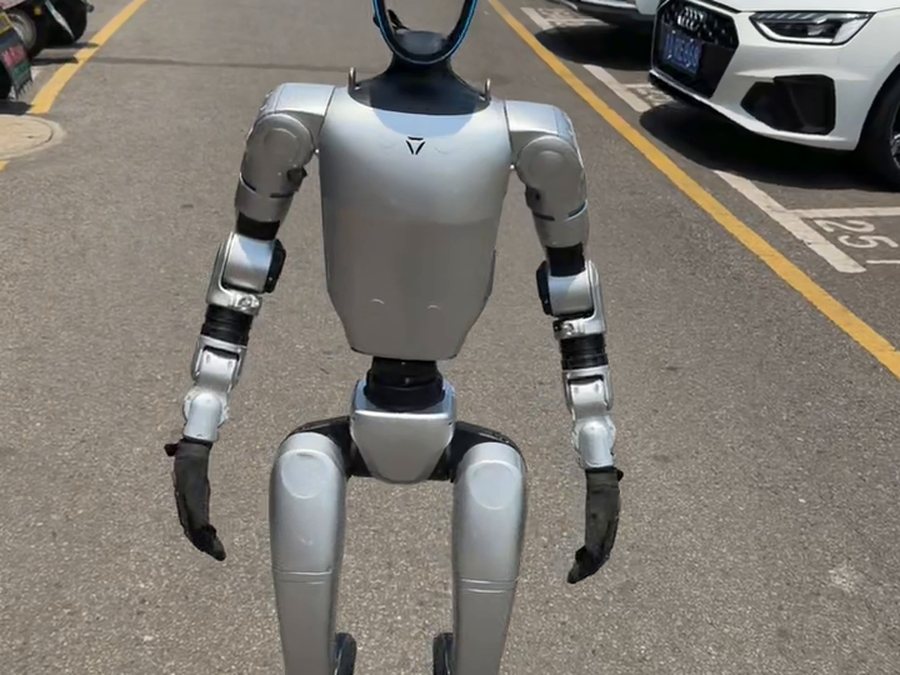
Humanoide Roboter sind der sich am schnellsten bewegende Teil unseres Katalogs — zweibeinige Plattformen in voller Größe und kompakt für Labore, die eine Entwicklungsplattform brauchen, Schulen, die einen Lehrroboter brauchen, und Eventteams, die einen Publikumsmagneten brauchen. Die meisten Modelle können neu oder gebraucht geliefert werden; nennen Sie uns die Aufgabe des Roboters, und wir verweisen Sie auf die passenden Versionen, mit den Spezifikationsunterschieden im Klartext.
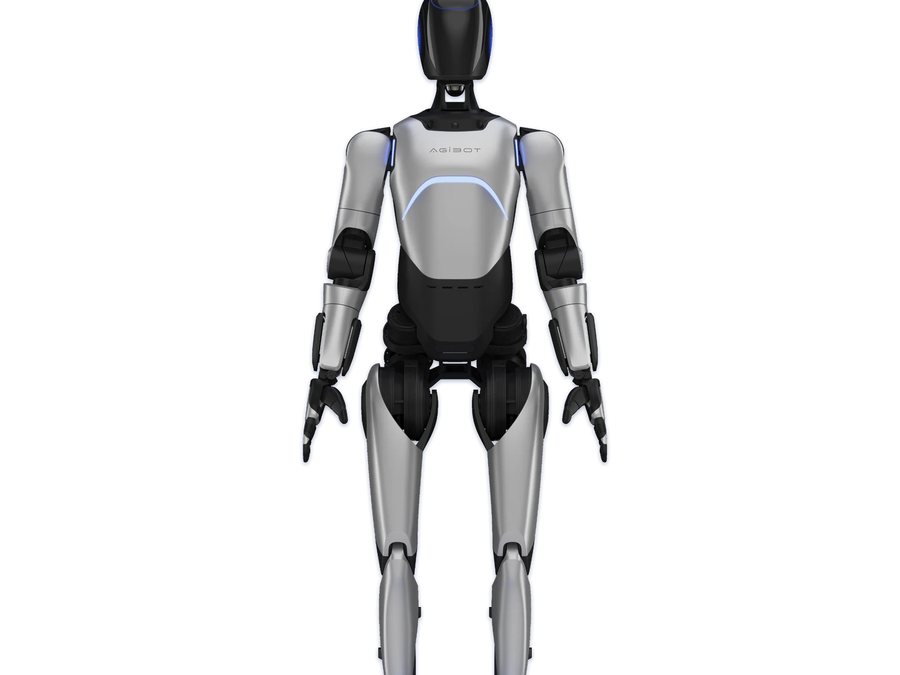
AgiBot A2
Young Edition / Flagship · Neu
- Größe169cm (169×75×30cm)
- Gewicht63 kg
- DOF23
- Nutzlast~2 kg per arm
- Akku / LaufzeitBattery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet)
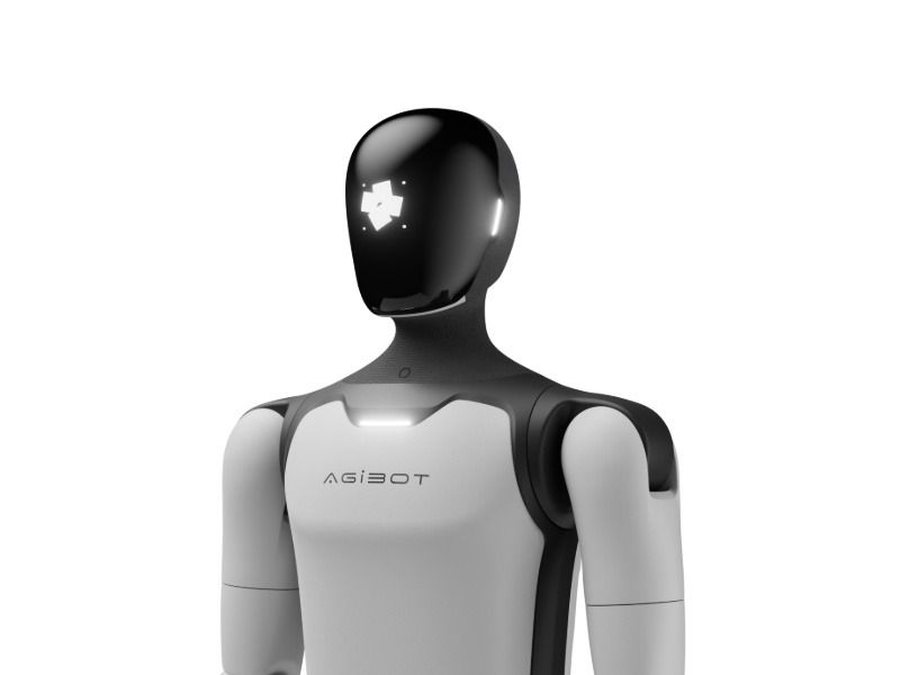
AgiBot A3
Basic Version / Development version · Neu
- Größe173cm (173×52×30cm)
- Gewicht55 kg
- DOF31 (active DOF)
- Nutzlast5 kg per arm
- Akku / Laufzeit1152Wh dual battery; up to ~10 h in typical use (10-second battery swap)
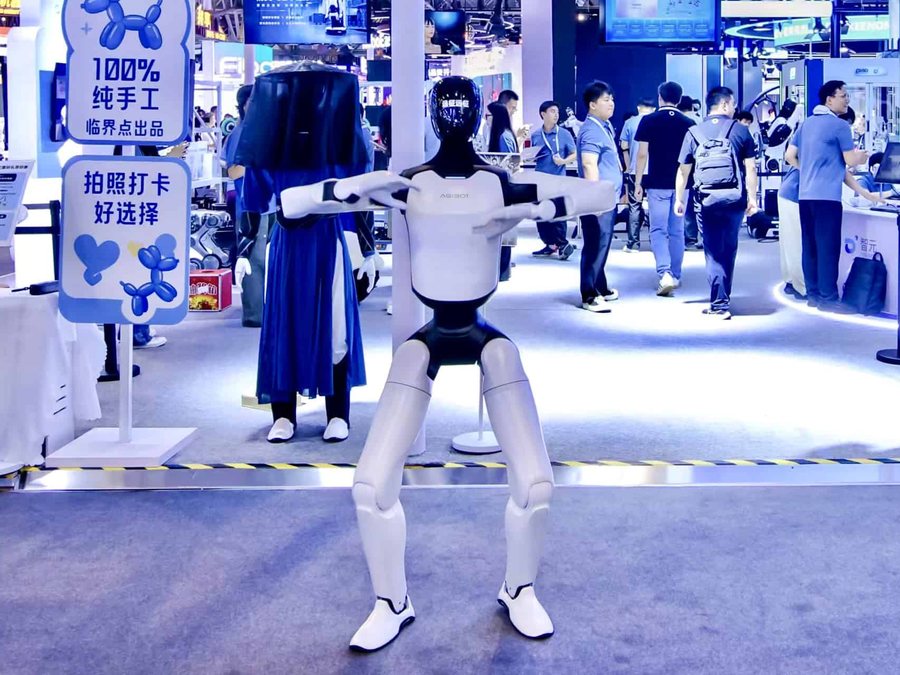
AgiBot A3 Ultra
Basic Version / Development version / Embodied version / EDU · Neu
- Größe174cm (174×52×30cm)
- Gewicht60 kg
- DOF51 (active DOF)
- Nutzlast5 kg per arm
- Akku / Laufzeit1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap)
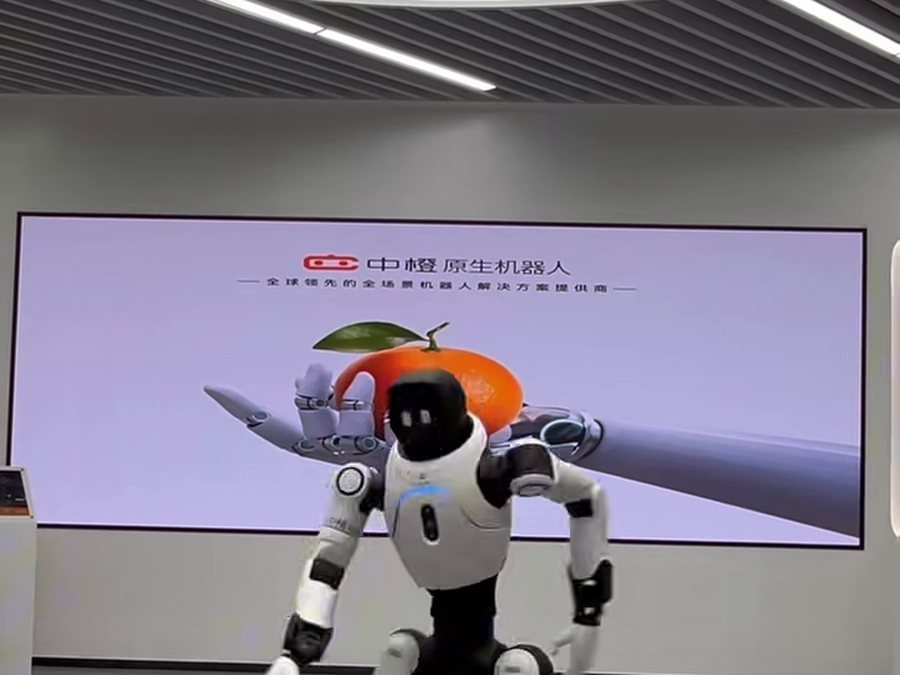
AgiBot X2
Basic Version / Ultra · Gebraucht & neu
- Größe131cm (131×46×21cm)
- Gewicht35 kg
- DOF25
- Nutzlast~3 kg in specific postures; ≤1 kg across full workspace
- Akku / Laufzeit~500Wh; ~2 h continuous walking (at 0.5 m/s)
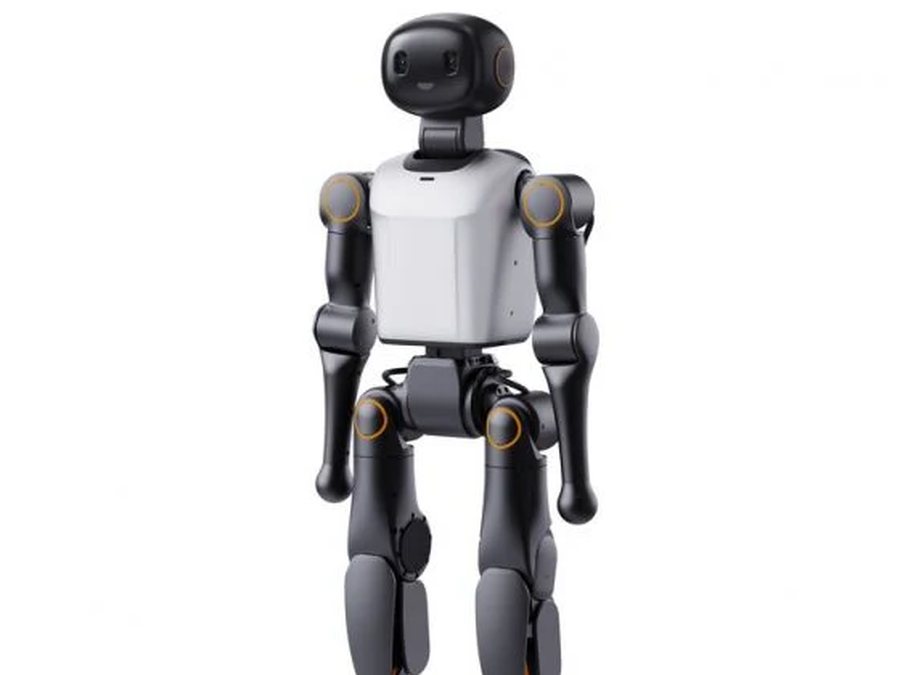
Booster K1
Geek / Education / Professional · Neu
- Größe~95cm
- Gewicht19.5 kg
- DOF22
- Akku / Laufzeit2Ah; ~20 min (official figure, walking at 1.1 m/s)
- Max. Geschwindigkeit2 m/s (walking speed per official site)
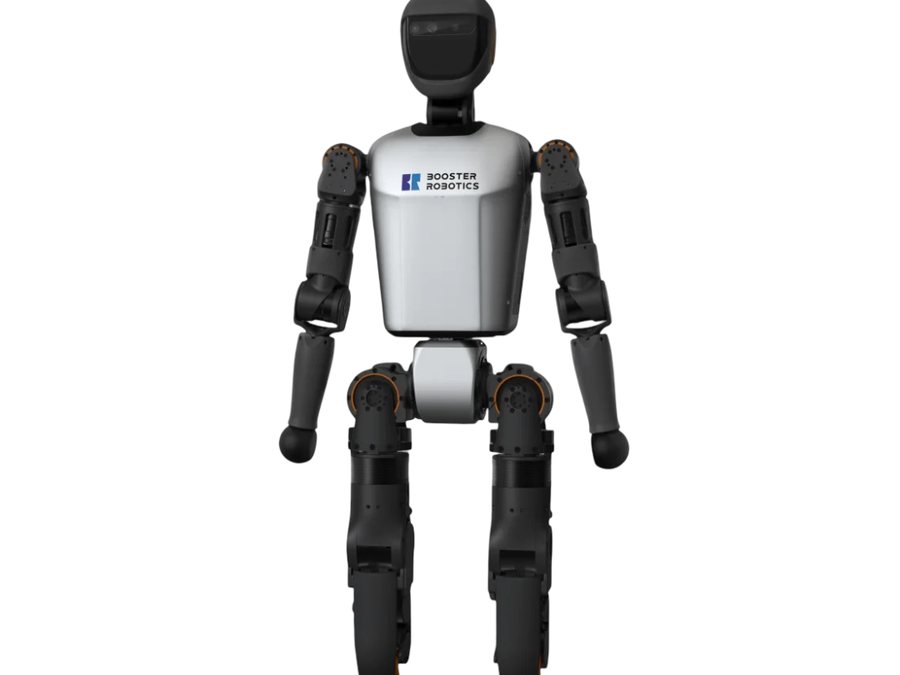
Booster T1
Basic / Standard / Customized · Neu
- Größe118cm (118×47×23cm)
- Gewicht30 kg
- DOF23
- Akku / Laufzeit10.5Ah battery; ~2 h walking, ~4 h standing
- Max. Geschwindigkeit0.5 m/s (walking speed per manual; top speed not published)
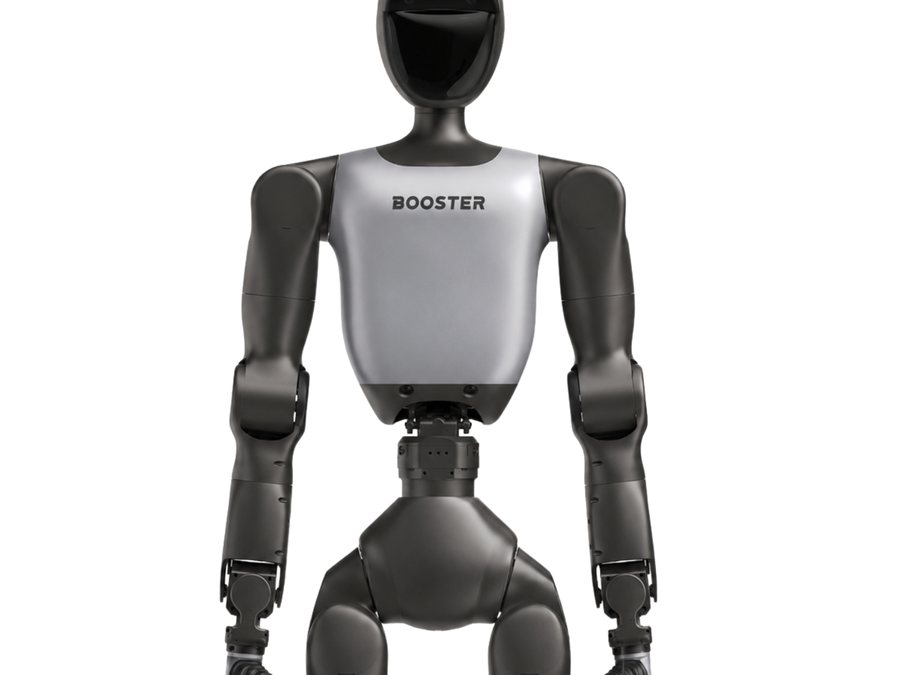
Booster T2
P1 / P2 Claw / P3 Nimble Hands · Neu
- Größe140cm
- Gewicht~42 kg
- DOF31
- NutzlastMax 10 kg both arms (base configuration, no end effector)
- Akku / Laufzeit48V 10Ah; ~2 h continuous walking
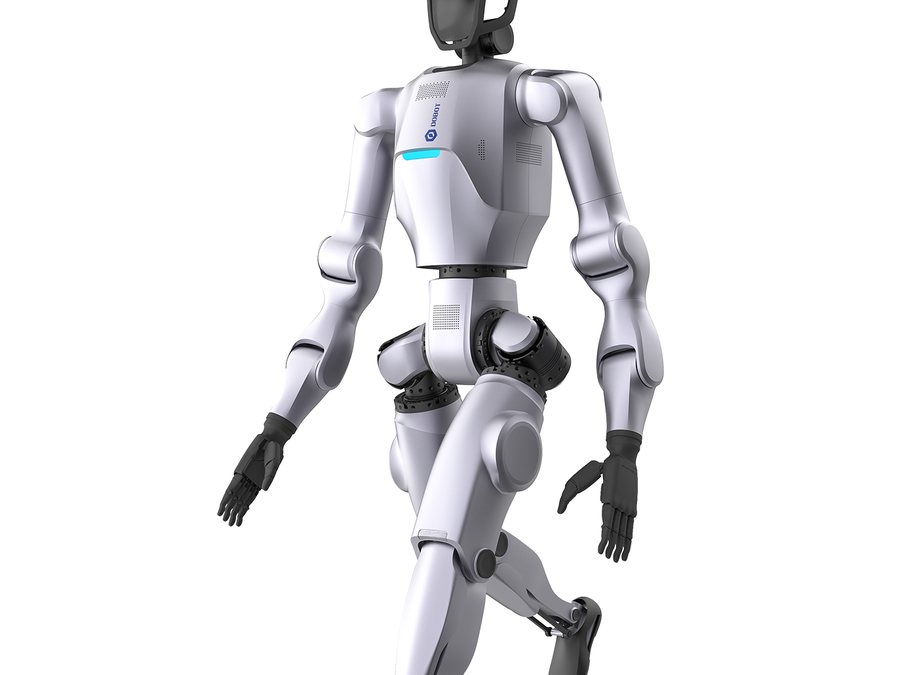
Dobot Atom
Base · Neu
- GrößeHeight ~1530mm
- Gewicht62 kg
- DOF41 (incl. dexterous hands; 29 without hands)
- Nutzlast3.5 kg per arm
- Akku / Laufzeit~2 h
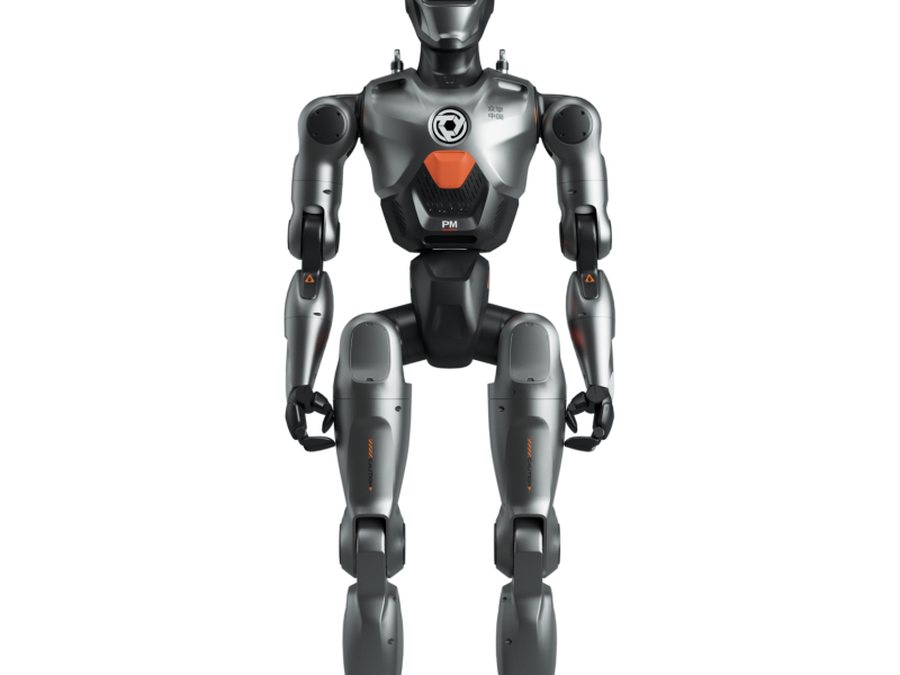
EngineAi PM01
Commercial / Education · Gebraucht
- Größe138cm (manual: 1388×490×220 mm)
- Gewicht~40 (manual spec table ~43 incl. battery — sources differ)
- DOF23 (manufacturer headline says 24-DOF)
- Akku / Laufzeit~2 h (10,000mAh quick-release battery)
- Max. Geschwindigkeit2m/s
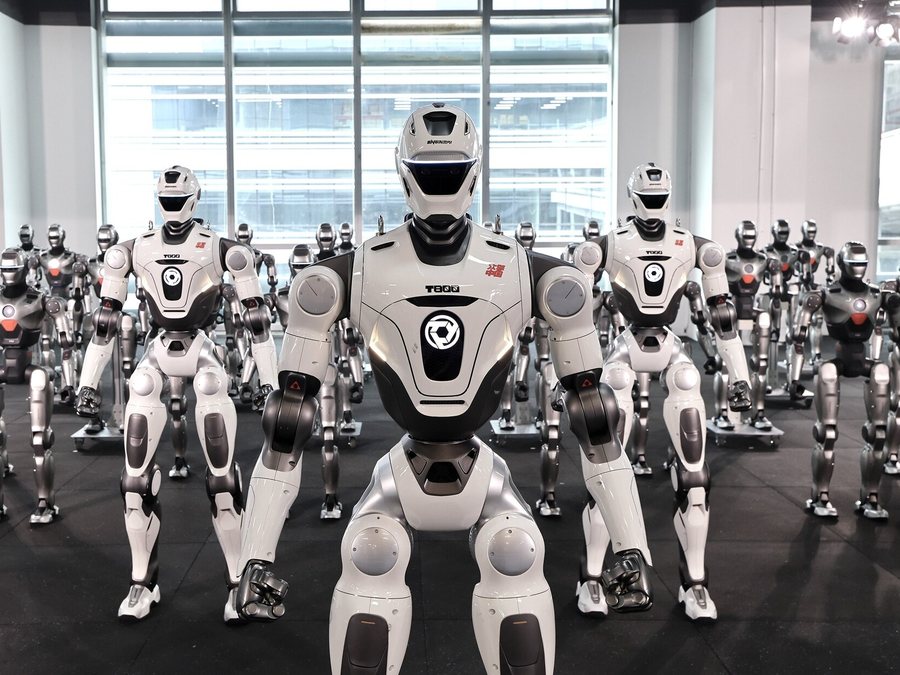
EngineAi T800
Base / Education / Pro · Neu
- Größe173cm (legs 91 cm, arms 60 cm)
- Gewicht75 (incl. battery, per launch materials)
- DOF25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands)
- Akku / Laufzeit4–5 h (solid-state battery, per manufacturer launch)
- Max. Geschwindigkeit≥3 m/s (hardware-capable)
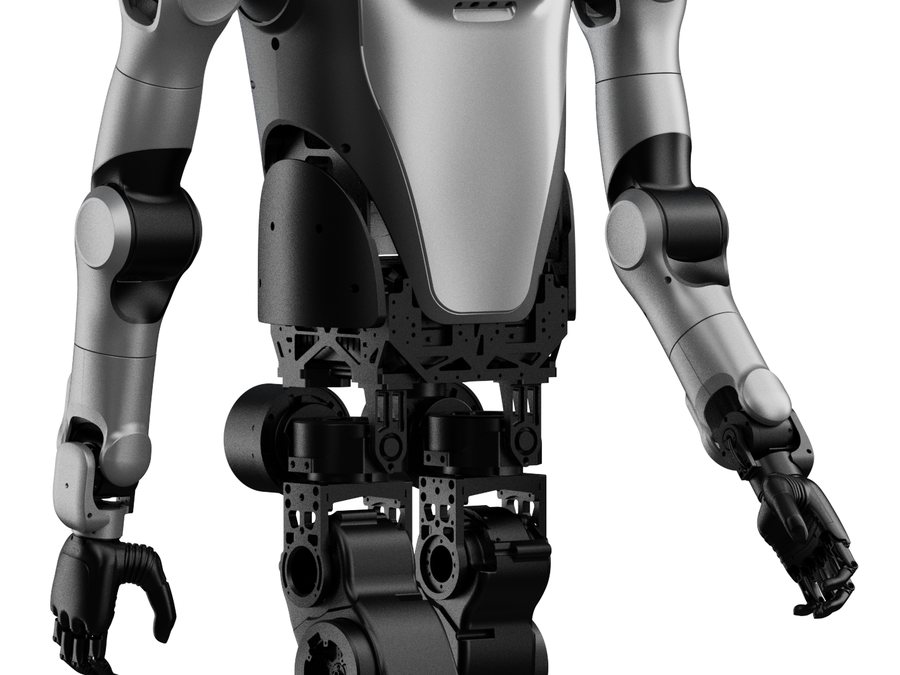
Leju Robotics Kuavo 4Pro
Base · Neu
- GrößeHeight ~1660mm
- Gewicht55 kg
- DOF40+
- Max. Geschwindigkeit>7 km/h (running)
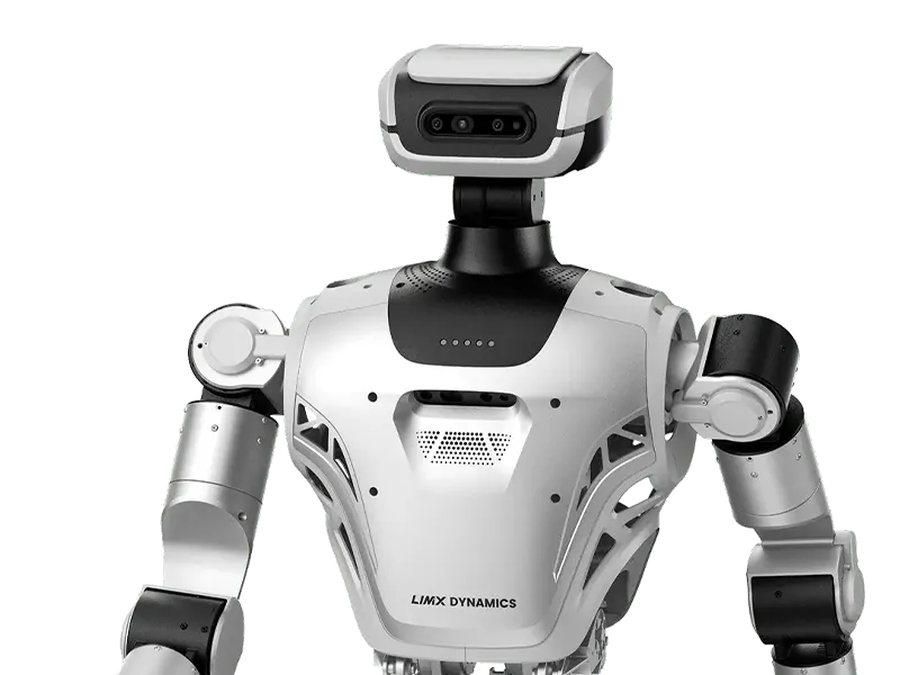
LimX Dynamics Oli
Lite / Edu / Super · Neu
- Größe165cm (shoulder width ≈55 cm, arm length ≈70 cm)
- Gewicht≤55 (incl. battery)
- DOF31 (body only, excl. end effectors)
- Akku / Laufzeit~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery)
- Max. GeschwindigkeitMax walking speed 5 km/h
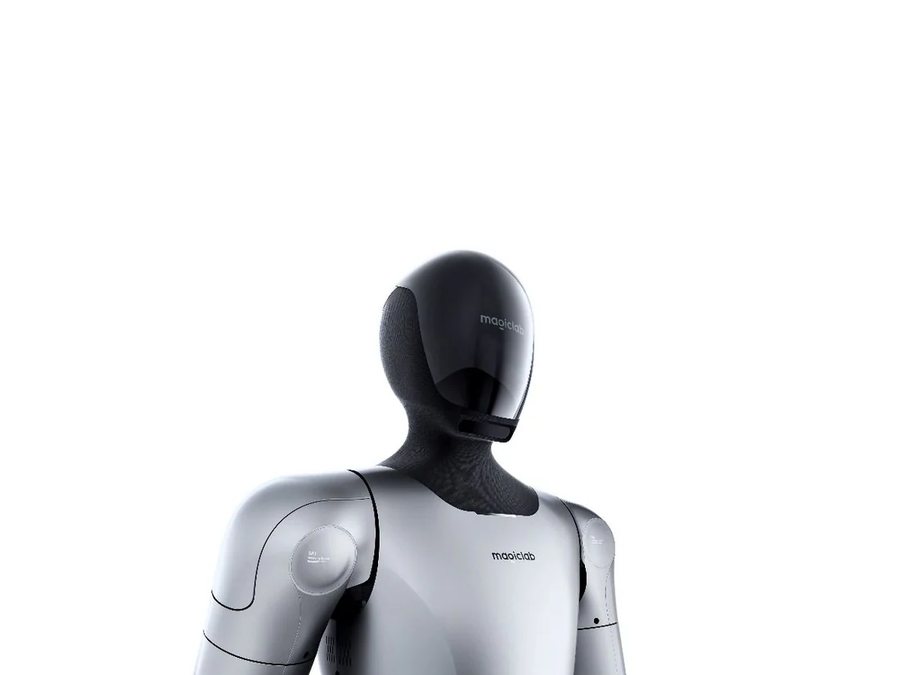
MagicBot Gen1
Base · Neu
- Größe1740×580×280mm (174cm)
- Gewicht~70 kg
- DOF42 (active DOF)
- Nutzlast7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg)
- Akku / Laufzeit3–5 h (25Ah / 1.35kWh battery)
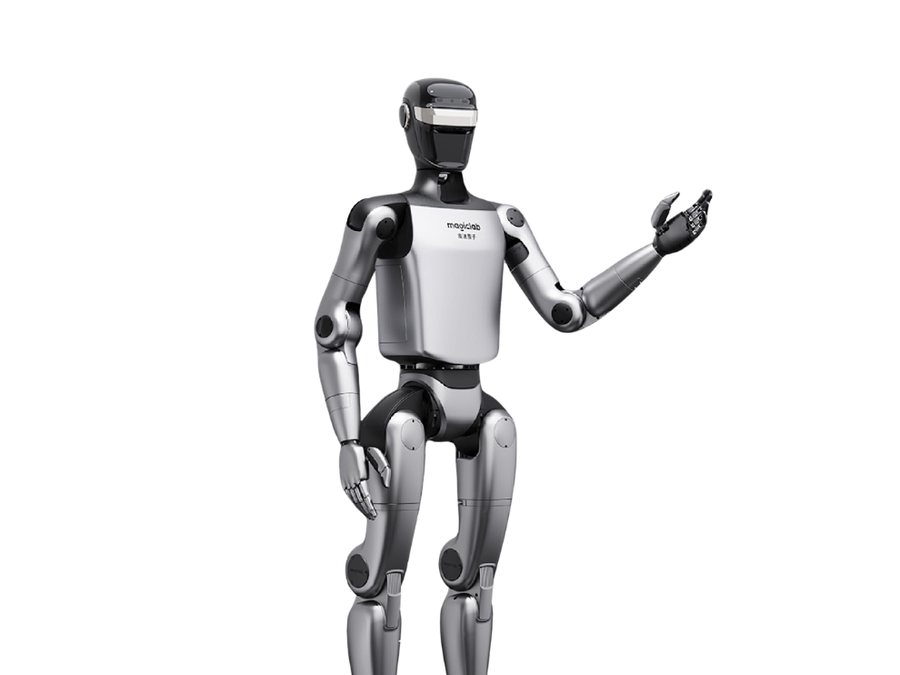
MagicBot Z1
Base · Neu
- Größe~140cm (Developer version 136.9 cm, 1369×422×200 mm)
- Gewicht~40 (incl. battery)
- DOF24 (base; expandable to 49/50 per different sources)
- NutzlastMax 3 kg per arm
- Akku / Laufzeit~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual)
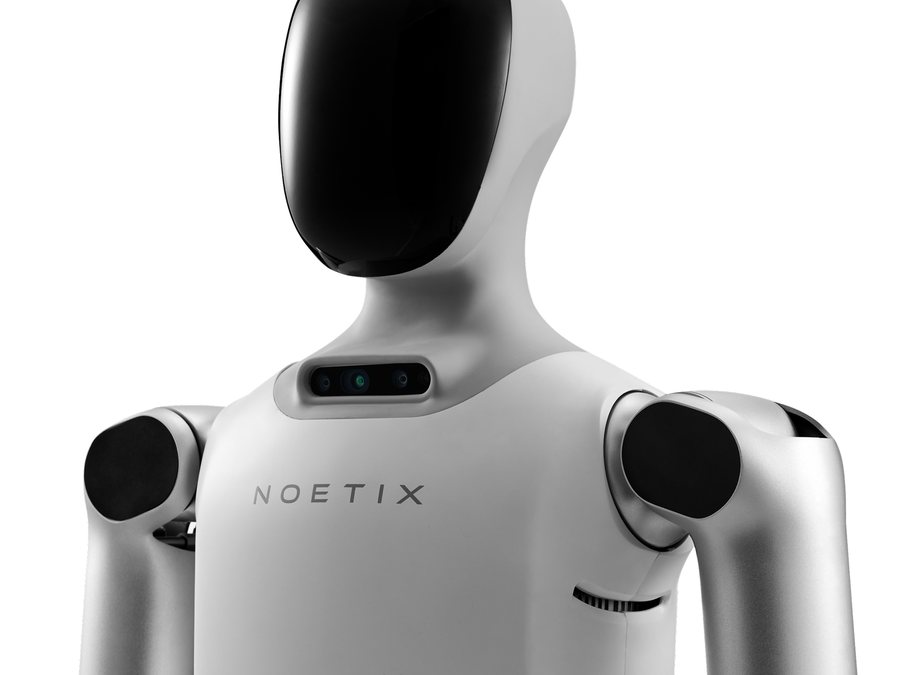
Noteix E1
Standard / Edu · Gebraucht
- Größe136×47×29cm
- Gewicht~36 kg
- DOF23 (manufacturer manual) / 21 (press release) — sources conflict
- Akku / Laufzeit1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict
- Max. GeschwindigkeitWalking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence)
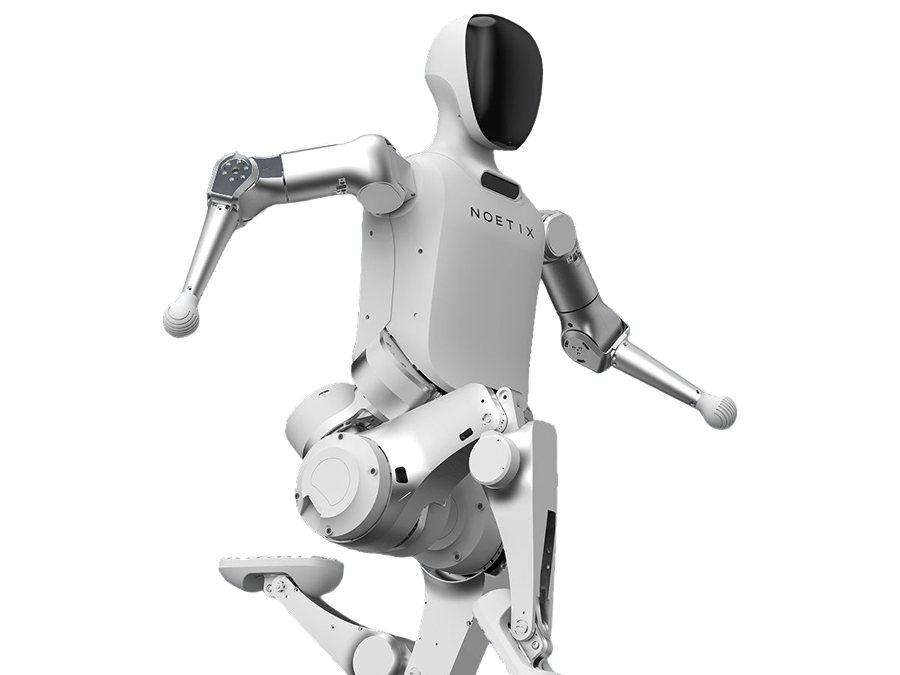
Noteix N2
Standard / Edu · Gebraucht
- Größe118 cm H × 47 cm W
- Gewicht~30 (another compilation lists 29)
- DOF18
- Nutzlast~5 (carried while walking continuously)
- Akku / Laufzeit1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min)
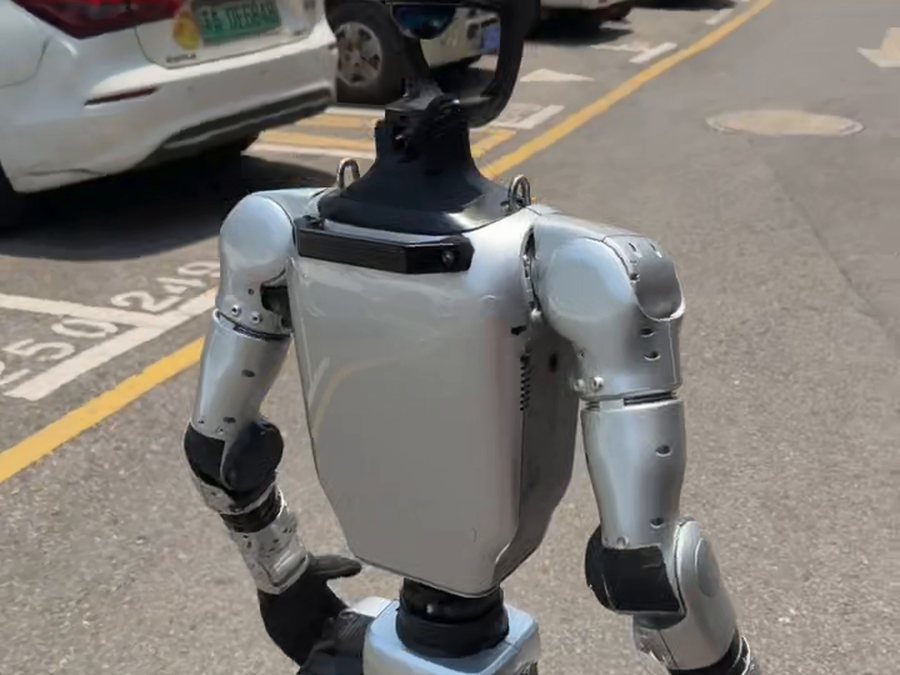
Unitree G1
Basic / U1 / U2 · Gebraucht
- Größe1320×450×200mm (Standing )
- Gewicht35 kg
- DOF23
- Nutzlast~2 (per arm)
- Akku / Laufzeit~2 h
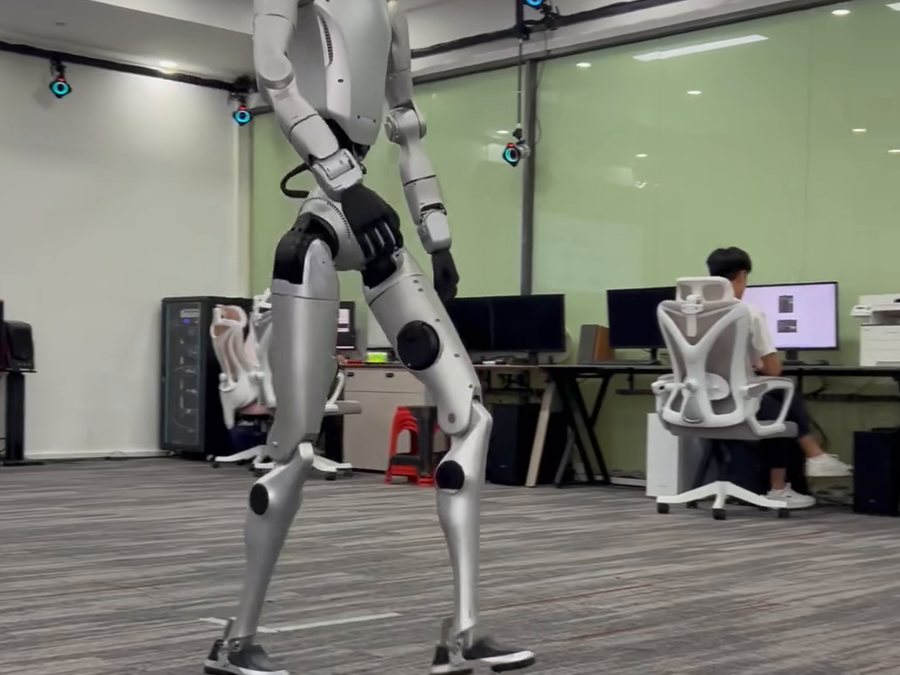
Vierbeinige Roboter
Vierbeinige Plattformen für Forschung, Inspektionspraxis, Bildung und Demonstrationen — neu und gebraucht.
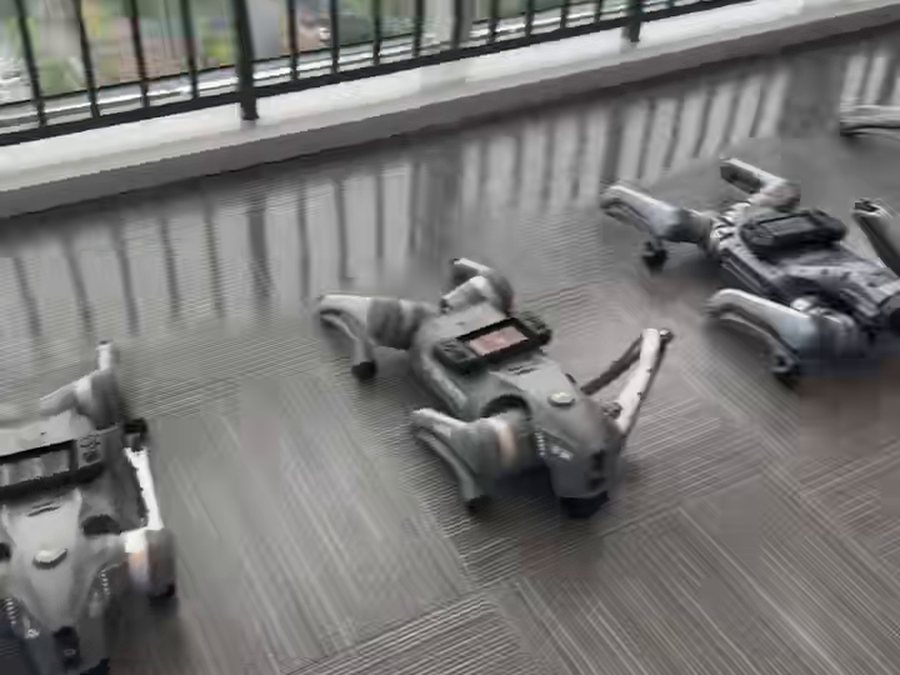
Vierbeinige Roboter bewähren sich dort, wo Räder nicht hinkommen: Treppen, Kies, Gras und zerbrochenes Gelände. Unsere Vierbeiner-Palette reicht von kompakten Bildungsplattformen bis zu industriellen Inspektionsmaschinen, neu und gebraucht. Wenn Sie nicht sicher sind, welche Größenklasse Sie brauchen, nennen Sie uns Gelände und Nutzlast — das entscheidet.
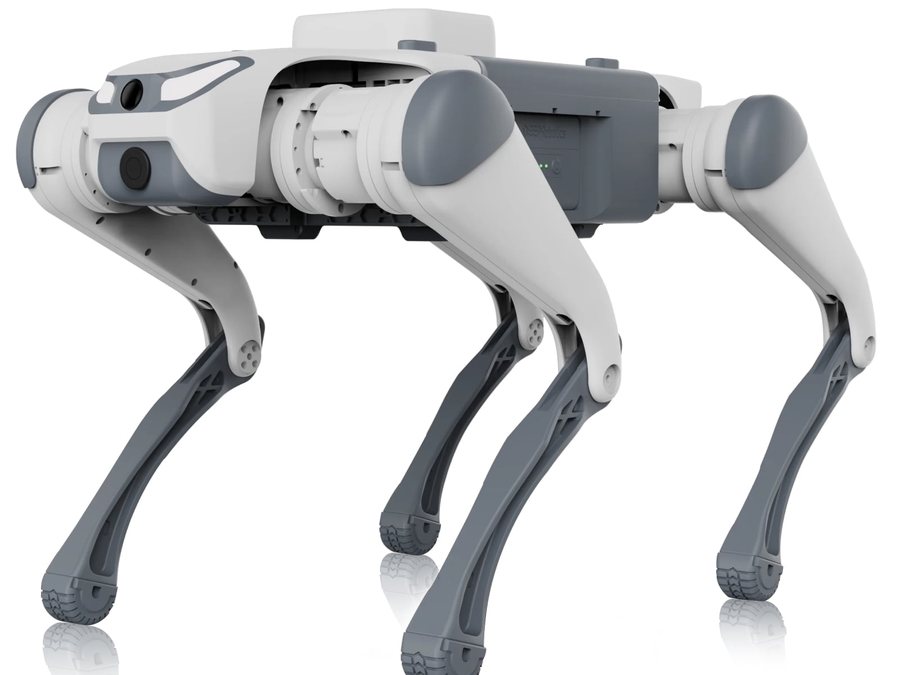
Deep Robotics Lite3
Basic / Venture / Pro / LiDAR · Gebraucht & neu
- GrößeStanding 610×370×406mm
- Gewicht12 kg
- DOF12
- NutzlastWalking payload 5
- Akku / Laufzeit1.5–2 h
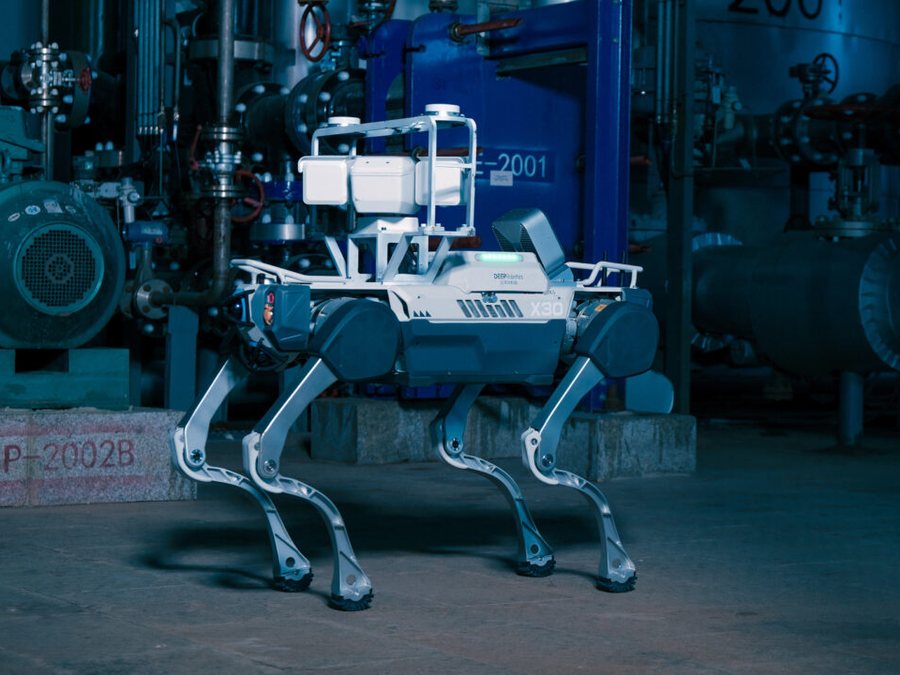
Deep Robotics X30
Basic / Pro · Gebraucht
- GrößeStanding 1000×585×470mm
- Gewicht56 kg
- DOF12
- NutzlastRated payload ≥20 (max 85)
- Akku / Laufzeit2.5–4 h
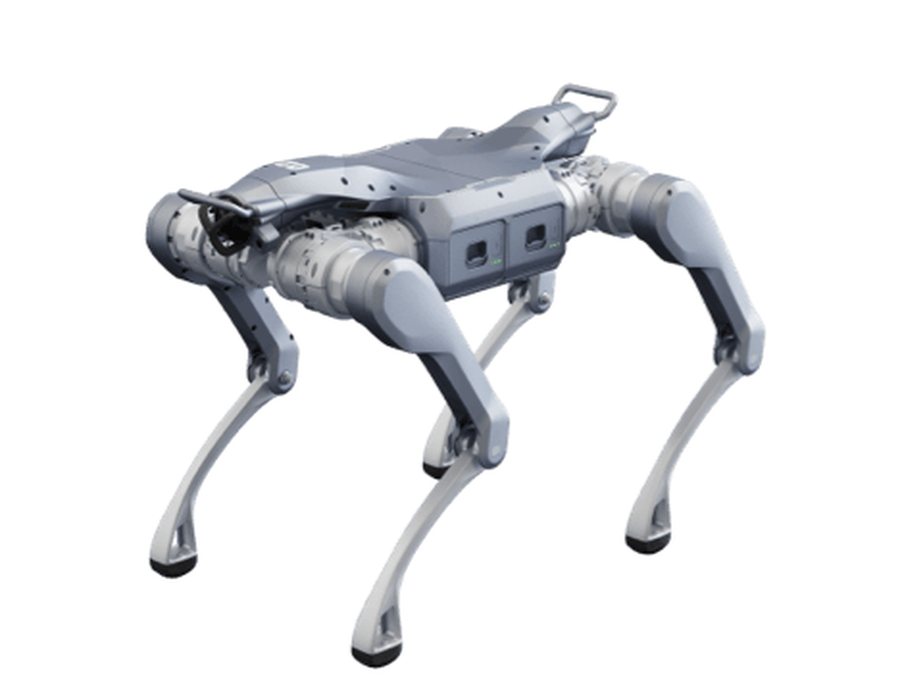
Unitree A2
Base · Neu
- Größe820×440×570mm
- Gewicht~37 (incl. dual batteries)
- DOF12
- Nutzlast~25 (walking; standing max ~100)
- Akku / Laufzeit~5 h unloaded / ~3 h with 25 kg payload
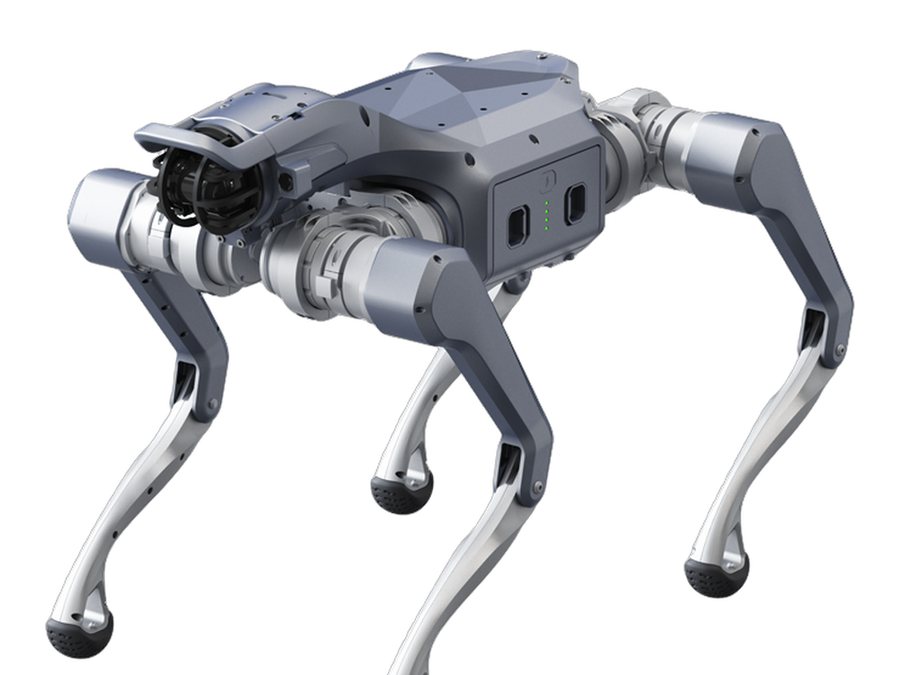
Unitree As2
EDU U1 / EDU U2 / EDU U3 / EDU U4 · Neu
- Gewicht18 kg
- DOF12
- Nutzlast~15 (walking; standing max ~65)
- Akku / Laufzeit>4 h unloaded
- Max. Geschwindigkeit3.7 m/s (peak 5)
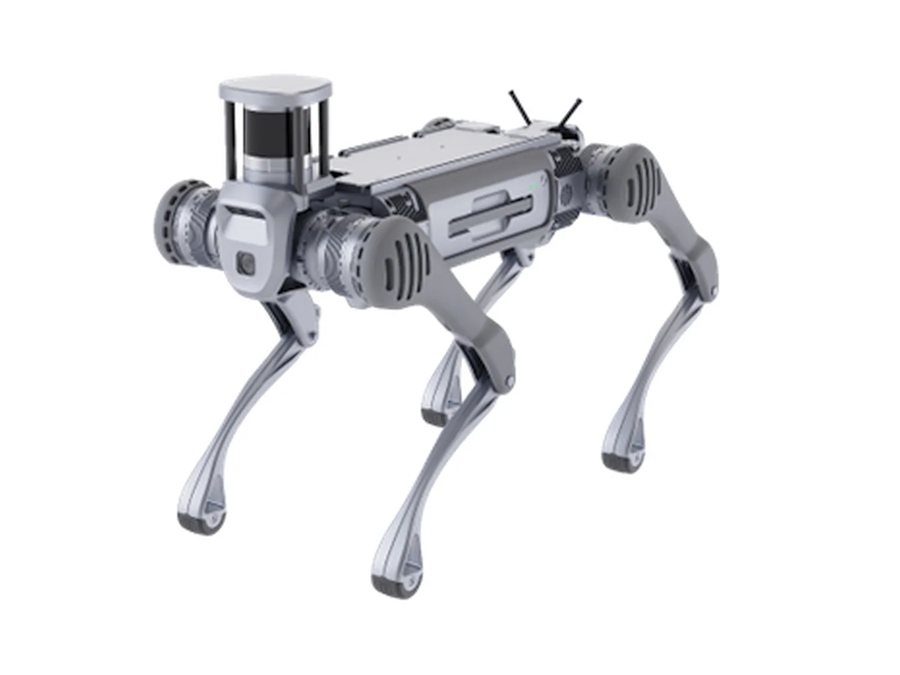
Unitree B2
Base · Gebraucht
- Größe~1098×450×645mm
- Gewicht~60 kg
- DOF12
- NutzlastWalking >40 (standing max 120)
- Akku / Laufzeit~4–6 h
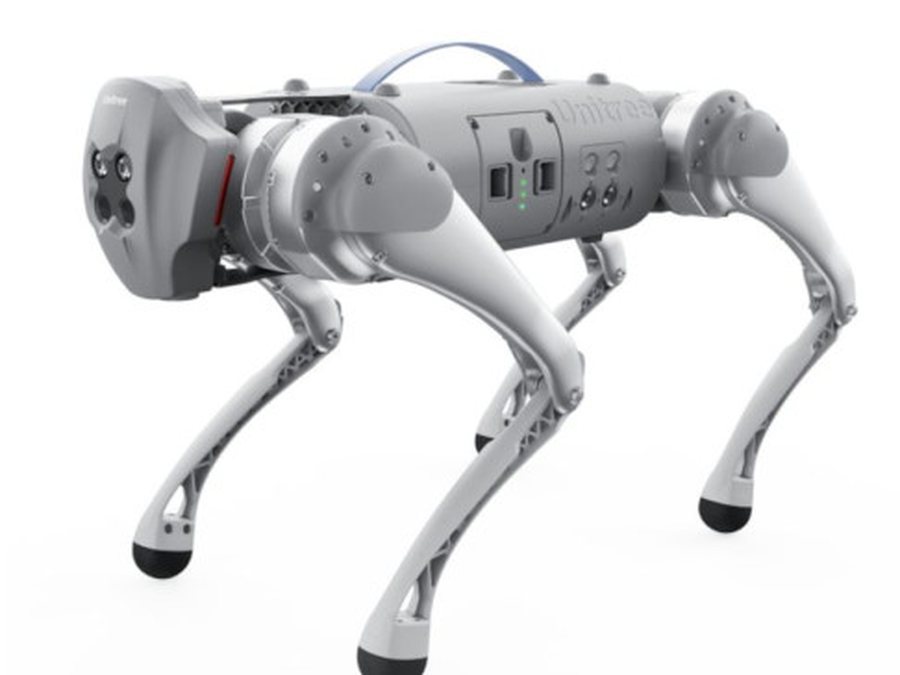
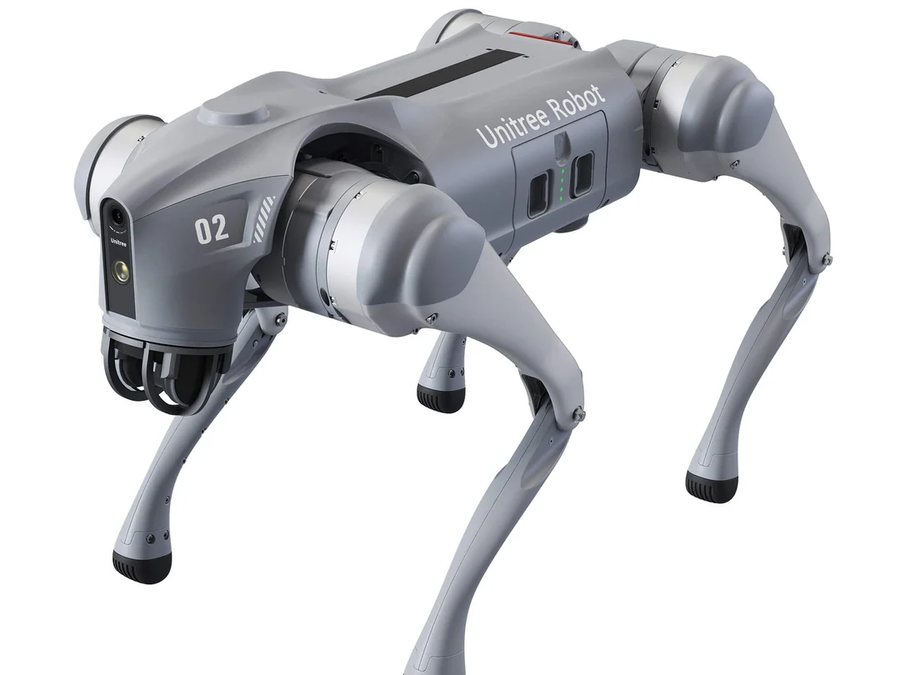
Unitree Go2 Air
Base · Gebraucht
- Größe700×310×400mm
- Gewicht15 kg
- DOF12
- Nutzlast~7 (max ~10)
- Akku / Laufzeit~1–2 h
Unitree Go2 Edu
Base · Gebraucht
- Größe700×310×400mm
- Gewicht15 kg
- DOF12
- Nutzlast~8 (limit 10)
- Akku / Laufzeit~2–4 h (15,000mAh long-life battery)
Unitree Go2 Pro
Base · Gebraucht
- Größe700×310×400mm
- Gewicht15 kg
- DOF12
- Nutzlast~7 (max ~10)
- Akku / Laufzeit~1–2 h
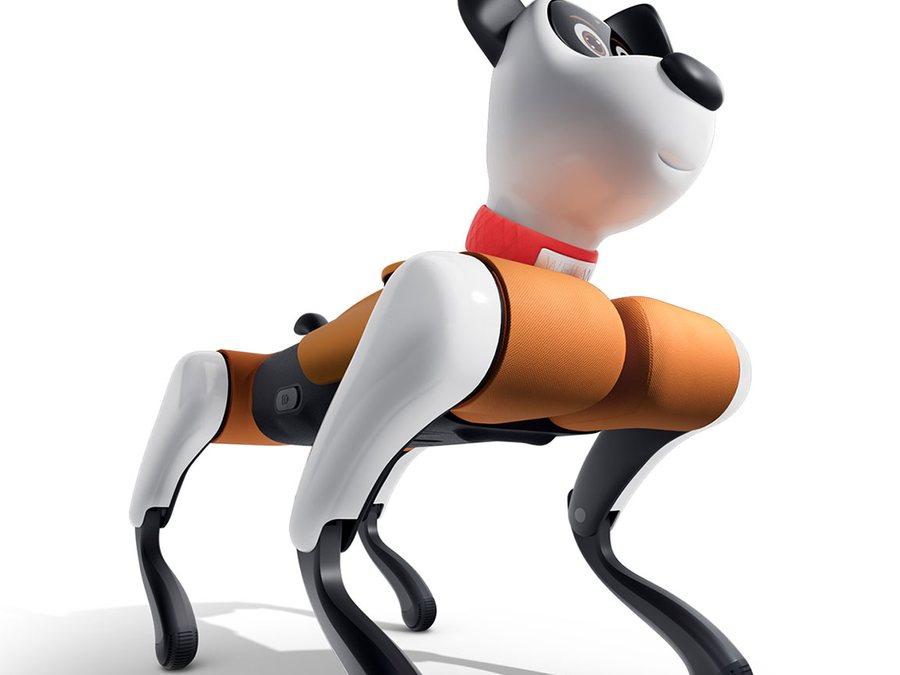
WEILAN Baby Alpha A2
Standard / Plus / Pro / Ultra · Gebraucht
- Akku / Laufzeit~120 min (media report only; not published by manufacturer)
- Max. Geschwindigkeit6.0 km/h (single media source, low–medium confidence)
Rad- und Rad-Bein-Roboter
Rad-Bein-Vierbeiner, die auf flachem Boden rollen und Hindernisse überwinden — für Innen-/Außenarbeit, wo Räder allein nicht genügen.
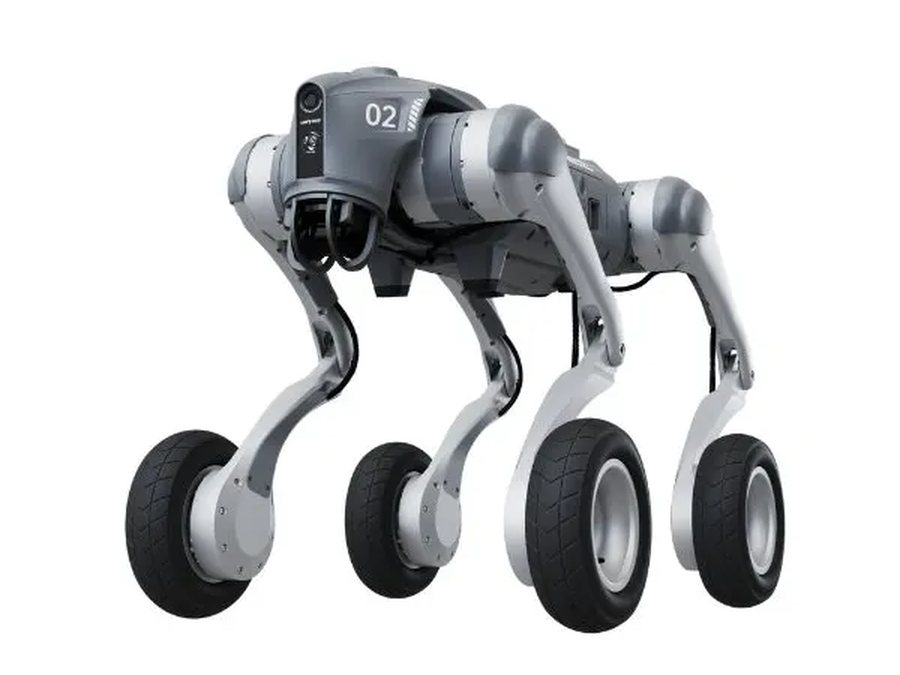
Rad- und Rad-Bein-Roboter tauschen etwas Geländegängigkeit gegen Geschwindigkeit, Ausdauer und Stabilität auf dem Boden, den die meisten Standorte tatsächlich haben — Böden, Höfe, Gehwege und Rampen. Dieser Abschnitt behandelt unsere Rad-Bein-Vierbeiner; wenn Ihr Gelände überwiegend harte Oberflächen mit der einen oder anderen Stufe oder Neigung ist, beginnen Sie hier.
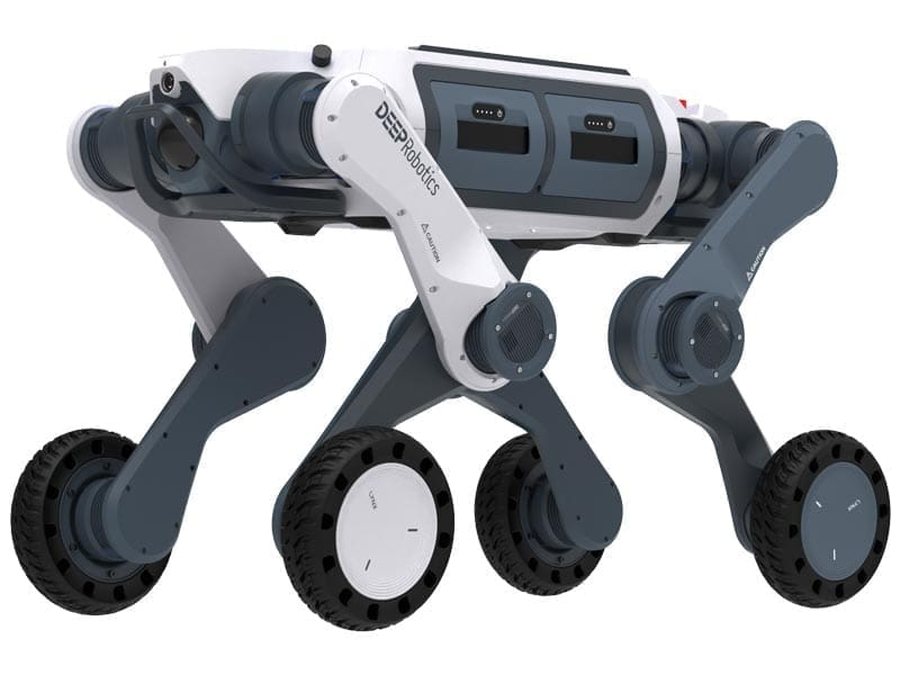
Deep Robotics M20
Basic / Pro · Neu
- GrößeStanding 820×430×570mm
- Gewicht33 kg
- DOF16
- NutzlastRated payload 15 (max 50)
- Akku / Laufzeit3 h unloaded / 2.5 h loaded
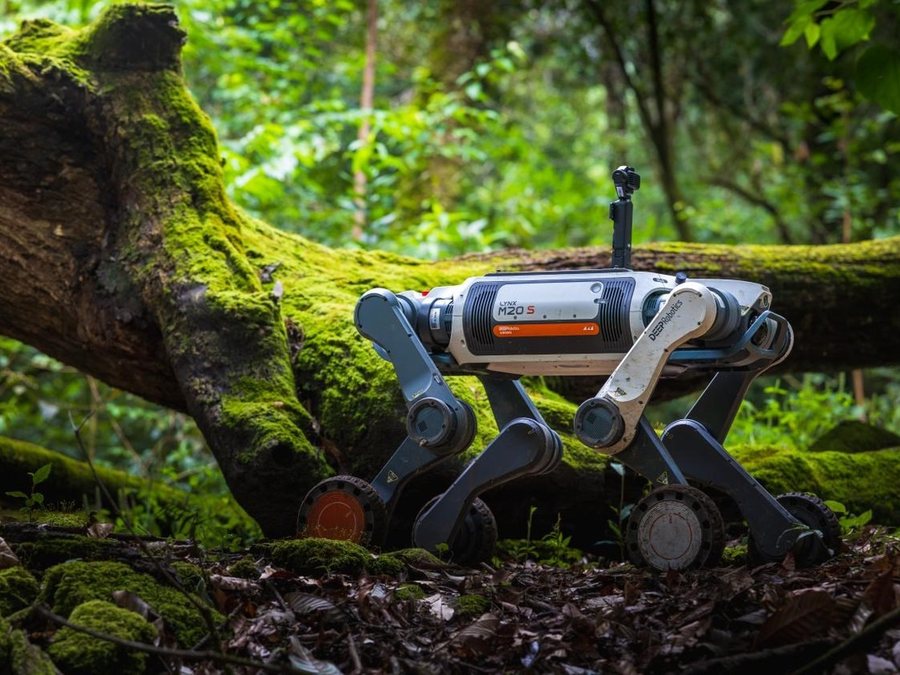
Deep Robotics M20S
New
- Gewicht33 (manufacturer states weight unchanged from M20 Pro)
- NutzlastContinuous payload 35 kg (flat terrain)
- Akku / Laufzeit3.5–5 h unloaded / 2.5–3.5 h loaded
- Max. Geschwindigkeit9 m/s
Unitree Go2-W
Standard Edition / Smart Edition / Laser Edition · Neu
- Größe700×430×500mm
- Gewicht18 kg
- DOF16 (12 leg joints + 4 hub motors)
- Nutzlast~8 (max ~12)
- Akku / Laufzeit~2–4 h
Roboterarme
Arme für humanoide und vierbeinige Forschungsplattformen, abgestimmt auf Ihren Roboter und Ihre Nutzlastanforderungen.
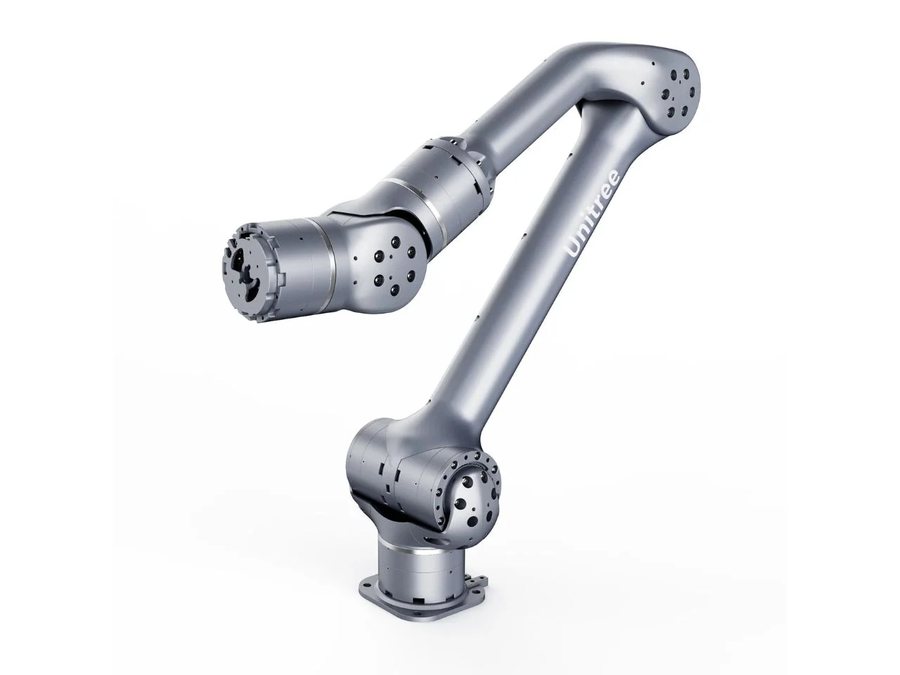
Roboterarme
Nennen Sie uns die Plattform, auf die Sie ihn montieren, und die benötigte Nutzlast — wir stimmen einen Arm ab und kalkulieren ihn pro Spezifikation, zusammen mit dem Roboter oder allein.
Gebrauchte Roboter
Gebrauchtversionen vieler Modelle oben sind auf Lager — jedes geprüft, mit Zustandsbericht und Video des tatsächlichen Geräts.
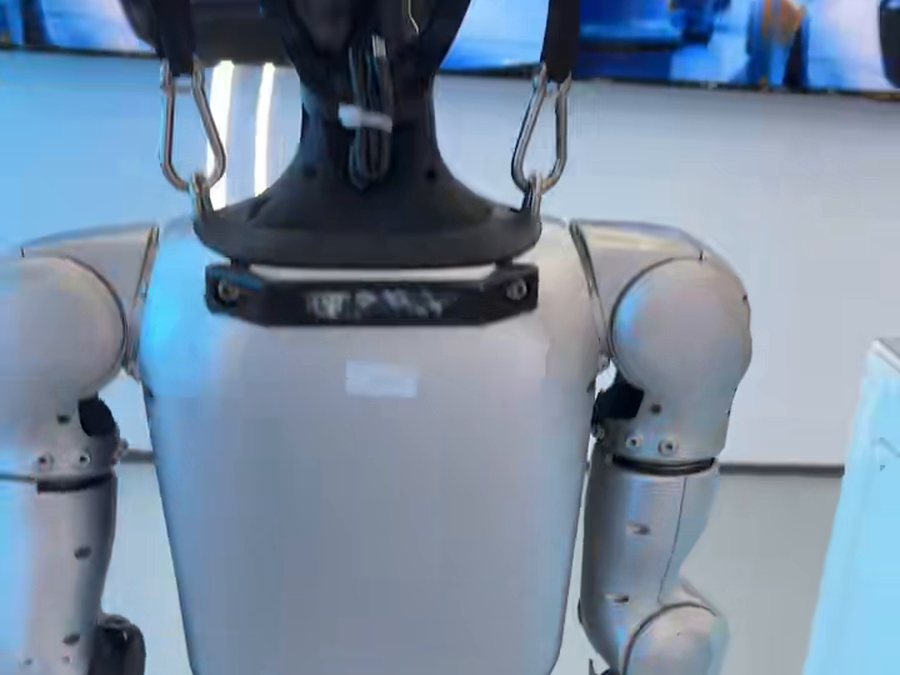
Gebrauchtbestand
Gebrauchtpreise sind ein Bruchteil des Neupreises für dasselbe Modell. Nennen Sie uns das gesuchte Modell, und wir senden Ihnen Zustandsbericht und Preis für das Gerät auf Lager.
Teile für Roboterbauer
Ein separates Sortiment für Teams, die eigene Roboter bauen — Komponenten, keine kompletten Maschinen.
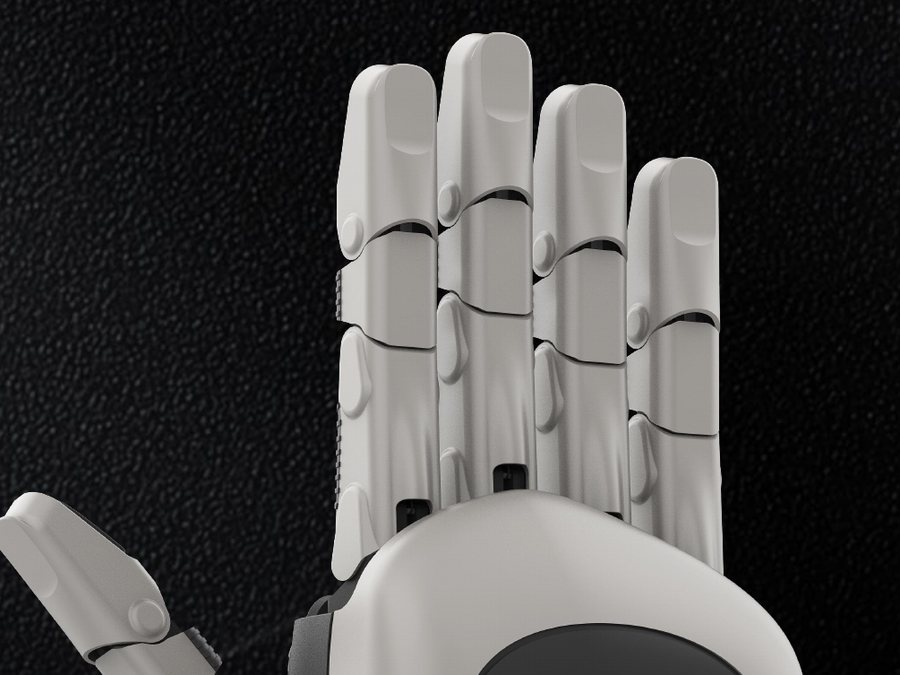
Wenn Ihr Team eigene Roboter entwickelt, liefern wir auch die Teile, die hineingehören: Gelenkmotoren und Gelenkmodule, geschickte Hände — die BrainCo Revo 2 Serie (Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 pro Hand, die einzigen Listenpreise in diesem Abschnitt) und die Dexrobot DexHand 021 und DexHand 021 S (Preis noch zu bestätigen) — plus Roboterarme, Akkus und Steuerungen. Nennen Sie uns Typ, Spezifikationen und benötigte Menge — wir kalkulieren pro Artikel.
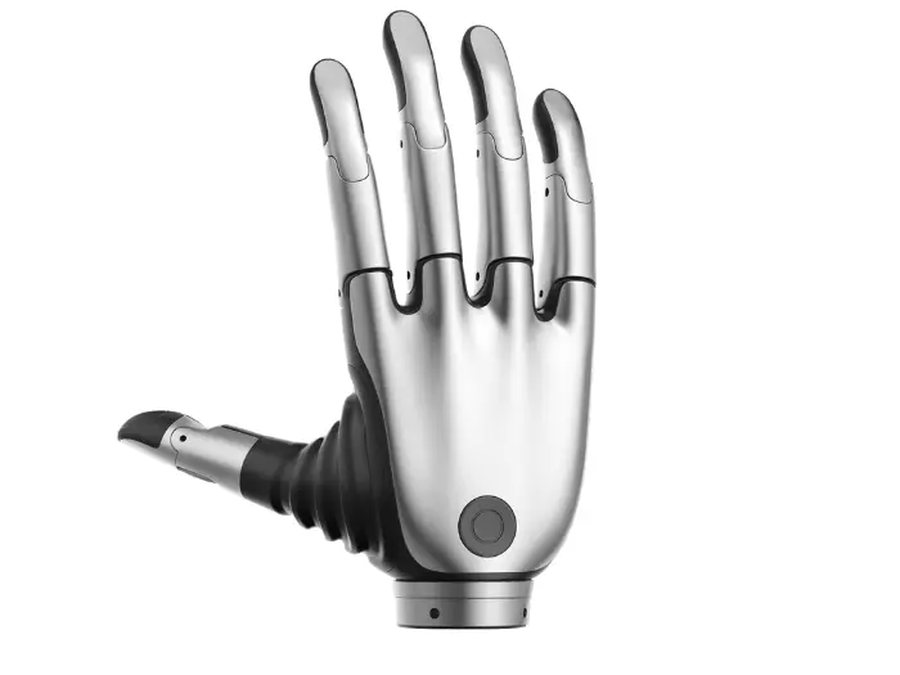
Geschickte Hände — Revo 2
Geschickte Hände der Revo 2 Serie: Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 pro Hand. Auch andere geschickte Hände sind verfügbar — senden Sie uns Ihre Spezifikation.
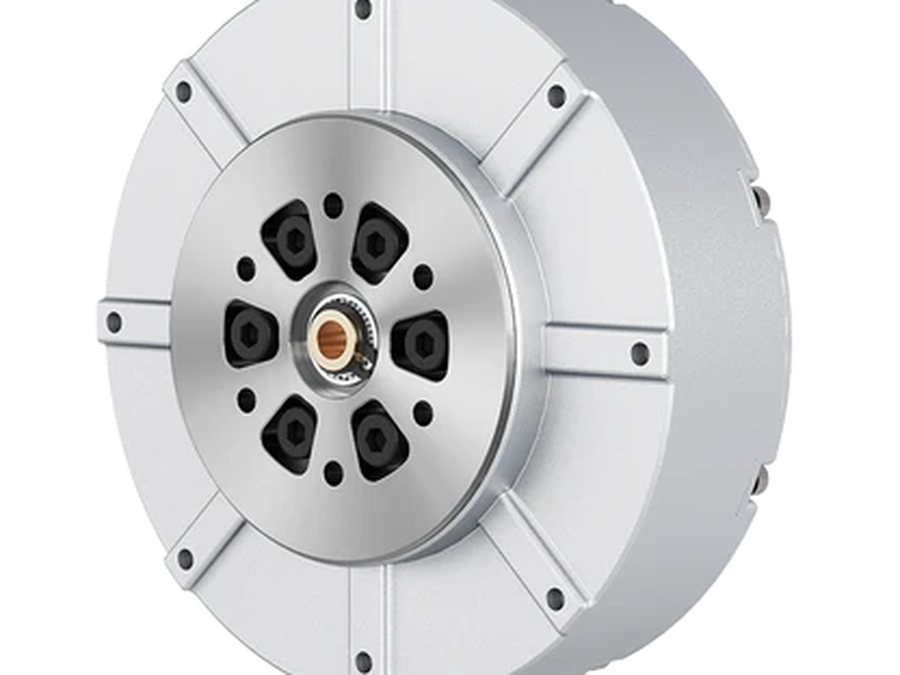
Gelenkmotoren & Gelenkmodule
Gelenkmotoren und Gelenkmodule für selbstentwickelte Roboter. Senden Sie uns Typ, Spezifikation und benötigte Menge, und wir kalkulieren Artikel für Artikel.
Akkus & Steuerungen
Akkus, Fernsteuerungen und weiteres Zubehör für die von uns gelieferten Plattformen — Preis pro Spezifikation auf Anfrage. Mehr Teile in unserem Spezialshop: Robosparex — Teile & Zubehör.
Vollständige Modellliste mit technischen Daten
Alle Modelle, die wir derzeit liefern, mit den wichtigsten technischen Daten. Der Zustand zeigt, ob die gelistete Version neu oder gebraucht ist; viele Modelle sind in beiden verfügbar — fragen Sie uns. Sie können diese Liste auch herunterladen (Excel).
| Modell | Variante | Zustand | Typ | Abmessungen | Gewicht (kg) | DOF | Nutzlast (kg) | Akku / Laufzeit | Max. Geschwindigkeit | Entwicklungsunterstützung |
|---|---|---|---|---|---|---|---|---|---|---|
| AgiBot A2 | Young Edition | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 63 | 23 | ~2 kg per arm | Battery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet) | Max walking 0.8 m/s (dealer spec sheet) | AimMaster/AimDK choreography and interaction customization tools (performance & presentation use); full low-level SDK openness not clearly stated by the manufacturer |
| AgiBot A2 | Flagship | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 69 | 40+ (active DOF) | ~3 kg per arm | 700Wh; ~2 h (hot-swappable battery) | Max walking 1.2 m/s (after V1.3 OTA update) | Secondary development supported: AimDK (HTTP JSON-RPC + ROS2 Topic interfaces, AimRT framework) |
| AgiBot X2 | Basic Version | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 35 | 25 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh; ~2 h continuous walking (at 0.5 m/s) | 1.8m/s | No secondary development (no public SDK, locked system; development open on Ultra only) |
| AgiBot X2 | Ultra | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) |
| AgiBot X2 | Ultra | Used | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking (pre-owned unit; hardware identical to new) | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) (pre-owned unit; hardware identical to new) |
| AgiBot A3 | Basic Version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (AimDK development only on the Development version) |
| AgiBot A3 | Development version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open AimDK development SDK (HTTP JSON-RPC + ROS2 Topic interfaces) |
| AgiBot A3 Ultra | Basic Version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (Open SDK + ROS2 only on Development/EDU versions) |
| AgiBot A3 Ultra | Development version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK), full development documentation included |
| AgiBot A3 Ultra | Embodied version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | No separate official statement found on this version's software entitlements (hardware as A3 Ultra) |
| AgiBot A3 Ultra | EDU | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK); education/research software and support package |
| Booster K1 | Geek | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 2Ah; ~20 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (this version: 48 TOPS compute) |
| Booster K1 | Education | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~80 min | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (117 TOPS, Jetson Orin NX) |
| Booster K1 | Professional | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~70 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (200 TOPS, Jetson AGX Orin) |
| Booster T1 | Basic | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); no Intel host on this version (AGX Orin 200 TOPS only). Note: one third-party database claims the Basic version lacks SDK support, contradicting official developer docs — confirm with the manufacturer before ordering |
| Booster T1 | Standard | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); AGX Orin 200 TOPS + Intel i7-1370P host |
| Booster T1 | Customized | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 31 (gripper version) / 41 (dexterous-hand version) | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); 7-DOF arms, optional gripper or 6-DOF dexterous hands; compute as Standard |
| Booster T2 | P1 | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (base configuration, no end effector) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P2 Claw | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (standard gripper configuration) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P3 Nimble Hands | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (6-DOF dexterous hands) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Deep Robotics Lite3 | Basic | New | Quadruped | Standing 610×370×406mm | 12 | 12 | Walking payload 5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Venture | Used | Quadruped | Standing 610×370×445mm | 12.2 | 12 | Walking payload 4.5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Pro | Used | Quadruped | Standing 610×370×450mm | 12.9 | 12 | Walking payload 4 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | LiDAR | Used | Quadruped | Standing 610×370×496mm | 13.5 | 12 | Walking payload 2.5 | 1.5–2 h | 4 m/s | Motion control SDK, perception development sample code and communication protocols (ROS1/ROS2) |
| Deep Robotics M20 | Basic | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Business development interfaces (Gigabit Ethernet, 72V power interface) |
| Deep Robotics M20 | Pro | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Secondary development supported (Gigabit Ethernet, USB 3.0, 24V/72V power interfaces, SLAM mapping & navigation) |
| Deep Robotics X30 | Basic | Used | Quadruped | Standing 1000×585×470mm | 56 | 12 | Rated payload ≥20 (max 85) | 2.5–4 h | ≥4 m/s | Secondary development supported |
| Deep Robotics X30 | Pro | Used | Quadruped | Standing 1000×585×470mm | 59 | 12 | 20 (max 85) | 4 h unloaded / 2.5 h loaded | ≥4 m/s | Secondary development supported (industrial-grade SDK interfaces) |
| Deep Robotics M20S | — | New | Quadruped (wheeled-leg) | Not published | 33 (manufacturer states weight unchanged from M20 Pro) | Not published | Continuous payload 35 kg (flat terrain) | 3.5–5 h unloaded / 2.5–3.5 h loaded | 9 m/s | Not published |
| Dobot Atom | Base | New | Humanoid | Height ~1530mm | 62 | 41 (incl. dexterous hands; 29 without hands) | 3.5 kg per arm | ~2 h | 1.5 m/s (walking) | SDK secondary development supported (official SDK development guide available) |
| EngineAi PM01 | Commercial | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | No secondary development (manufacturer manual lists openness as "not supported"); the manufacturer also publishes EngineAI ROS (ROS2-based) open resources |
| EngineAi PM01 | Education | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | Open platform: x86 + NVIDIA Jetson Orin dual chips, open training/deployment code, secondary development supported; ROS2 (EngineAI ROS framework); native SDK (pm01_edu) via GitHub mirror, not directly from the official site |
| EngineAi T800 | Base | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery, per launch materials) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | No secondary development |
| EngineAi T800 | Education | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery; dealers cite 75–85 depending on version) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported (official Eco/open-source edition ≈ this Education version: stereo vision/LiDAR + AGX Orin 64G); dedicated official T800 SDK documentation not found |
| EngineAi T800 | Pro | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75–85 (varies by version, per dealers) | 43 (29 body + 7×2 hands) | Dexterous hand 5 kg per hand (whole-body / per-arm payload not published) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported |
| Leju Robotics Kuavo 4Pro | Base | New | Humanoid | Height ~1660mm | 55 | 40+ | Not published | Not published | >7 km/h (running) | Fully open motion-control and application development interfaces (open-source HarmonyOS) |
| LimX Dynamics Oli | Lite | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors) | Not published (same-series EDU/Super: max 3 kg per arm; no per-variant data for Lite) | ~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| LimX Dynamics Oli | Edu | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors; RobotShop lists 33 — unconfirmed) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development (plus C++/JavaScript examples); ROS2 (official GitHub); Isaac Sim/MuJoCo/Gazebo support |
| LimX Dynamics Oli | Super | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 33 (body only, excl. end effectors) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| Noteix N2 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | No secondary development; no official ROS2/Python statement found |
| Noteix N2 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | Secondary development supported (adds NVIDIA Jetson Orin Nano Super compute, depth camera; optional spherical hands / five-finger hands); no official ROS2/Python statement found |
| Noteix E1 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Base compute 6 TOPS (RK3588s); no open-SDK statement found; no official ROS2/Python statement found |
| Noteix E1 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Open SDK interfaces (velocity/motion commands and joint-level algorithm control), 6+67 TOPS compute (adds Jetson Orin Nano Super, depth camera); no official ROS2/Python statement found |
| Unitree G1 | Basic | Used | Humanoid | 1320×450×200mm (Standing ) | 35 | 23 | ~2 (per arm) | ~2 h | 2 m/s | No secondary development (no SDK; remote control / app demos only) |
| Unitree G1 | U1 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Jetson Orin compute module) |
| Unitree G1 | U2 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 (expandable) | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Orin NX 100 TOPS) |
| Unitree H2 | Basic | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | No official secondary-development support found (only the EDU version explicitly supports it) |
| Unitree H2 | EDU | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | Secondary development supported (EDU version; compute module customizable) |
| Unitree Go1 Air | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1 h | 2.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go1 Pro | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1.5 h | 3.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go2 Air | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 2.5 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Pro | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 3.7 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Edu | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~8 (limit 10) | ~2–4 h (15,000mAh long-life battery) | 3.7 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python; optional Jetson Orin expansion dock) |
| Unitree Go2-W | Standard Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Smart Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Laser Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree A2 | Base | New | Quadruped | 820×440×570mm | ~37 (incl. dual batteries) | 12 | ~25 (walking; standing max ~100) | ~5 h unloaded / ~3 h with 25 kg payload | 3.7 m/s (up to ~5) | Secondary development supported (Intel i7 development compute, ROS/ROS2) |
| Unitree As2 | EDU U1 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U2 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U3 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U4 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree B2 | Base | Used | Quadruped | ~1098×450×645mm | ~60 | 12 | Walking >40 (standing max 120) | ~4–6 h | >6 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python) |
| WEILAN Baby Alpha A2 | Standard | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 128GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Plus | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 256GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Pro | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 512GB storage, Premium Orange) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Ultra | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 1TB storage, Cyber Dream) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| MagicBot Z1 | Base | New | Bipedal humanoid (compact, high-dynamic; not a quadruped — the quadruped line is MagicDog) | ~140cm (Developer version 136.9 cm, 1369×422×200 mm) | ~40 (incl. battery) | 24 (base; expandable to 49/50 per different sources) | Max 3 kg per arm | ~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual) | ≥2.5m/s | Secondary development / OTA supported; official SDK magicbot-z1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
| MagicBot Gen1 | Base | New | Full-size general-purpose humanoid (nicknamed "Xiaomai") | 1740×580×280mm (174cm) | ~70 | 42 (active DOF) | 7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg) | 3–5 h (25Ah / 1.35kWh battery) | Official site ≥4 km/h; manual ≥2 m/s — sources differ | Secondary development / OTA supported; official SDK magicbot-gen1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
Ihr Modell gefunden?
Nennen Sie uns Modell und Menge — wir bestätigen Preis, Bestand und Lieferzeit, in der Regel innerhalb von 24 Stunden.
Angebot anfordern