Productos
Líneas principales: Unitree, AgiBot, ENGINEAI — humanoides, cuadrúpedos, robots con ruedas y brazos robóticos, nuevos y de segunda mano. También hay motores de articulación, módulos de articulación y manos diestras para equipos que construyen sus propios robots.
Los precios se confirman por consulta — solicita una cotización y confirmamos precio, stock y plazo, normalmente en 24 horas. Más allá de los modelos listados aquí, también podemos suministrar cualquier otro robot fabricado en China: si buscas un modelo, dínoslo y lo comprobaremos por ti.
Nota para visitantes de EE. UU.: para EE. UU. ofrecemos solo los modelos admitidos en ese mercado — pídenos la versión estadounidense de esta lista.
¿Qué tipo necesitas?
Robots humanoides
Elige un humanoide cuando las personas son lo importante: investigación en locomoción bípeda y manipulación, enseñanza, demostraciones, recepción y eventos. Si tu equipo necesita programarlo, revisa primero la línea Desarrollo y SDK de la página del modelo.
Robots cuadrúpedos
Elige un cuadrúpedo cuando el terreno es el problema — escaleras, grava, césped y superficies rotas — para trabajo de inspección, investigación y robótica de campo.
Robots con ruedas y de patas con ruedas
Elige patas con ruedas cuando tu sitio es sobre todo suelos, patios y pavimentos pero tiene escalones o rampas: más rápido y con más autonomía en suelo duro, y aún puede superar obstáculos.
Piezas y manos diestras
¿Construyes tu propio robot? Empieza con motores de articulación, módulos de articulación y manos diestras, cotizados por especificación — y pregúntanos por brazos, baterías y controladores compatibles.
Robots humanoides
Humanoides bípedos para investigación, educación, exposiciones y eventos — nuevos y de segunda mano. Especificaciones clave del catálogo completo siguiente; pídenos la versión que encaje con tu proyecto.
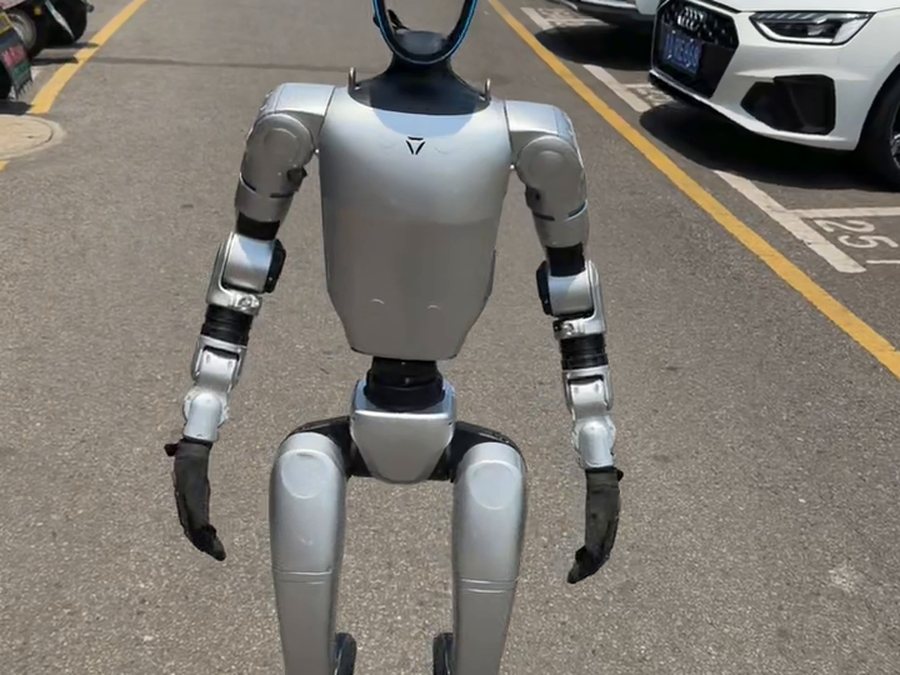
Los robots humanoides son la parte de nuestro catálogo que más rápido se mueve — plataformas bípedas de tamaño completo y compactas para laboratorios que necesitan una plataforma de desarrollo, escuelas que necesitan un robot de enseñanza y equipos de eventos que necesitan un imán de público. La mayoría de los modelos pueden suministrarse nuevos o de segunda mano; dinos el trabajo que debe hacer el robot y te orientaremos hacia las versiones adecuadas, con las diferencias de especificaciones explicadas.
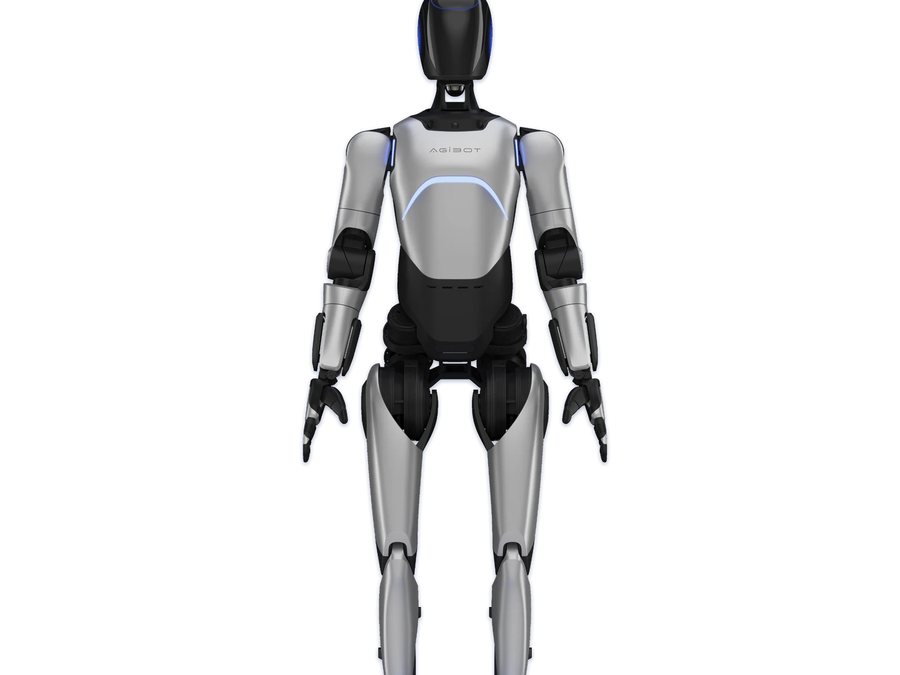
AgiBot A2
Young Edition / Flagship · Nuevo
- Tamaño169cm (169×75×30cm)
- Peso63 kg
- DOF23
- Carga útil~2 kg per arm
- Batería / autonomíaBattery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet)
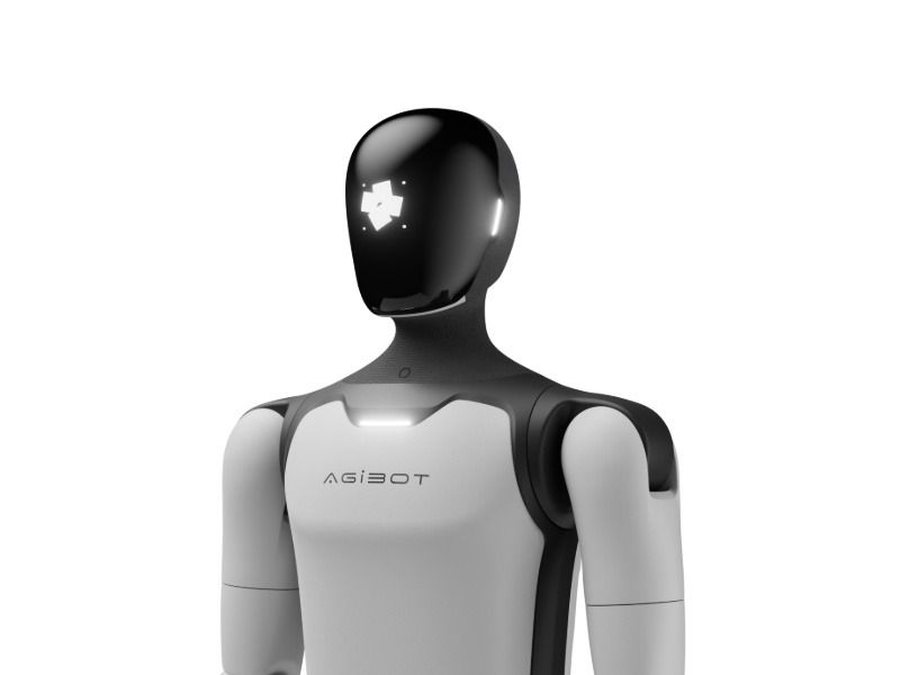
AgiBot A3
Basic Version / Development version · Nuevo
- Tamaño173cm (173×52×30cm)
- Peso55 kg
- DOF31 (active DOF)
- Carga útil5 kg per arm
- Batería / autonomía1152Wh dual battery; up to ~10 h in typical use (10-second battery swap)
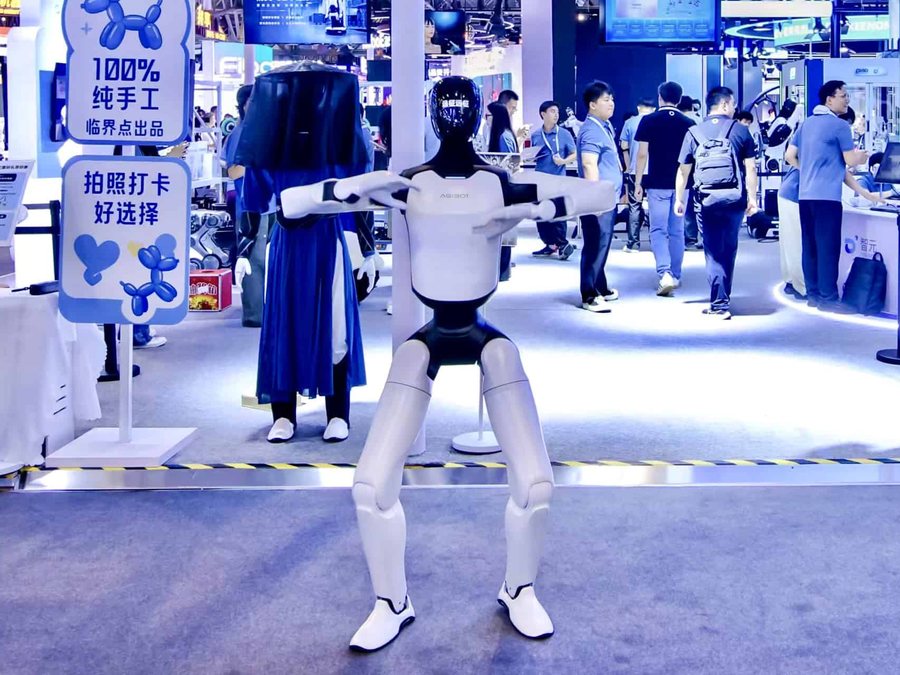
AgiBot A3 Ultra
Basic Version / Development version / Embodied version / EDU · Nuevo
- Tamaño174cm (174×52×30cm)
- Peso60 kg
- DOF51 (active DOF)
- Carga útil5 kg per arm
- Batería / autonomía1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap)
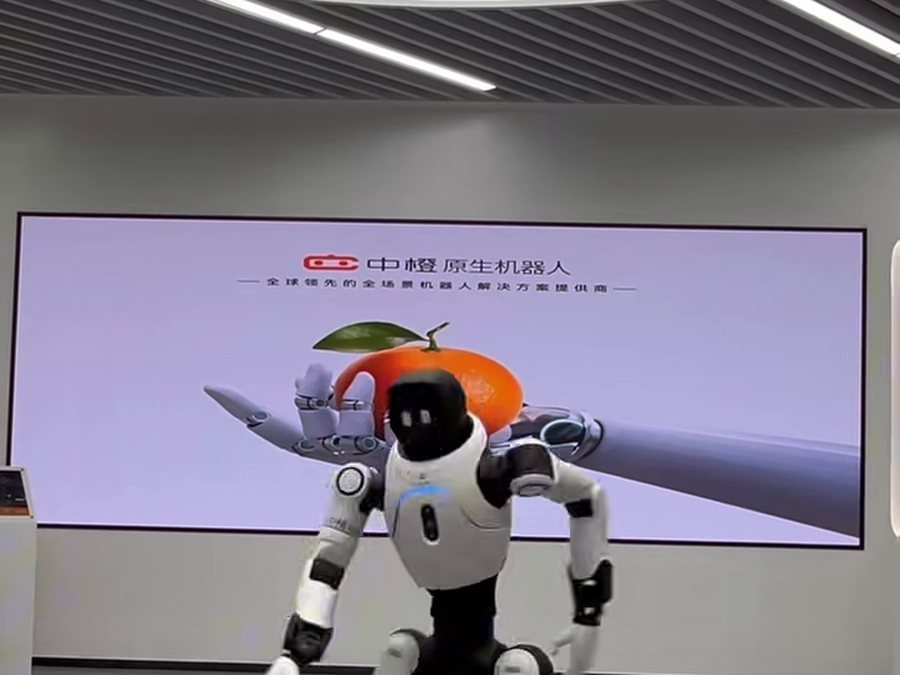
AgiBot X2
Basic Version / Ultra · De segunda mano y nuevo
- Tamaño131cm (131×46×21cm)
- Peso35 kg
- DOF25
- Carga útil~3 kg in specific postures; ≤1 kg across full workspace
- Batería / autonomía~500Wh; ~2 h continuous walking (at 0.5 m/s)
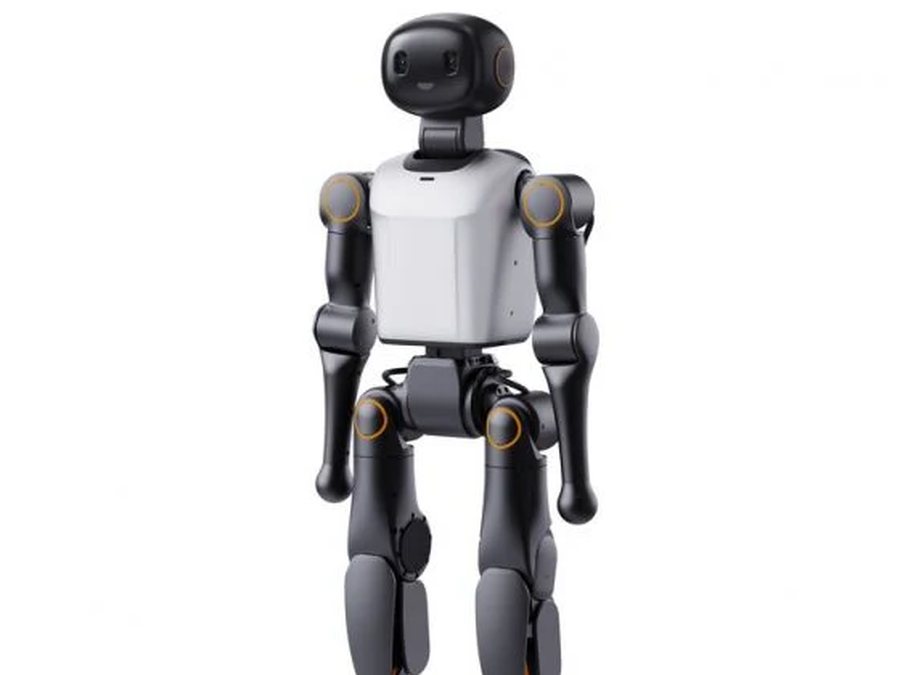
Booster K1
Geek / Education / Professional · Nuevo
- Tamaño~95cm
- Peso19.5 kg
- DOF22
- Batería / autonomía2Ah; ~20 min (official figure, walking at 1.1 m/s)
- Velocidad máx.2 m/s (walking speed per official site)
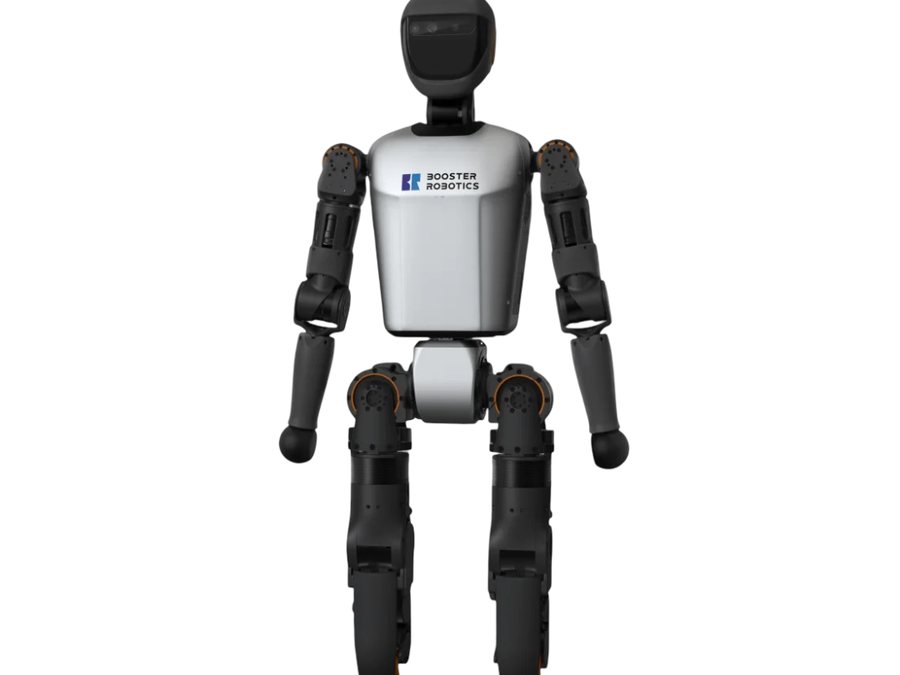
Booster T1
Basic / Standard / Customized · Nuevo
- Tamaño118cm (118×47×23cm)
- Peso30 kg
- DOF23
- Batería / autonomía10.5Ah battery; ~2 h walking, ~4 h standing
- Velocidad máx.0.5 m/s (walking speed per manual; top speed not published)
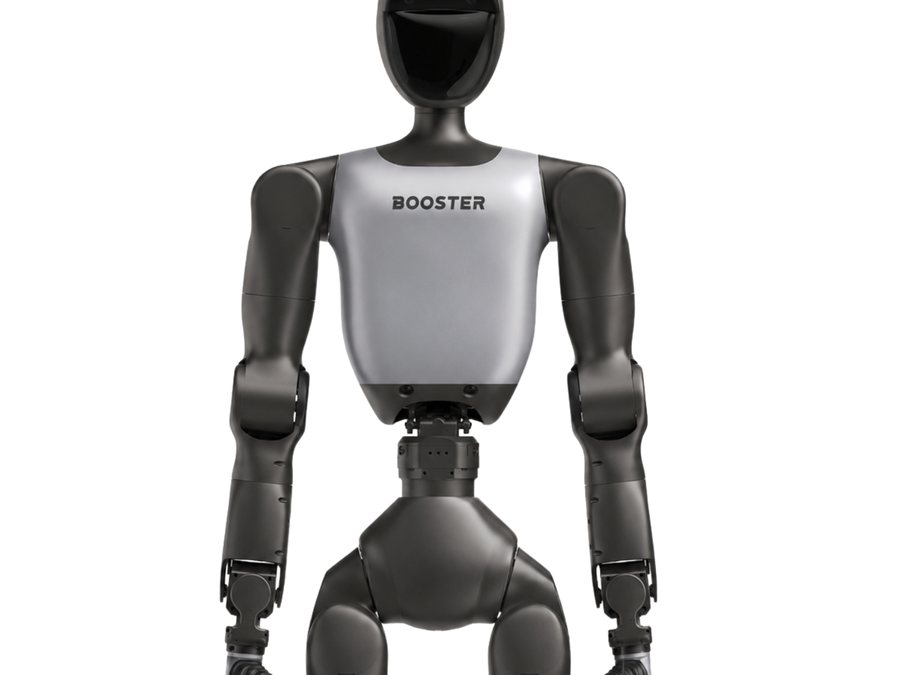
Booster T2
P1 / P2 Claw / P3 Nimble Hands · Nuevo
- Tamaño140cm
- Peso~42 kg
- DOF31
- Carga útilMax 10 kg both arms (base configuration, no end effector)
- Batería / autonomía48V 10Ah; ~2 h continuous walking
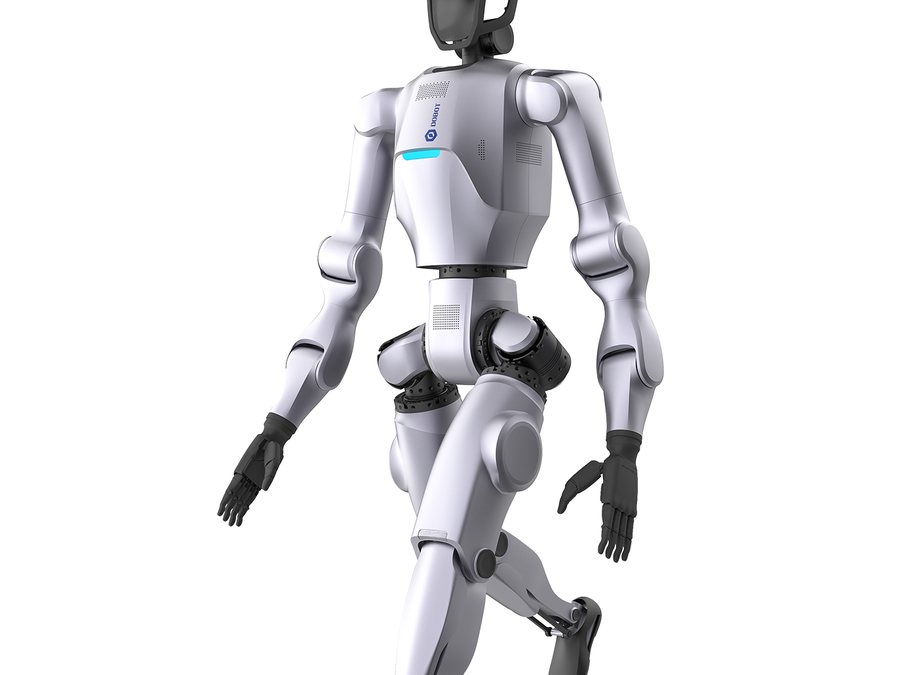
Dobot Atom
Base · Nuevo
- TamañoHeight ~1530mm
- Peso62 kg
- DOF41 (incl. dexterous hands; 29 without hands)
- Carga útil3.5 kg per arm
- Batería / autonomía~2 h
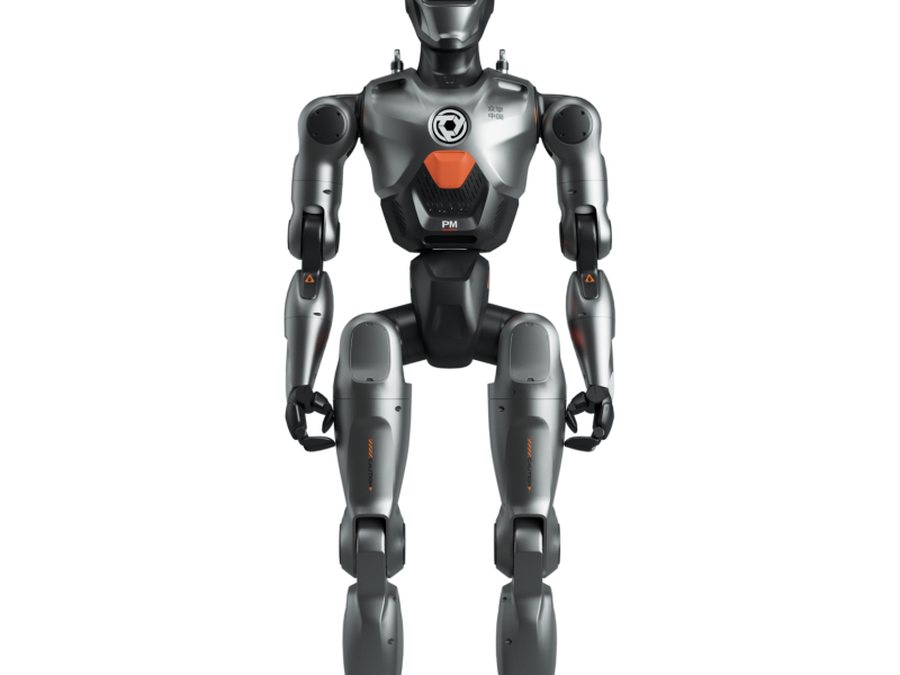
EngineAi PM01
Commercial / Education · De segunda mano
- Tamaño138cm (manual: 1388×490×220 mm)
- Peso~40 (manual spec table ~43 incl. battery — sources differ)
- DOF23 (manufacturer headline says 24-DOF)
- Batería / autonomía~2 h (10,000mAh quick-release battery)
- Velocidad máx.2m/s
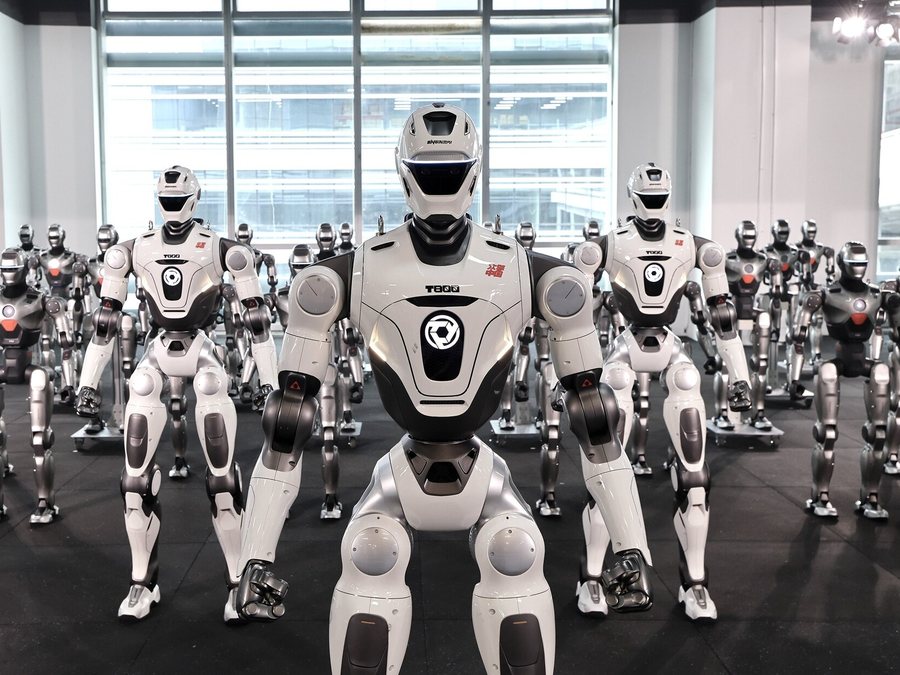
EngineAi T800
Base / Education / Pro · Nuevo
- Tamaño173cm (legs 91 cm, arms 60 cm)
- Peso75 (incl. battery, per launch materials)
- DOF25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands)
- Batería / autonomía4–5 h (solid-state battery, per manufacturer launch)
- Velocidad máx.≥3 m/s (hardware-capable)
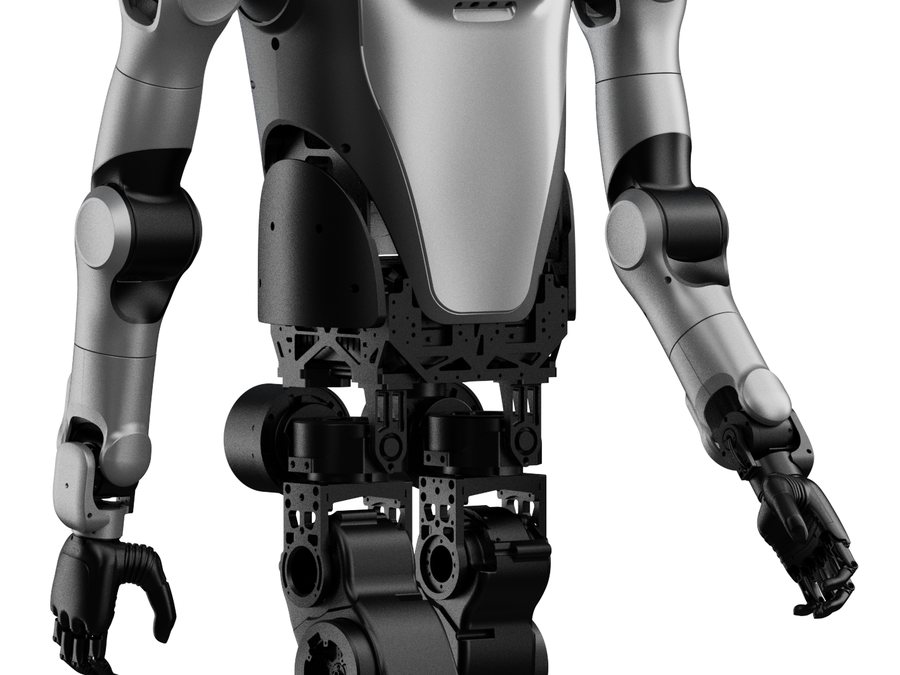
Leju Robotics Kuavo 4Pro
Base · Nuevo
- TamañoHeight ~1660mm
- Peso55 kg
- DOF40+
- Velocidad máx.>7 km/h (running)
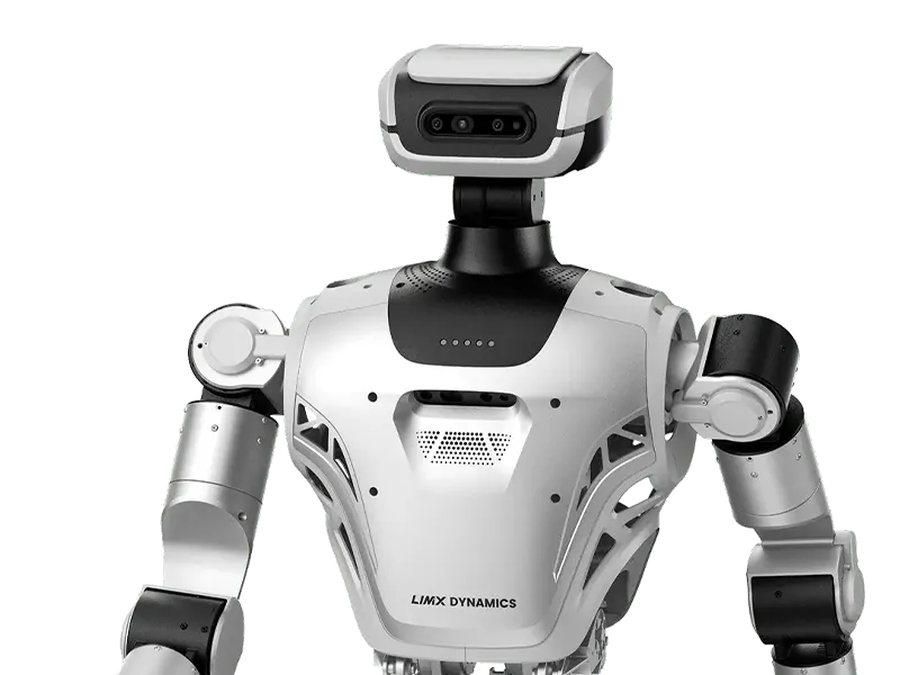
LimX Dynamics Oli
Lite / Edu / Super · Nuevo
- Tamaño165cm (shoulder width ≈55 cm, arm length ≈70 cm)
- Peso≤55 (incl. battery)
- DOF31 (body only, excl. end effectors)
- Batería / autonomía~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery)
- Velocidad máx.Max walking speed 5 km/h
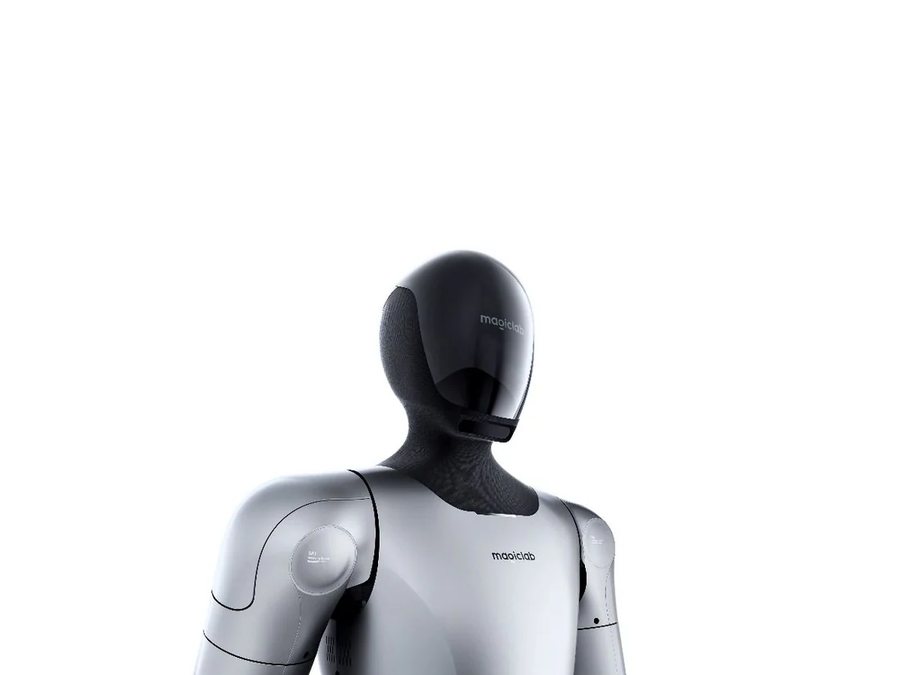
MagicBot Gen1
Base · Nuevo
- Tamaño1740×580×280mm (174cm)
- Peso~70 kg
- DOF42 (active DOF)
- Carga útil7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg)
- Batería / autonomía3–5 h (25Ah / 1.35kWh battery)
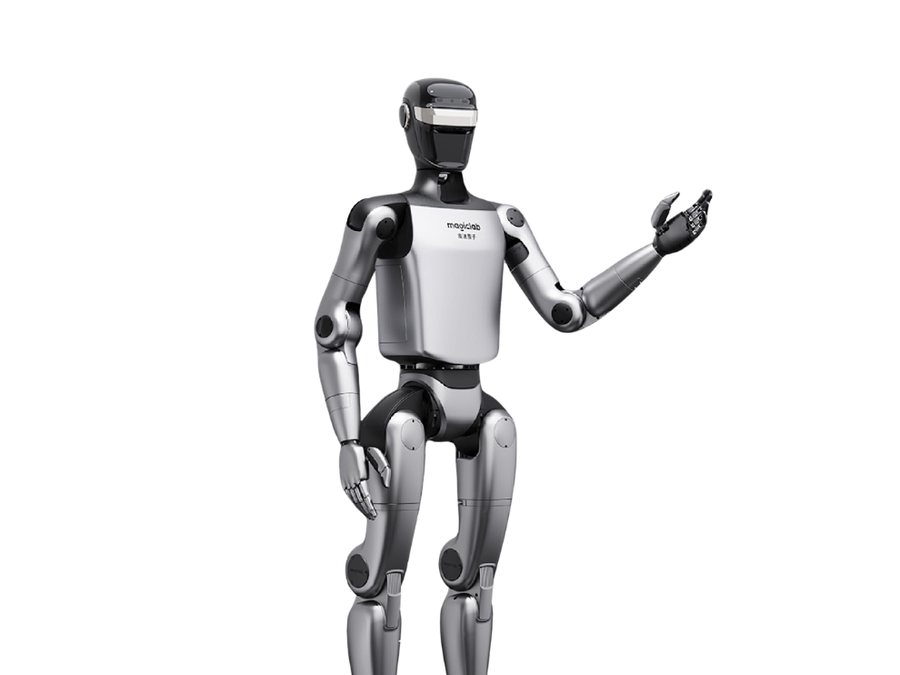
MagicBot Z1
Base · Nuevo
- Tamaño~140cm (Developer version 136.9 cm, 1369×422×200 mm)
- Peso~40 (incl. battery)
- DOF24 (base; expandable to 49/50 per different sources)
- Carga útilMax 3 kg per arm
- Batería / autonomía~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual)
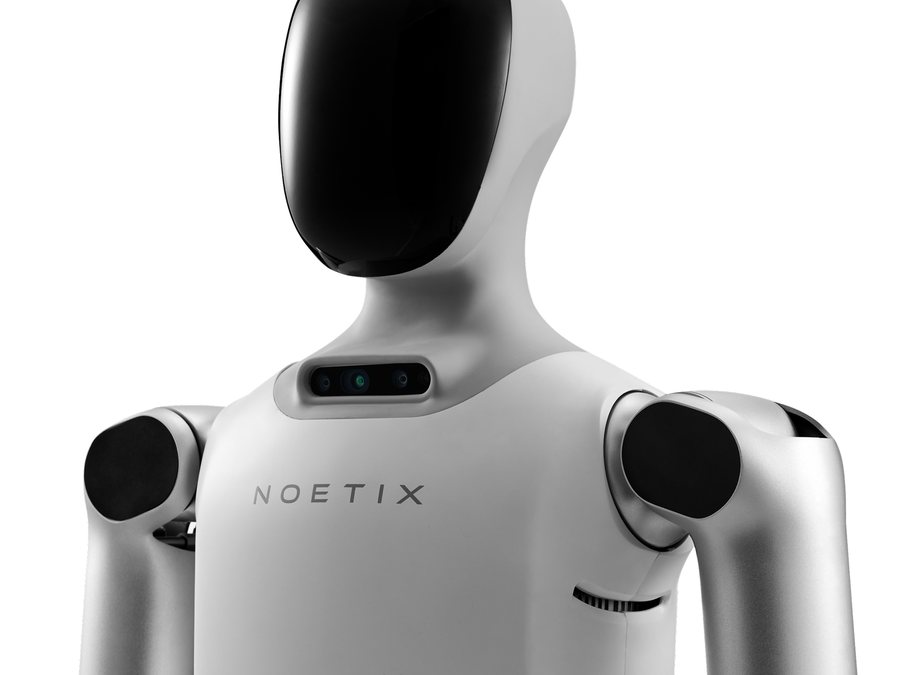
Noteix E1
Standard / Edu · De segunda mano
- Tamaño136×47×29cm
- Peso~36 kg
- DOF23 (manufacturer manual) / 21 (press release) — sources conflict
- Batería / autonomía1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict
- Velocidad máx.Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence)
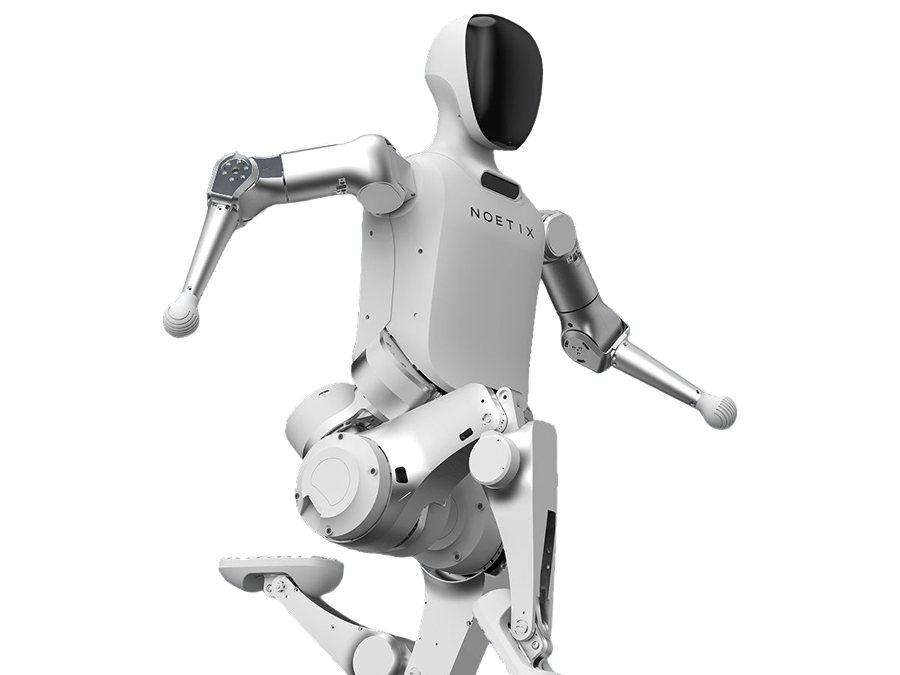
Noteix N2
Standard / Edu · De segunda mano
- Tamaño118 cm H × 47 cm W
- Peso~30 (another compilation lists 29)
- DOF18
- Carga útil~5 (carried while walking continuously)
- Batería / autonomía1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min)
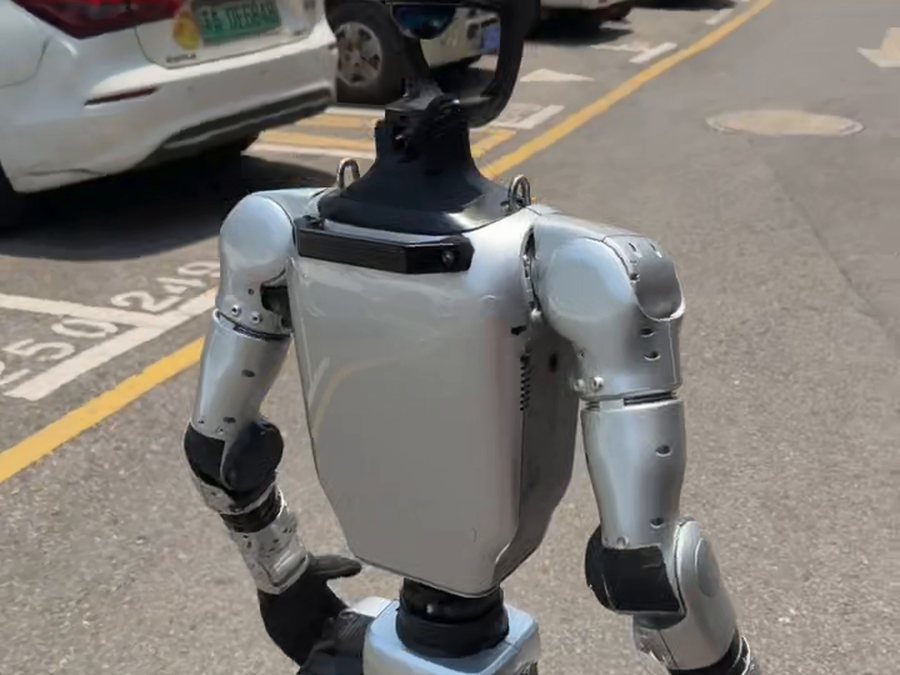
Unitree G1
Basic / U1 / U2 · De segunda mano
- Tamaño1320×450×200mm (Standing )
- Peso35 kg
- DOF23
- Carga útil~2 (per arm)
- Batería / autonomía~2 h
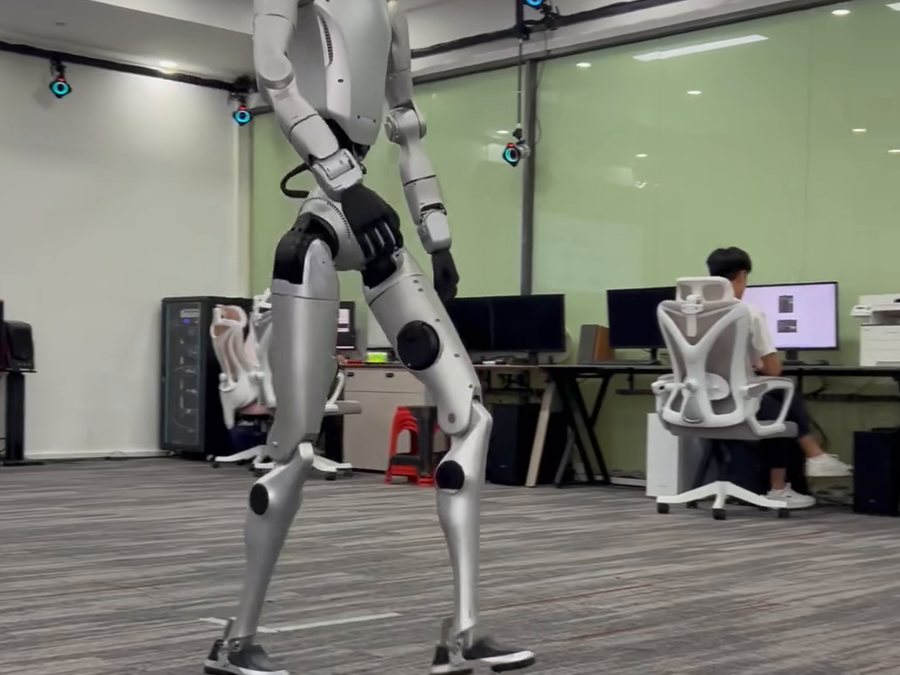
Unitree H2
Basic / EDU · Nuevo
- Tamaño~182cm
- Peso70 kg
- DOF31
- Carga útil~7 (peak 21)
- Batería / autonomía~3 h
Robots cuadrúpedos
Plataformas de cuatro patas para investigación, práctica de inspección, educación y demostraciones — nuevas y de segunda mano.
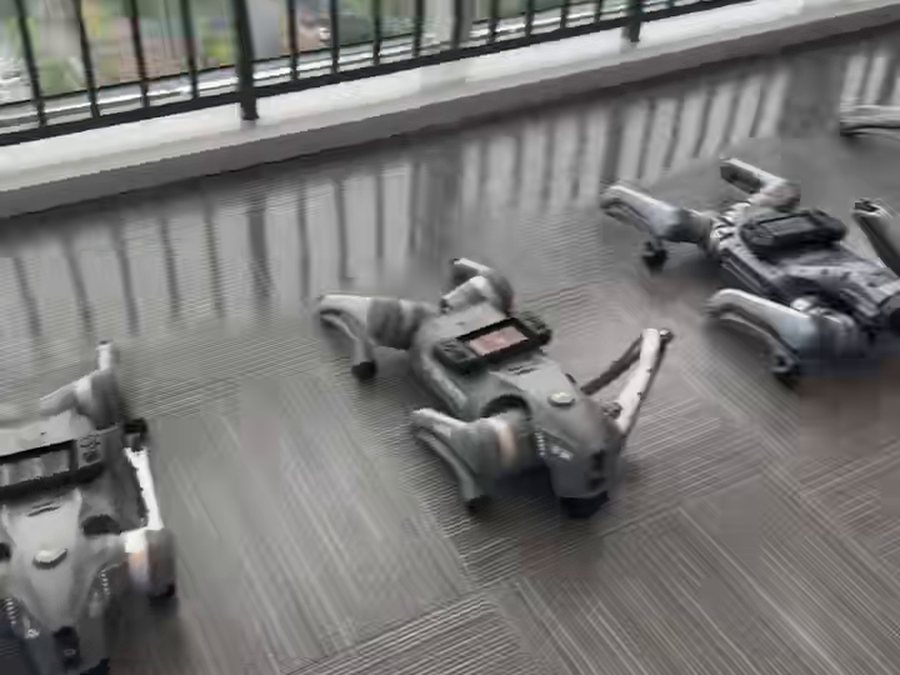
Los robots de cuatro patas se ganan su lugar donde las ruedas no pueden ir: escaleras, grava, césped y terreno roto. Nuestra gama de cuadrúpedos va de plataformas educativas compactas a máquinas industriales de inspección, nuevas y de segunda mano. Si no estás seguro de qué clase de tamaño necesitas, dinos el terreno y la carga útil — eso lo decide.
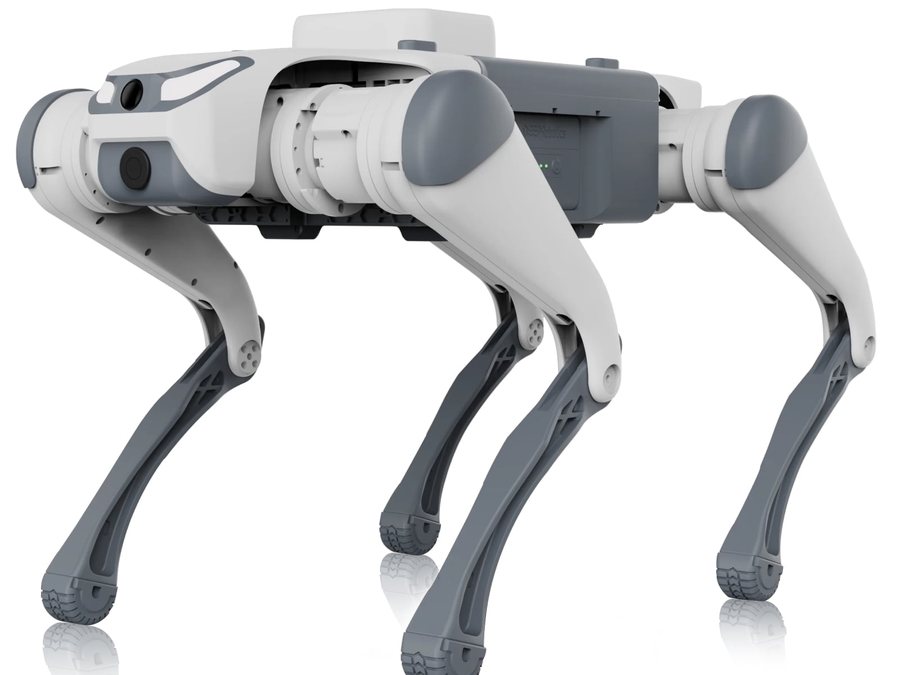
Deep Robotics Lite3
Basic / Venture / Pro / LiDAR · De segunda mano y nuevo
- TamañoStanding 610×370×406mm
- Peso12 kg
- DOF12
- Carga útilWalking payload 5
- Batería / autonomía1.5–2 h
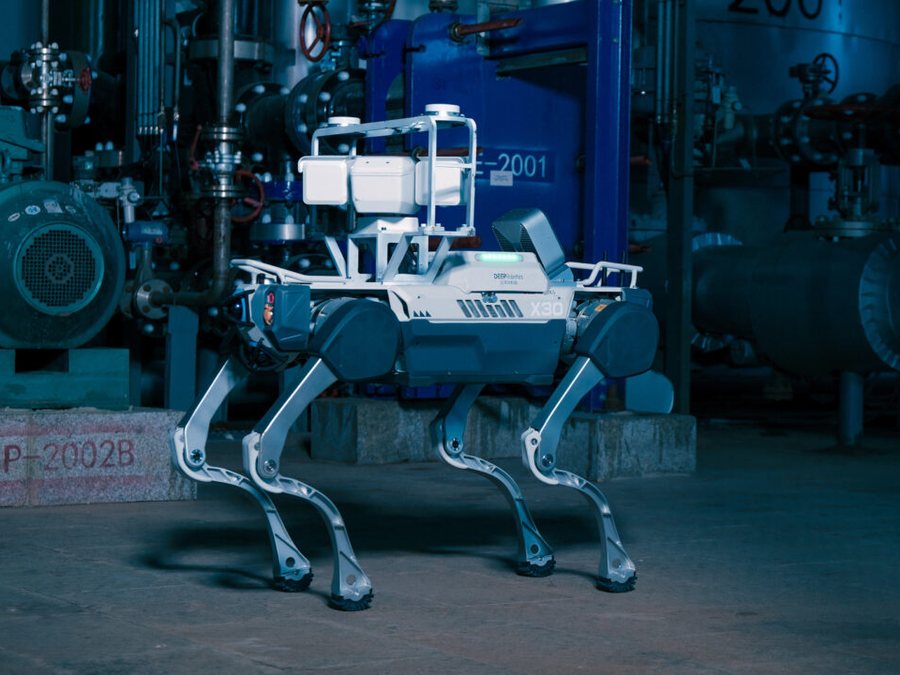
Deep Robotics X30
Basic / Pro · De segunda mano
- TamañoStanding 1000×585×470mm
- Peso56 kg
- DOF12
- Carga útilRated payload ≥20 (max 85)
- Batería / autonomía2.5–4 h
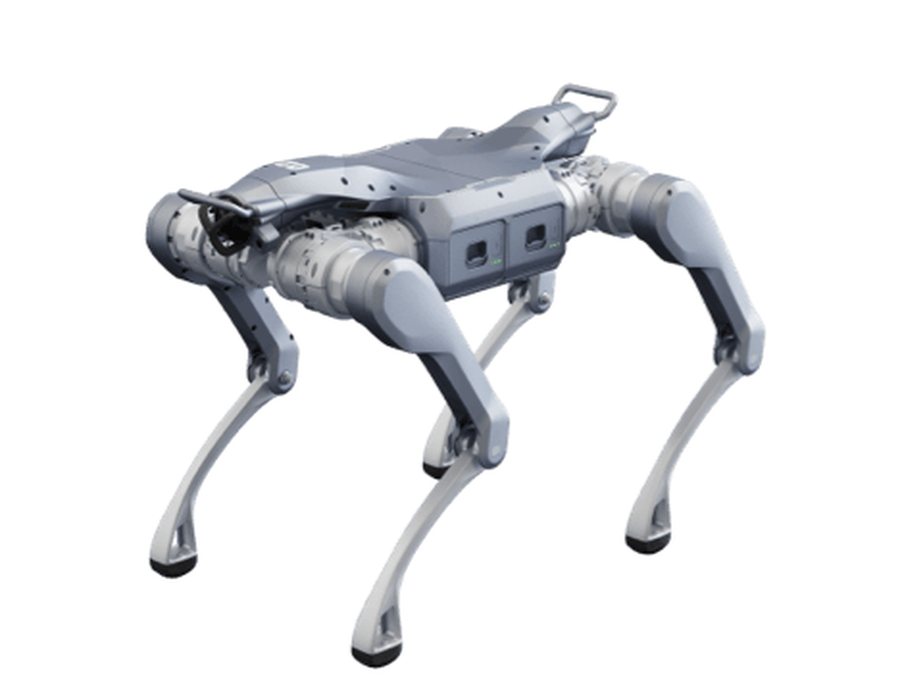
Unitree A2
Base · Nuevo
- Tamaño820×440×570mm
- Peso~37 (incl. dual batteries)
- DOF12
- Carga útil~25 (walking; standing max ~100)
- Batería / autonomía~5 h unloaded / ~3 h with 25 kg payload
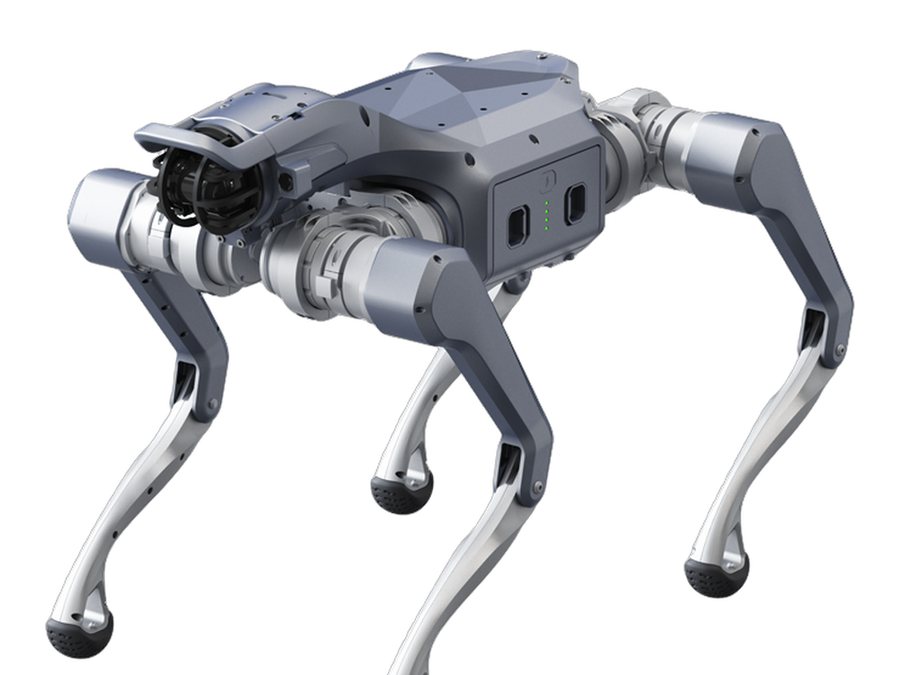
Unitree As2
EDU U1 / EDU U2 / EDU U3 / EDU U4 · Nuevo
- Peso18 kg
- DOF12
- Carga útil~15 (walking; standing max ~65)
- Batería / autonomía>4 h unloaded
- Velocidad máx.3.7 m/s (peak 5)
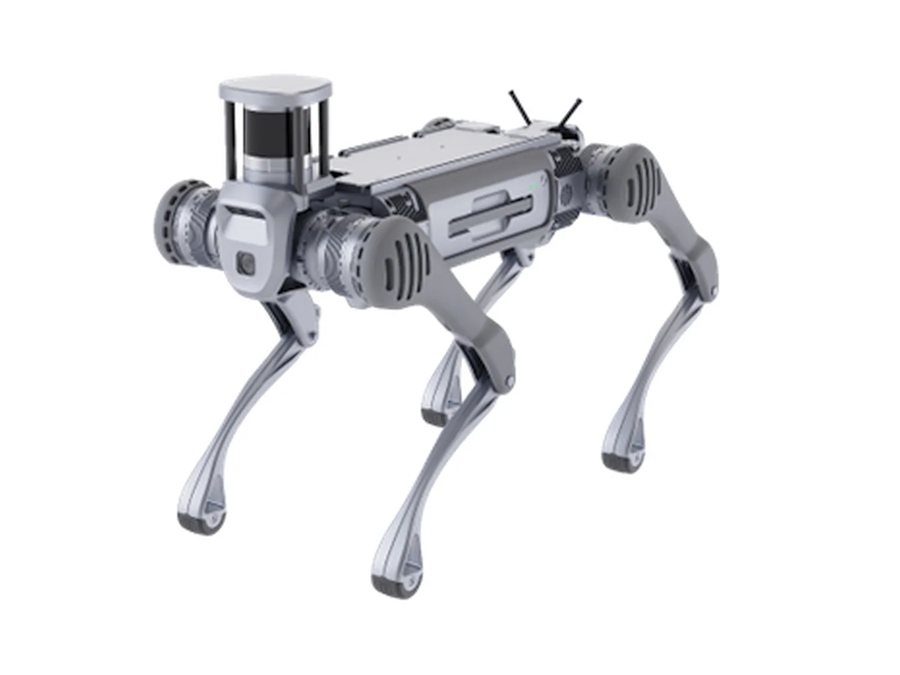
Unitree B2
Base · De segunda mano
- Tamaño~1098×450×645mm
- Peso~60 kg
- DOF12
- Carga útilWalking >40 (standing max 120)
- Batería / autonomía~4–6 h
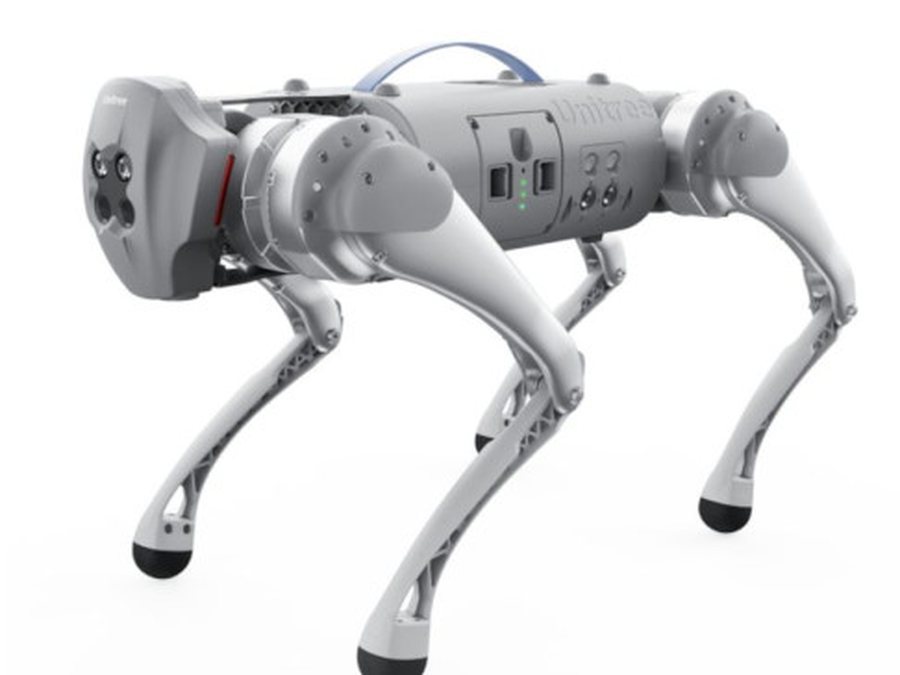
Unitree Go1 Air
Base · De segunda mano
- Tamaño645×280×400mm
- Peso12 kg
- DOF12
- Carga útil~3
- Batería / autonomía~1 h
Unitree Go1 Pro
Base · De segunda mano
- Tamaño645×280×400mm
- Peso12 kg
- DOF12
- Carga útil~3
- Batería / autonomía~1.5 h
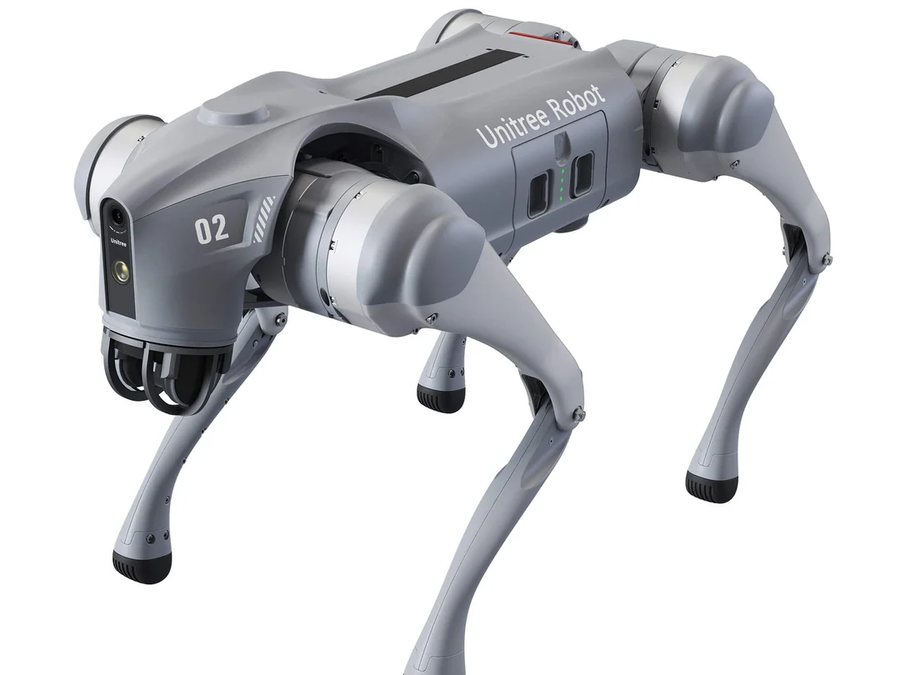
Unitree Go2 Air
Base · De segunda mano
- Tamaño700×310×400mm
- Peso15 kg
- DOF12
- Carga útil~7 (max ~10)
- Batería / autonomía~1–2 h
Unitree Go2 Edu
Base · De segunda mano
- Tamaño700×310×400mm
- Peso15 kg
- DOF12
- Carga útil~8 (limit 10)
- Batería / autonomía~2–4 h (15,000mAh long-life battery)
Unitree Go2 Pro
Base · De segunda mano
- Tamaño700×310×400mm
- Peso15 kg
- DOF12
- Carga útil~7 (max ~10)
- Batería / autonomía~1–2 h
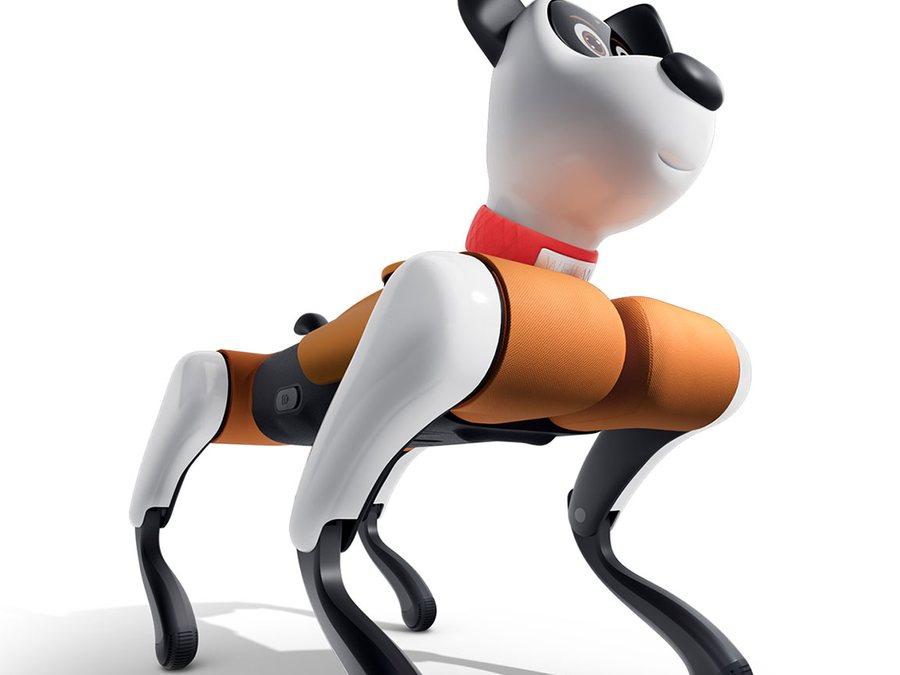
WEILAN Baby Alpha A2
Standard / Plus / Pro / Ultra · De segunda mano
- Batería / autonomía~120 min (media report only; not published by manufacturer)
- Velocidad máx.6.0 km/h (single media source, low–medium confidence)
Robots con ruedas y de patas con ruedas
Cuadrúpedos de patas con ruedas que ruedan en suelo plano y superan obstáculos — para trabajo interior/exterior donde las ruedas solas no bastan.
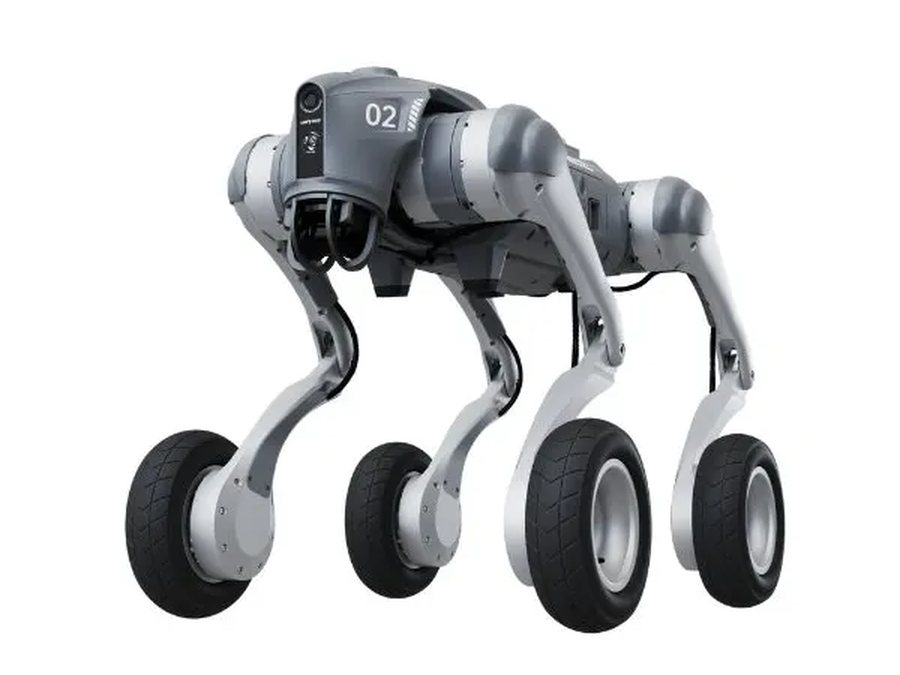
Los robots con ruedas y de patas con ruedas cambian un poco de capacidad todoterreno por velocidad, autonomía y estabilidad en el suelo que la mayoría de los sitios realmente tienen — suelos, patios, pavimentos y rampas. Esta sección cubre nuestros cuadrúpedos de patas con ruedas; si tu sitio es sobre todo superficies duras con algún escalón o pendiente, empieza aquí.
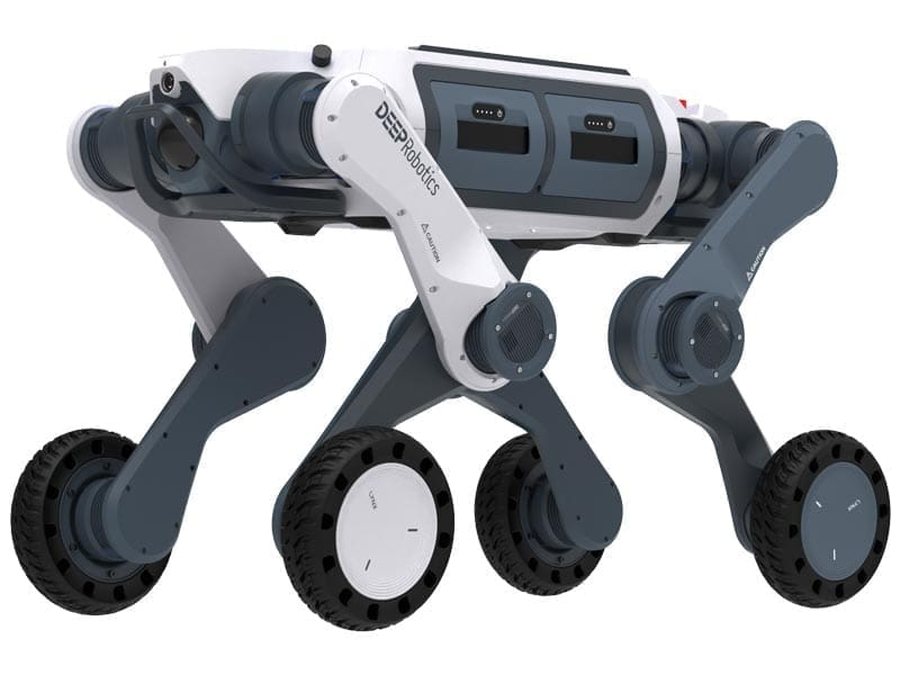
Deep Robotics M20
Basic / Pro · Nuevo
- TamañoStanding 820×430×570mm
- Peso33 kg
- DOF16
- Carga útilRated payload 15 (max 50)
- Batería / autonomía3 h unloaded / 2.5 h loaded
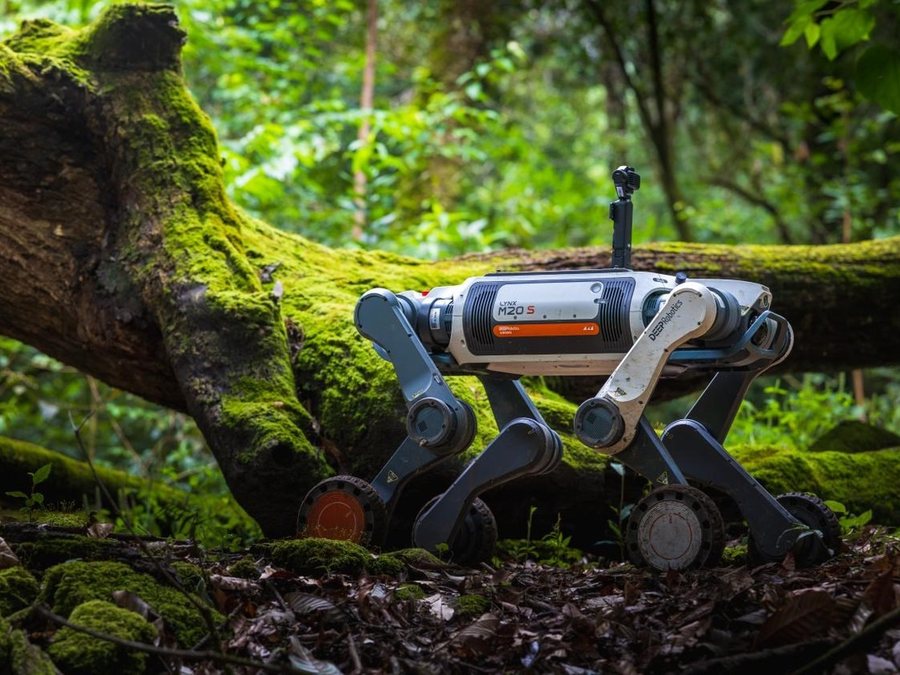
Deep Robotics M20S
New
- Peso33 (manufacturer states weight unchanged from M20 Pro)
- Carga útilContinuous payload 35 kg (flat terrain)
- Batería / autonomía3.5–5 h unloaded / 2.5–3.5 h loaded
- Velocidad máx.9 m/s
Unitree Go2-W
Standard Edition / Smart Edition / Laser Edition · Nuevo
- Tamaño700×430×500mm
- Peso18 kg
- DOF16 (12 leg joints + 4 hub motors)
- Carga útil~8 (max ~12)
- Batería / autonomía~2–4 h
Brazos robóticos
Brazos para plataformas de investigación humanoides y cuadrúpedas, adaptados a tu robot y requisitos de carga útil.
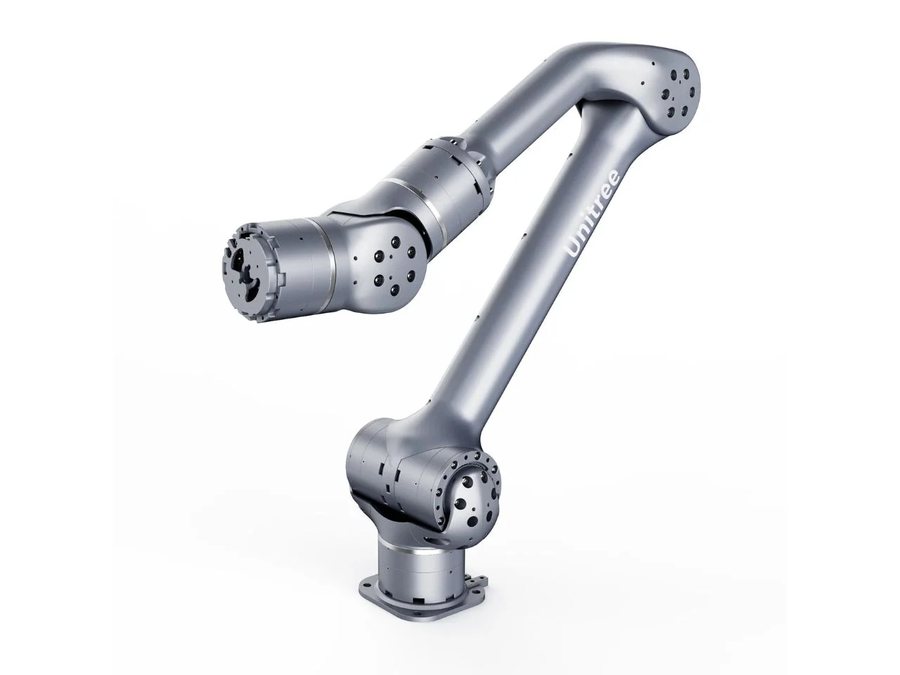
Brazos robóticos
Dinos la plataforma sobre la que lo montarás y la carga útil que necesitas — adaptaremos un brazo y lo cotizaremos por especificación, junto con el robot o por separado.
Robots de segunda mano
Las versiones de segunda mano de muchos modelos anteriores están en stock — cada una inspeccionada, con informe de estado y video de la unidad real.
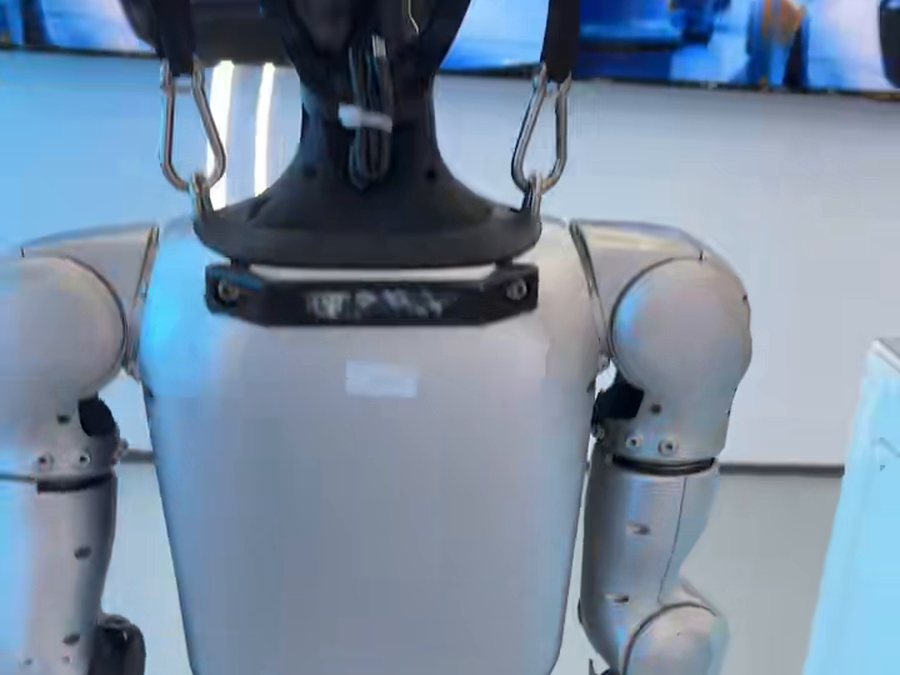
Stock de segunda mano
Los precios de segunda mano son una fracción del precio nuevo del mismo modelo. Dinos el modelo que buscas y te enviaremos el informe de estado y el precio de la unidad en stock.
Cómo funciona lo de segunda mano · Preguntar por stock de segunda mano
Piezas para constructores de robots
Una gama aparte para equipos que construyen sus propios robots — componentes, no máquinas completas.
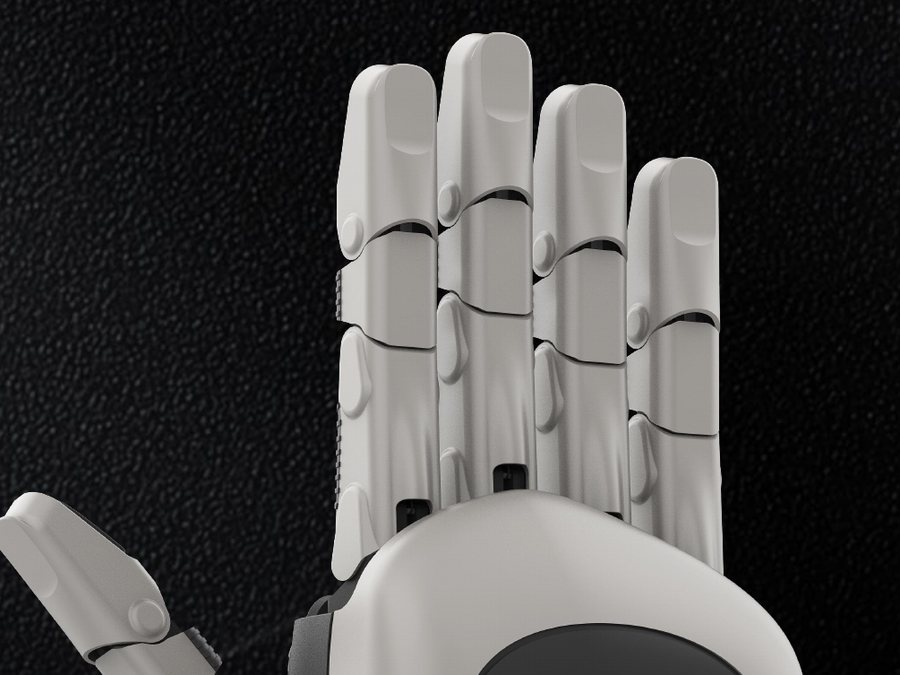
Si tu equipo desarrolla sus propios robots, también suministramos las piezas que los componen: motores de articulación y módulos de articulación, manos diestras — la gama BrainCo Revo 2 (Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 por mano, los únicos precios de lista de esta sección) y la Dexrobot DexHand 021 y DexHand 021 S (precio por confirmar) — además de brazos robóticos, baterías y controladores. Dinos el tipo, las especificaciones y la cantidad que necesitas — cotizamos por artículo.
Solicitar una cotización de piezas
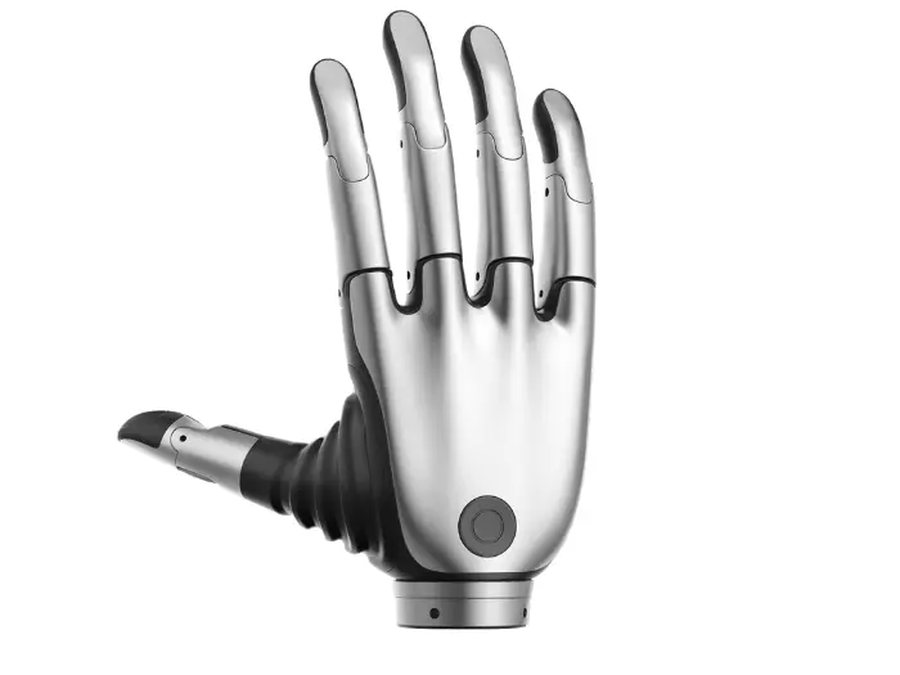
Manos diestras — Revo 2
Manos diestras de la serie Revo 2: Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 por mano. También hay otras manos diestras — envíanos tu especificación.
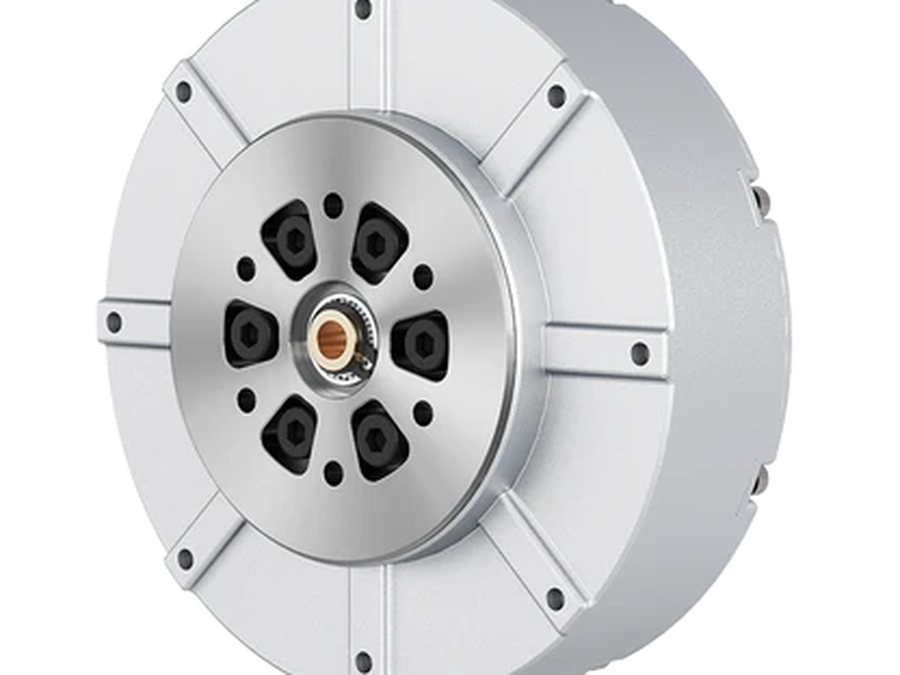
Motores y módulos de articulación
Motores de articulación y módulos de articulación para robots de desarrollo propio. Envíanos el tipo, la especificación y la cantidad que necesitas y cotizaremos artículo por artículo.
Baterías y controladores
Baterías, controles remotos y otros accesorios para las plataformas que suministramos — precio por especificación a petición. Más piezas en nuestra tienda dedicada: Robosparex — piezas y accesorios.
Lista completa de modelos con especificaciones
Todos los modelos que suministramos actualmente, con especificaciones clave. El estado indica si la versión listada es nueva o de segunda mano; muchos modelos están disponibles en ambos — pregúntanos. También puedes descargar esta lista (Excel).
| Modelo | Variante | Estado | Tipo | Dimensiones | Peso (kg) | DOF | Carga útil (kg) | Batería / autonomía | Velocidad máx. | Soporte de desarrollo |
|---|---|---|---|---|---|---|---|---|---|---|
| AgiBot A2 | Young Edition | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 63 | 23 | ~2 kg per arm | Battery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet) | Max walking 0.8 m/s (dealer spec sheet) | AimMaster/AimDK choreography and interaction customization tools (performance & presentation use); full low-level SDK openness not clearly stated by the manufacturer |
| AgiBot A2 | Flagship | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 69 | 40+ (active DOF) | ~3 kg per arm | 700Wh; ~2 h (hot-swappable battery) | Max walking 1.2 m/s (after V1.3 OTA update) | Secondary development supported: AimDK (HTTP JSON-RPC + ROS2 Topic interfaces, AimRT framework) |
| AgiBot X2 | Basic Version | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 35 | 25 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh; ~2 h continuous walking (at 0.5 m/s) | 1.8m/s | No secondary development (no public SDK, locked system; development open on Ultra only) |
| AgiBot X2 | Ultra | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) |
| AgiBot X2 | Ultra | Used | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking (pre-owned unit; hardware identical to new) | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) (pre-owned unit; hardware identical to new) |
| AgiBot A3 | Basic Version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (AimDK development only on the Development version) |
| AgiBot A3 | Development version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open AimDK development SDK (HTTP JSON-RPC + ROS2 Topic interfaces) |
| AgiBot A3 Ultra | Basic Version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (Open SDK + ROS2 only on Development/EDU versions) |
| AgiBot A3 Ultra | Development version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK), full development documentation included |
| AgiBot A3 Ultra | Embodied version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | No separate official statement found on this version's software entitlements (hardware as A3 Ultra) |
| AgiBot A3 Ultra | EDU | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK); education/research software and support package |
| Booster K1 | Geek | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 2Ah; ~20 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (this version: 48 TOPS compute) |
| Booster K1 | Education | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~80 min | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (117 TOPS, Jetson Orin NX) |
| Booster K1 | Professional | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~70 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (200 TOPS, Jetson AGX Orin) |
| Booster T1 | Basic | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); no Intel host on this version (AGX Orin 200 TOPS only). Note: one third-party database claims the Basic version lacks SDK support, contradicting official developer docs — confirm with the manufacturer before ordering |
| Booster T1 | Standard | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); AGX Orin 200 TOPS + Intel i7-1370P host |
| Booster T1 | Customized | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 31 (gripper version) / 41 (dexterous-hand version) | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); 7-DOF arms, optional gripper or 6-DOF dexterous hands; compute as Standard |
| Booster T2 | P1 | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (base configuration, no end effector) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P2 Claw | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (standard gripper configuration) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P3 Nimble Hands | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (6-DOF dexterous hands) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Deep Robotics Lite3 | Basic | New | Quadruped | Standing 610×370×406mm | 12 | 12 | Walking payload 5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Venture | Used | Quadruped | Standing 610×370×445mm | 12.2 | 12 | Walking payload 4.5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Pro | Used | Quadruped | Standing 610×370×450mm | 12.9 | 12 | Walking payload 4 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | LiDAR | Used | Quadruped | Standing 610×370×496mm | 13.5 | 12 | Walking payload 2.5 | 1.5–2 h | 4 m/s | Motion control SDK, perception development sample code and communication protocols (ROS1/ROS2) |
| Deep Robotics M20 | Basic | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Business development interfaces (Gigabit Ethernet, 72V power interface) |
| Deep Robotics M20 | Pro | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Secondary development supported (Gigabit Ethernet, USB 3.0, 24V/72V power interfaces, SLAM mapping & navigation) |
| Deep Robotics X30 | Basic | Used | Quadruped | Standing 1000×585×470mm | 56 | 12 | Rated payload ≥20 (max 85) | 2.5–4 h | ≥4 m/s | Secondary development supported |
| Deep Robotics X30 | Pro | Used | Quadruped | Standing 1000×585×470mm | 59 | 12 | 20 (max 85) | 4 h unloaded / 2.5 h loaded | ≥4 m/s | Secondary development supported (industrial-grade SDK interfaces) |
| Deep Robotics M20S | — | New | Quadruped (wheeled-leg) | Not published | 33 (manufacturer states weight unchanged from M20 Pro) | Not published | Continuous payload 35 kg (flat terrain) | 3.5–5 h unloaded / 2.5–3.5 h loaded | 9 m/s | Not published |
| Dobot Atom | Base | New | Humanoid | Height ~1530mm | 62 | 41 (incl. dexterous hands; 29 without hands) | 3.5 kg per arm | ~2 h | 1.5 m/s (walking) | SDK secondary development supported (official SDK development guide available) |
| EngineAi PM01 | Commercial | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | No secondary development (manufacturer manual lists openness as "not supported"); the manufacturer also publishes EngineAI ROS (ROS2-based) open resources |
| EngineAi PM01 | Education | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | Open platform: x86 + NVIDIA Jetson Orin dual chips, open training/deployment code, secondary development supported; ROS2 (EngineAI ROS framework); native SDK (pm01_edu) via GitHub mirror, not directly from the official site |
| EngineAi T800 | Base | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery, per launch materials) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | No secondary development |
| EngineAi T800 | Education | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery; dealers cite 75–85 depending on version) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported (official Eco/open-source edition ≈ this Education version: stereo vision/LiDAR + AGX Orin 64G); dedicated official T800 SDK documentation not found |
| EngineAi T800 | Pro | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75–85 (varies by version, per dealers) | 43 (29 body + 7×2 hands) | Dexterous hand 5 kg per hand (whole-body / per-arm payload not published) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported |
| Leju Robotics Kuavo 4Pro | Base | New | Humanoid | Height ~1660mm | 55 | 40+ | Not published | Not published | >7 km/h (running) | Fully open motion-control and application development interfaces (open-source HarmonyOS) |
| LimX Dynamics Oli | Lite | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors) | Not published (same-series EDU/Super: max 3 kg per arm; no per-variant data for Lite) | ~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| LimX Dynamics Oli | Edu | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors; RobotShop lists 33 — unconfirmed) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development (plus C++/JavaScript examples); ROS2 (official GitHub); Isaac Sim/MuJoCo/Gazebo support |
| LimX Dynamics Oli | Super | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 33 (body only, excl. end effectors) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| Noteix N2 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | No secondary development; no official ROS2/Python statement found |
| Noteix N2 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | Secondary development supported (adds NVIDIA Jetson Orin Nano Super compute, depth camera; optional spherical hands / five-finger hands); no official ROS2/Python statement found |
| Noteix E1 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Base compute 6 TOPS (RK3588s); no open-SDK statement found; no official ROS2/Python statement found |
| Noteix E1 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Open SDK interfaces (velocity/motion commands and joint-level algorithm control), 6+67 TOPS compute (adds Jetson Orin Nano Super, depth camera); no official ROS2/Python statement found |
| Unitree G1 | Basic | Used | Humanoid | 1320×450×200mm (Standing ) | 35 | 23 | ~2 (per arm) | ~2 h | 2 m/s | No secondary development (no SDK; remote control / app demos only) |
| Unitree G1 | U1 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Jetson Orin compute module) |
| Unitree G1 | U2 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 (expandable) | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Orin NX 100 TOPS) |
| Unitree H2 | Basic | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | No official secondary-development support found (only the EDU version explicitly supports it) |
| Unitree H2 | EDU | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | Secondary development supported (EDU version; compute module customizable) |
| Unitree Go1 Air | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1 h | 2.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go1 Pro | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1.5 h | 3.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go2 Air | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 2.5 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Pro | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 3.7 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Edu | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~8 (limit 10) | ~2–4 h (15,000mAh long-life battery) | 3.7 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python; optional Jetson Orin expansion dock) |
| Unitree Go2-W | Standard Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Smart Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Laser Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree A2 | Base | New | Quadruped | 820×440×570mm | ~37 (incl. dual batteries) | 12 | ~25 (walking; standing max ~100) | ~5 h unloaded / ~3 h with 25 kg payload | 3.7 m/s (up to ~5) | Secondary development supported (Intel i7 development compute, ROS/ROS2) |
| Unitree As2 | EDU U1 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U2 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U3 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U4 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree B2 | Base | Used | Quadruped | ~1098×450×645mm | ~60 | 12 | Walking >40 (standing max 120) | ~4–6 h | >6 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python) |
| WEILAN Baby Alpha A2 | Standard | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 128GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Plus | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 256GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Pro | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 512GB storage, Premium Orange) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Ultra | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 1TB storage, Cyber Dream) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| MagicBot Z1 | Base | New | Bipedal humanoid (compact, high-dynamic; not a quadruped — the quadruped line is MagicDog) | ~140cm (Developer version 136.9 cm, 1369×422×200 mm) | ~40 (incl. battery) | 24 (base; expandable to 49/50 per different sources) | Max 3 kg per arm | ~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual) | ≥2.5m/s | Secondary development / OTA supported; official SDK magicbot-z1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
| MagicBot Gen1 | Base | New | Full-size general-purpose humanoid (nicknamed "Xiaomai") | 1740×580×280mm (174cm) | ~70 | 42 (active DOF) | 7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg) | 3–5 h (25Ah / 1.35kWh battery) | Official site ≥4 km/h; manual ≥2 m/s — sources differ | Secondary development / OTA supported; official SDK magicbot-gen1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
¿Encontraste tu modelo?
Dinos el modelo y la cantidad — confirmamos precio, stock y plazo, normalmente en 24 horas.
Pedir una cotización