Produits
Gammes principales : Unitree, AgiBot, ENGINEAI — humanoïdes, quadrupèdes, robots à roues et bras robotiques, neufs et d’occasion. Moteurs d’articulation, modules d’articulation et mains dextres sont aussi disponibles pour les équipes qui construisent leurs propres robots.
Les prix sont confirmés sur demande — demandez un devis et nous confirmons prix, stock et délai, généralement sous 24 heures. Au-delà des modèles listés ici, nous pouvons aussi fournir tout autre robot fabriqué en Chine : si vous cherchez un modèle, dites-le-nous et nous vérifierons pour vous.
Note pour les visiteurs des États-Unis : pour les États-Unis, nous ne proposons que les modèles admis sur ce marché — demandez-nous la version américaine de cette liste.
Quel type vous faut-il ?
Robots humanoïdes
Choisissez un humanoïde quand les personnes sont l’enjeu : recherche en locomotion bipède et manipulation, enseignement, démonstrations, accueil et événements. Si votre équipe doit le programmer, vérifiez d’abord la ligne Développement et SDK de la page du modèle.
Robots quadrupèdes
Choisissez un quadrupède quand le sol est le problème — escaliers, gravier, herbe et surfaces cassées — pour l’inspection, la recherche et la robotique de terrain.
Robots à roues et à pattes à roues
Choisissez les pattes à roues quand votre site est surtout fait de sols, cours et trottoirs mais comporte des marches ou des rampes : plus rapide et plus endurant sur sol dur, et il franchit toujours les obstacles.
Pièces et mains dextres
Vous construisez votre propre robot ? Commencez par les moteurs d’articulation, les modules d’articulation et les mains dextres, chiffrés par spécification — et demandez-nous les bras, batteries et contrôleurs assortis.
Robots humanoïdes
Humanoïdes bipèdes pour la recherche, l’éducation, les expositions et les événements — neufs et d’occasion. Spécifications clés du catalogue complet ci-dessous ; demandez-nous la version adaptée à votre projet.
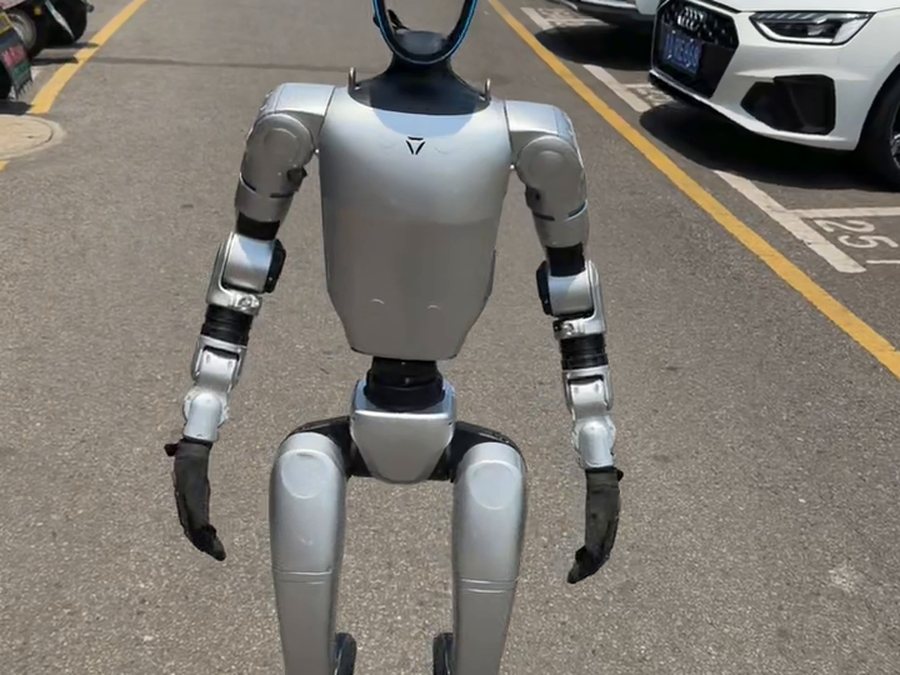
Les robots humanoïdes sont la partie de notre catalogue qui évolue le plus vite — plateformes bipèdes pleine taille et compactes pour les laboratoires qui ont besoin d’une plateforme de développement, les écoles qui ont besoin d’un robot pédagogique et les équipes événementielles qui ont besoin d’attirer la foule. La plupart des modèles peuvent être fournis neufs ou d’occasion ; dites-nous le travail que le robot doit faire et nous vous orienterons vers les versions adaptées, différences de spécifications à l’appui.
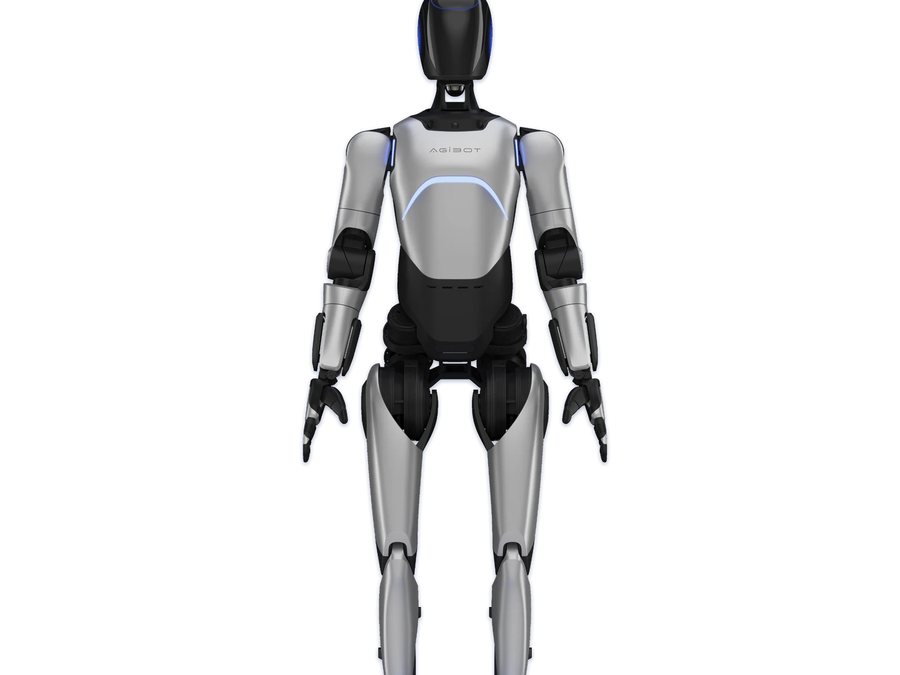
AgiBot A2
Young Edition / Flagship · Nouveau
- Taille169cm (169×75×30cm)
- Poids63 kg
- DOF23
- Charge utile~2 kg per arm
- Batterie / autonomieBattery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet)
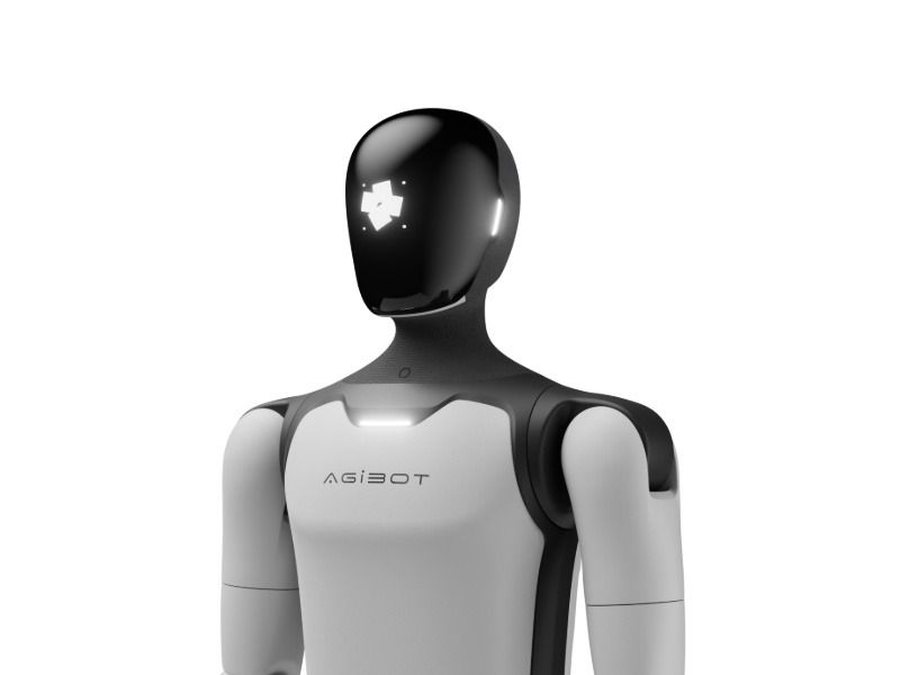
AgiBot A3
Basic Version / Development version · Nouveau
- Taille173cm (173×52×30cm)
- Poids55 kg
- DOF31 (active DOF)
- Charge utile5 kg per arm
- Batterie / autonomie1152Wh dual battery; up to ~10 h in typical use (10-second battery swap)
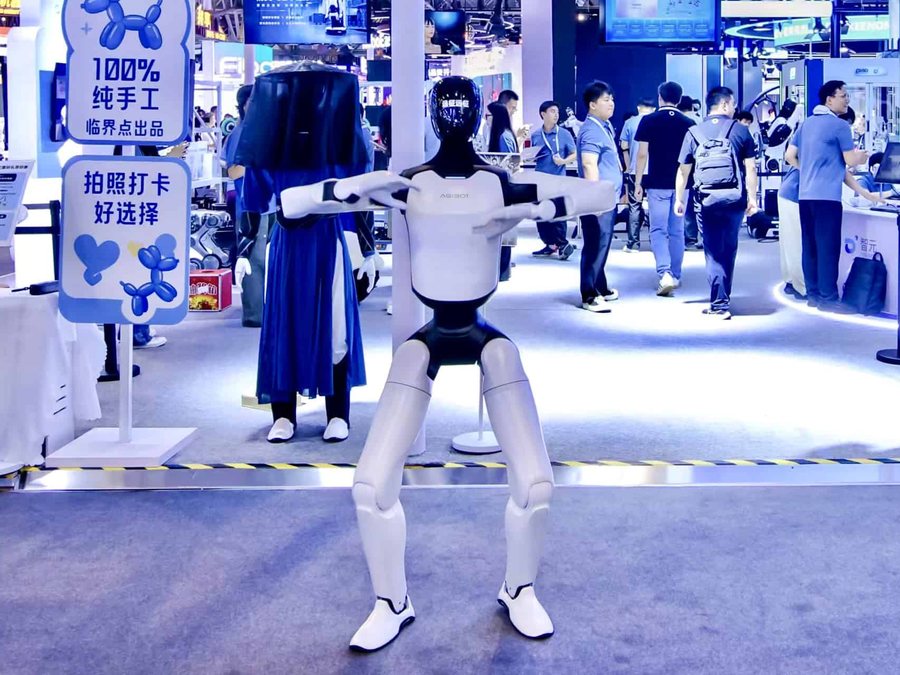
AgiBot A3 Ultra
Basic Version / Development version / Embodied version / EDU · Nouveau
- Taille174cm (174×52×30cm)
- Poids60 kg
- DOF51 (active DOF)
- Charge utile5 kg per arm
- Batterie / autonomie1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap)
AgiBot X2
Basic Version / Ultra · Occasion et neuf
- Taille131cm (131×46×21cm)
- Poids35 kg
- DOF25
- Charge utile~3 kg in specific postures; ≤1 kg across full workspace
- Batterie / autonomie~500Wh; ~2 h continuous walking (at 0.5 m/s)
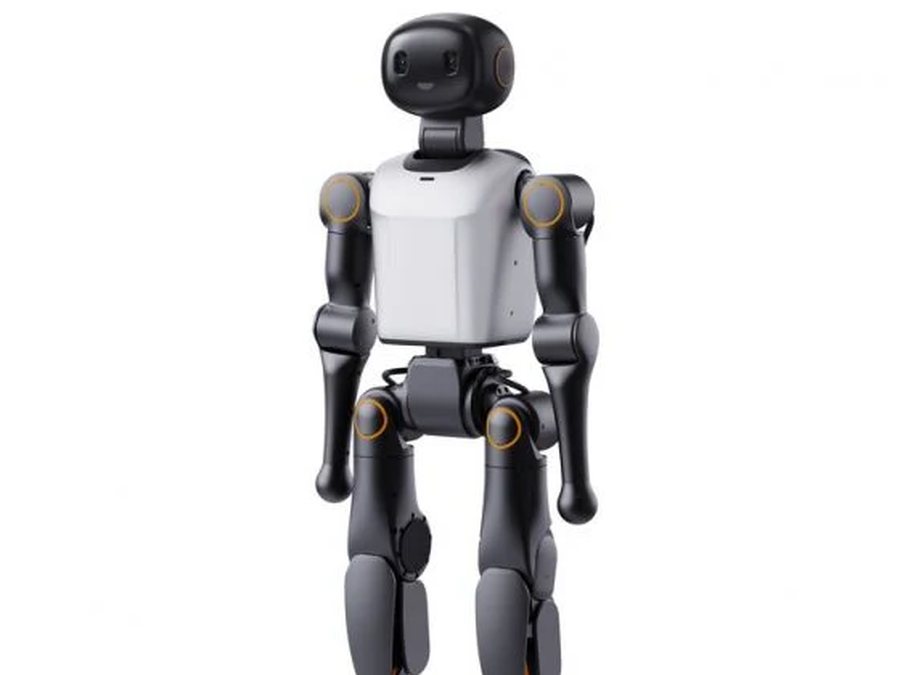
Booster K1
Geek / Education / Professional · Nouveau
- Taille~95cm
- Poids19.5 kg
- DOF22
- Batterie / autonomie2Ah; ~20 min (official figure, walking at 1.1 m/s)
- Vitesse max.2 m/s (walking speed per official site)
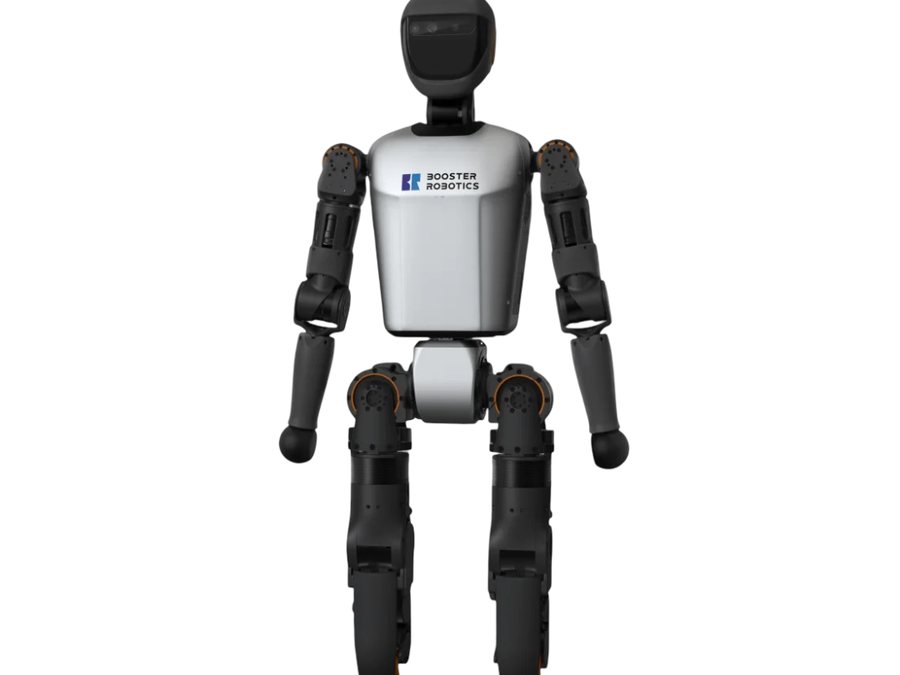
Booster T1
Basic / Standard / Customized · Nouveau
- Taille118cm (118×47×23cm)
- Poids30 kg
- DOF23
- Batterie / autonomie10.5Ah battery; ~2 h walking, ~4 h standing
- Vitesse max.0.5 m/s (walking speed per manual; top speed not published)
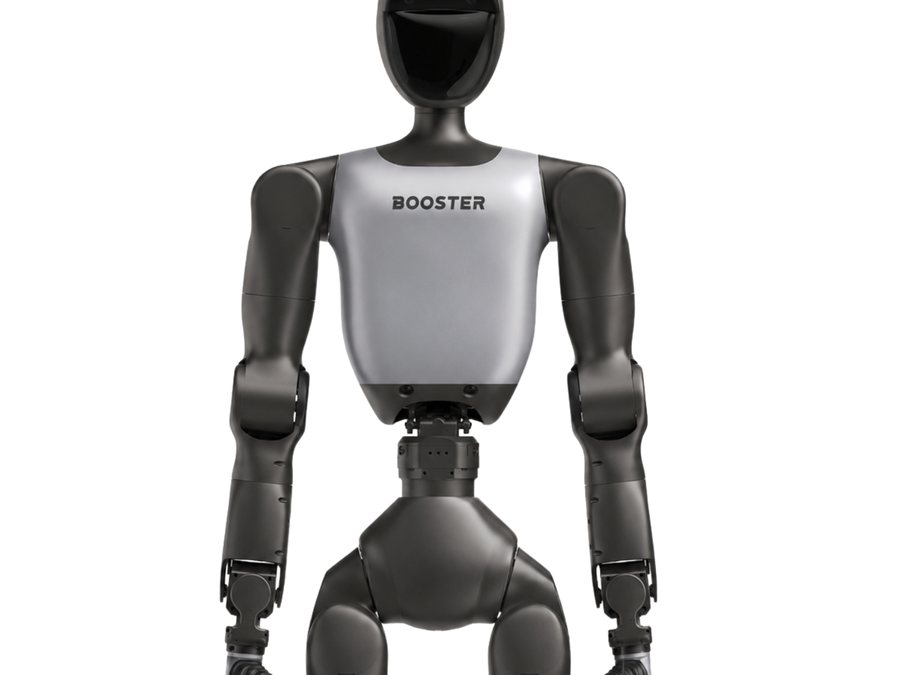
Booster T2
P1 / P2 Claw / P3 Nimble Hands · Nouveau
- Taille140cm
- Poids~42 kg
- DOF31
- Charge utileMax 10 kg both arms (base configuration, no end effector)
- Batterie / autonomie48V 10Ah; ~2 h continuous walking
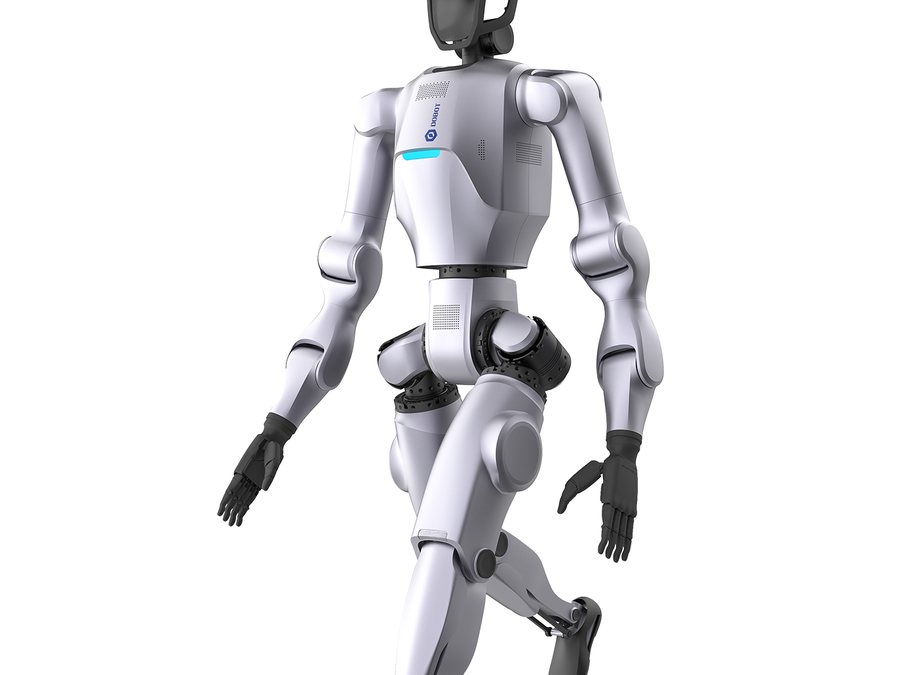
Dobot Atom
Base · Nouveau
- TailleHeight ~1530mm
- Poids62 kg
- DOF41 (incl. dexterous hands; 29 without hands)
- Charge utile3.5 kg per arm
- Batterie / autonomie~2 h
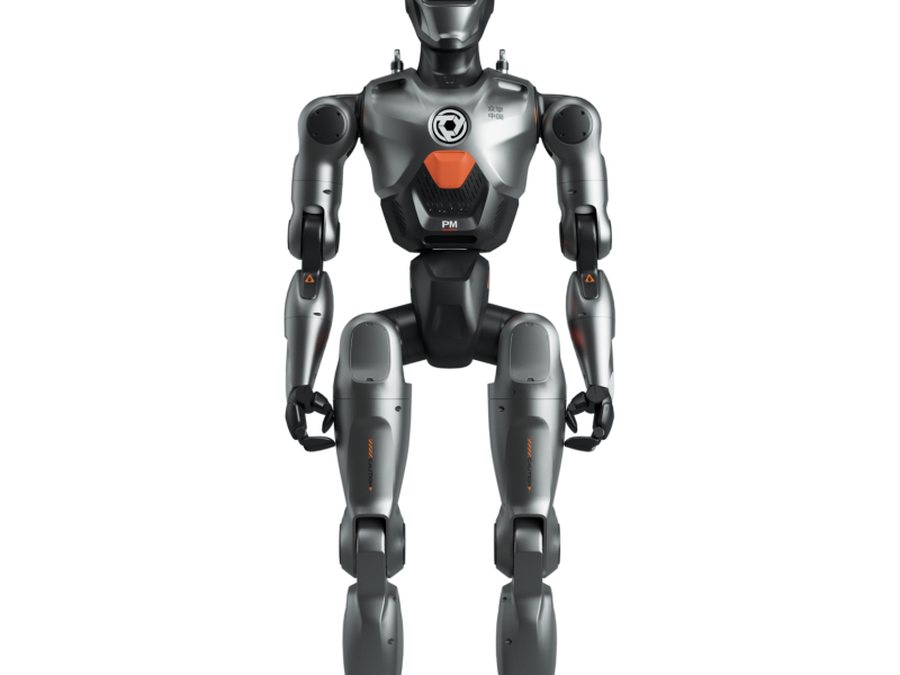
EngineAi PM01
Commercial / Education · Occasion
- Taille138cm (manual: 1388×490×220 mm)
- Poids~40 (manual spec table ~43 incl. battery — sources differ)
- DOF23 (manufacturer headline says 24-DOF)
- Batterie / autonomie~2 h (10,000mAh quick-release battery)
- Vitesse max.2m/s
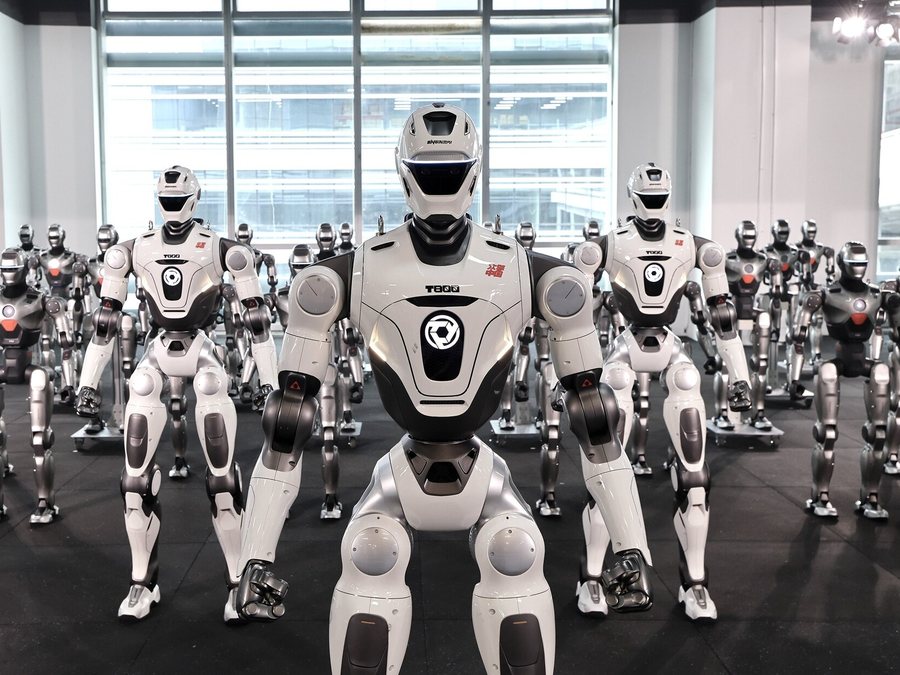
EngineAi T800
Base / Education / Pro · Nouveau
- Taille173cm (legs 91 cm, arms 60 cm)
- Poids75 (incl. battery, per launch materials)
- DOF25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands)
- Batterie / autonomie4–5 h (solid-state battery, per manufacturer launch)
- Vitesse max.≥3 m/s (hardware-capable)
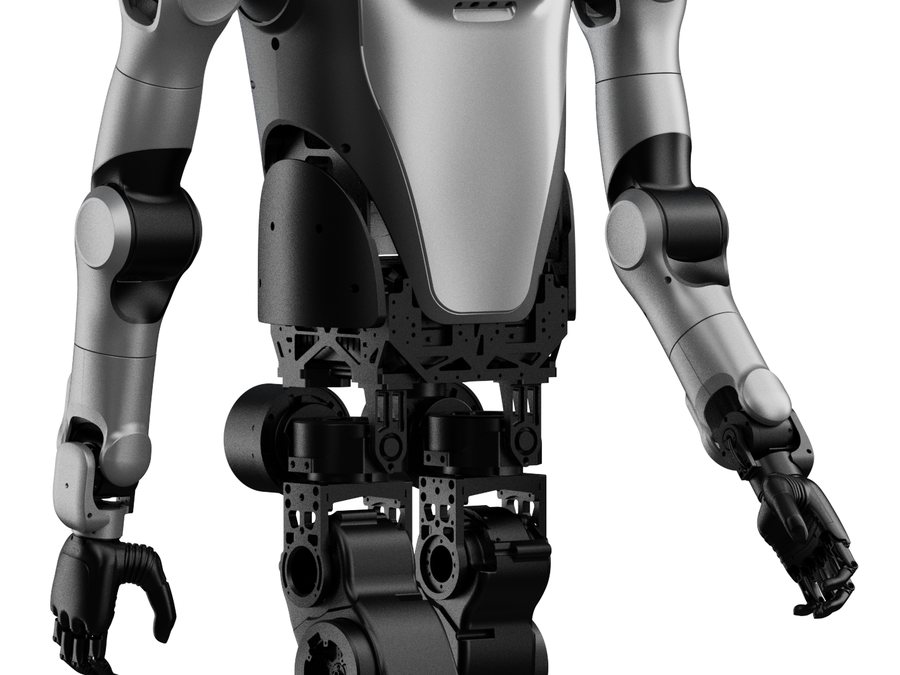
Leju Robotics Kuavo 4Pro
Base · Nouveau
- TailleHeight ~1660mm
- Poids55 kg
- DOF40+
- Vitesse max.>7 km/h (running)
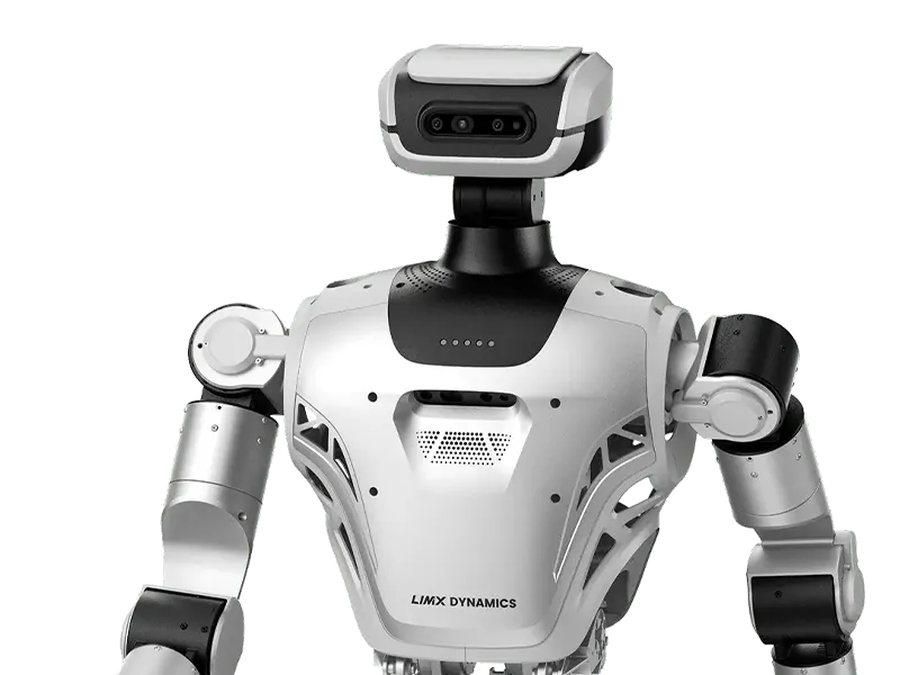
LimX Dynamics Oli
Lite / Edu / Super · Nouveau
- Taille165cm (shoulder width ≈55 cm, arm length ≈70 cm)
- Poids≤55 (incl. battery)
- DOF31 (body only, excl. end effectors)
- Batterie / autonomie~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery)
- Vitesse max.Max walking speed 5 km/h
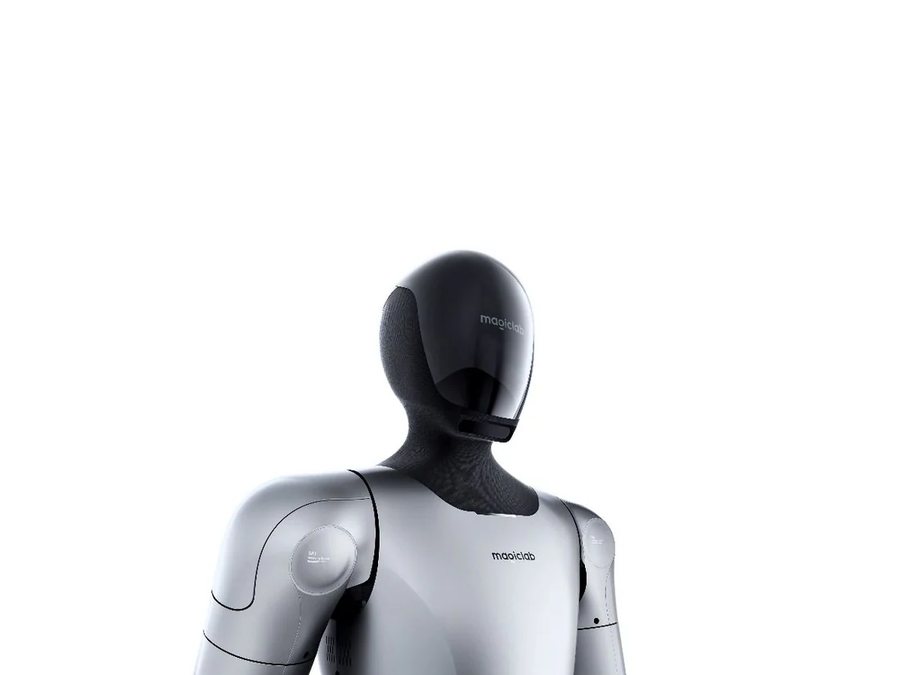
MagicBot Gen1
Base · Nouveau
- Taille1740×580×280mm (174cm)
- Poids~70 kg
- DOF42 (active DOF)
- Charge utile7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg)
- Batterie / autonomie3–5 h (25Ah / 1.35kWh battery)
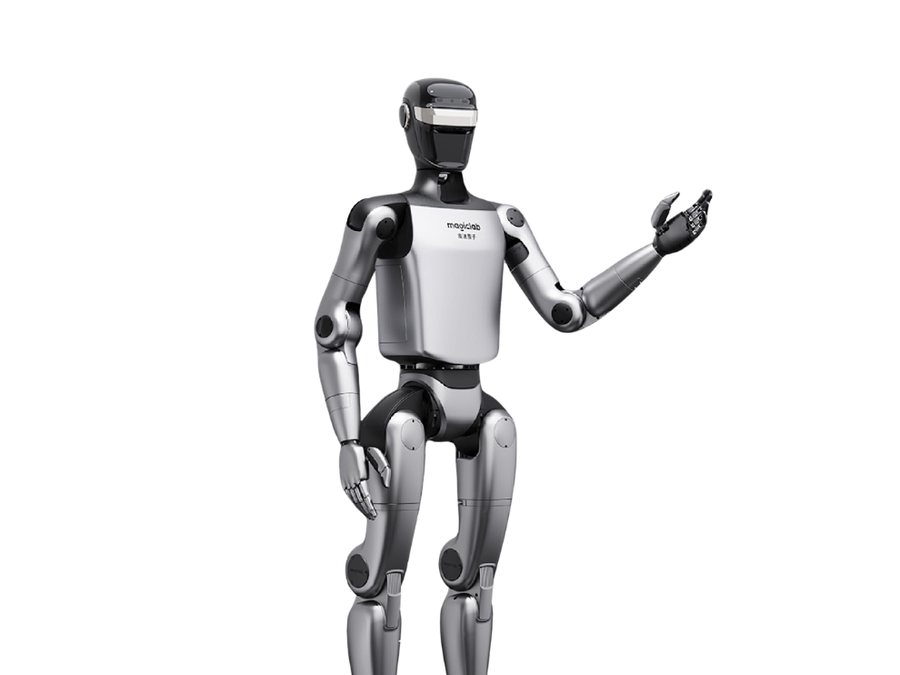
MagicBot Z1
Base · Nouveau
- Taille~140cm (Developer version 136.9 cm, 1369×422×200 mm)
- Poids~40 (incl. battery)
- DOF24 (base; expandable to 49/50 per different sources)
- Charge utileMax 3 kg per arm
- Batterie / autonomie~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual)
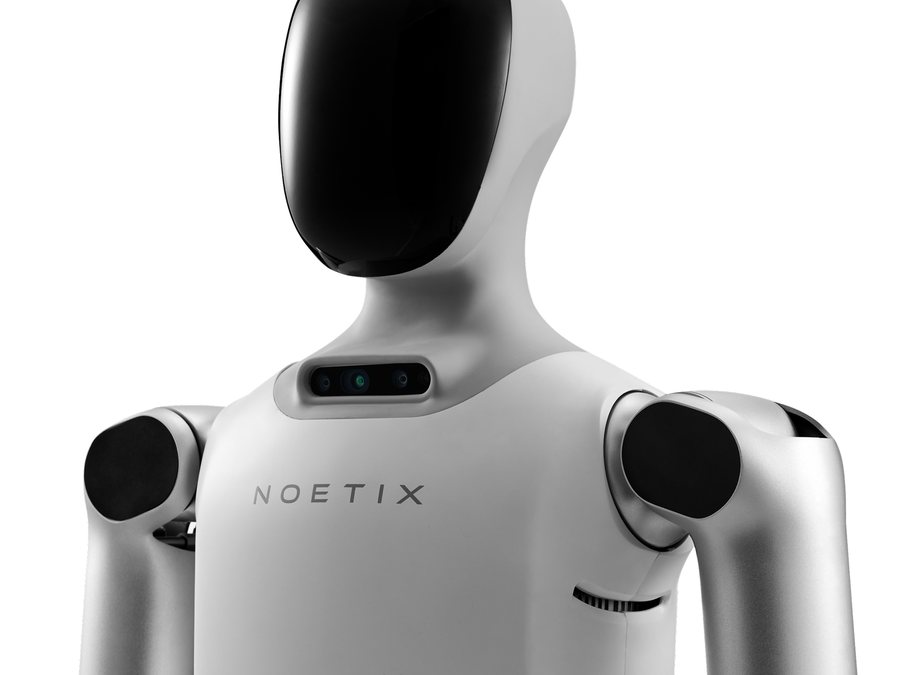
Noteix E1
Standard / Edu · Occasion
- Taille136×47×29cm
- Poids~36 kg
- DOF23 (manufacturer manual) / 21 (press release) — sources conflict
- Batterie / autonomie1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict
- Vitesse max.Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence)
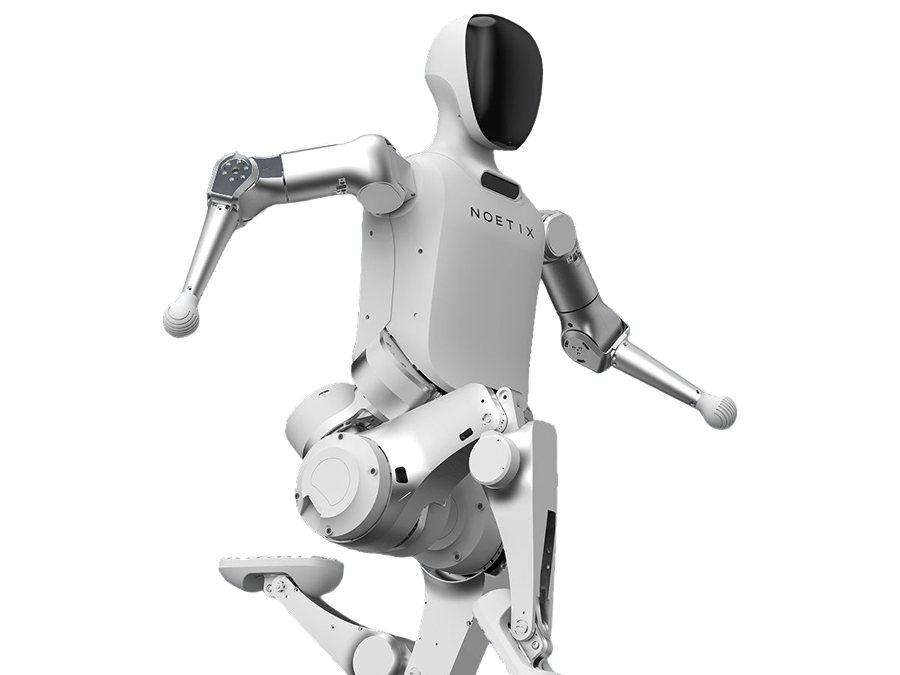
Noteix N2
Standard / Edu · Occasion
- Taille118 cm H × 47 cm W
- Poids~30 (another compilation lists 29)
- DOF18
- Charge utile~5 (carried while walking continuously)
- Batterie / autonomie1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min)
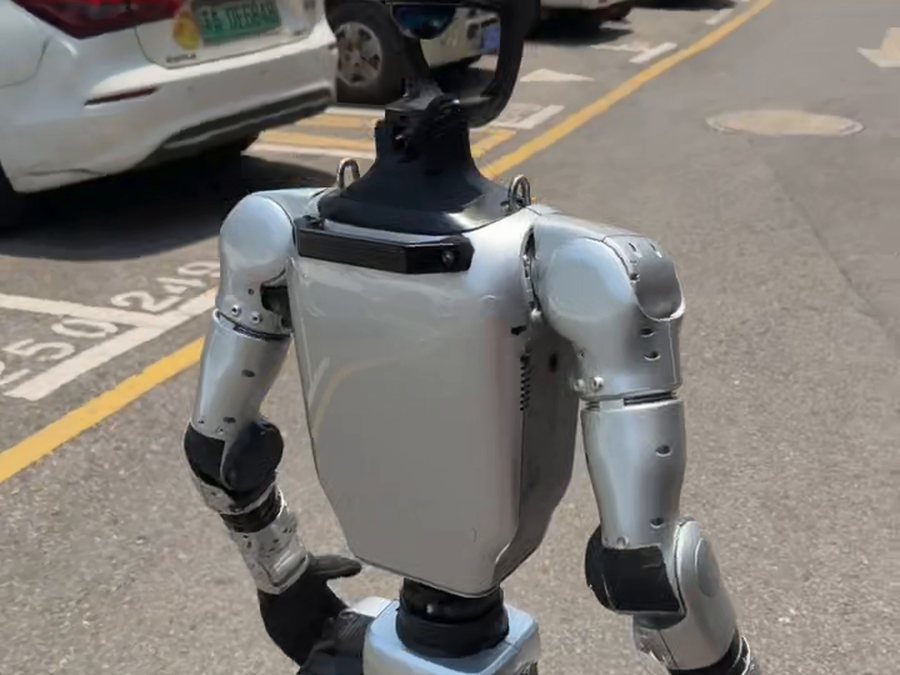
Unitree G1
Basic / U1 / U2 · Occasion
- Taille1320×450×200mm (Standing )
- Poids35 kg
- DOF23
- Charge utile~2 (per arm)
- Batterie / autonomie~2 h
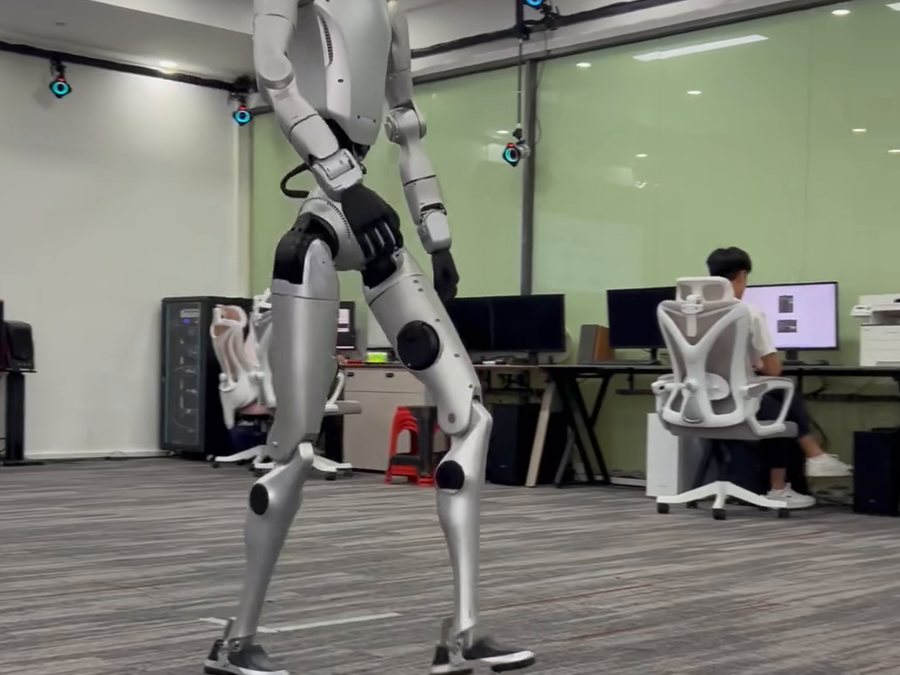
Unitree H2
Basic / EDU · Nouveau
- Taille~182cm
- Poids70 kg
- DOF31
- Charge utile~7 (peak 21)
- Batterie / autonomie~3 h
Robots quadrupèdes
Plateformes à quatre pattes pour la recherche, la pratique d’inspection, l’éducation et les démonstrations — neuves et d’occasion.
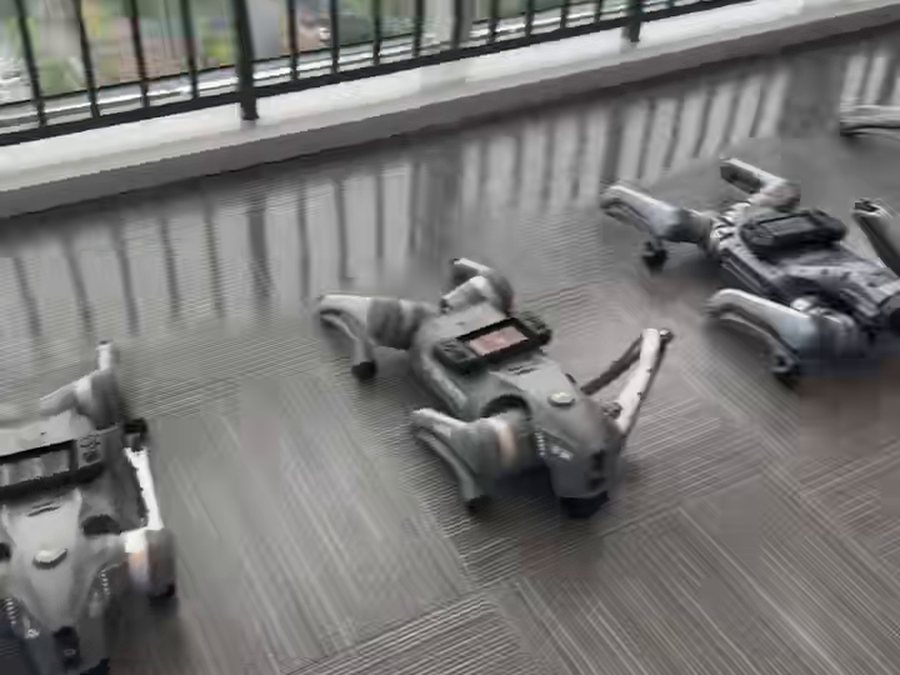
Les robots à quatre pattes gagnent leur place là où les roues ne peuvent pas aller : escaliers, gravier, herbe et terrain cassé. Notre gamme de quadrupèdes va des plateformes éducatives compactes aux machines industrielles d’inspection, neuves et d’occasion. Si vous n’êtes pas sûr de la classe de taille qu’il vous faut, dites-nous le terrain et la charge utile — c’est ce qui décide.
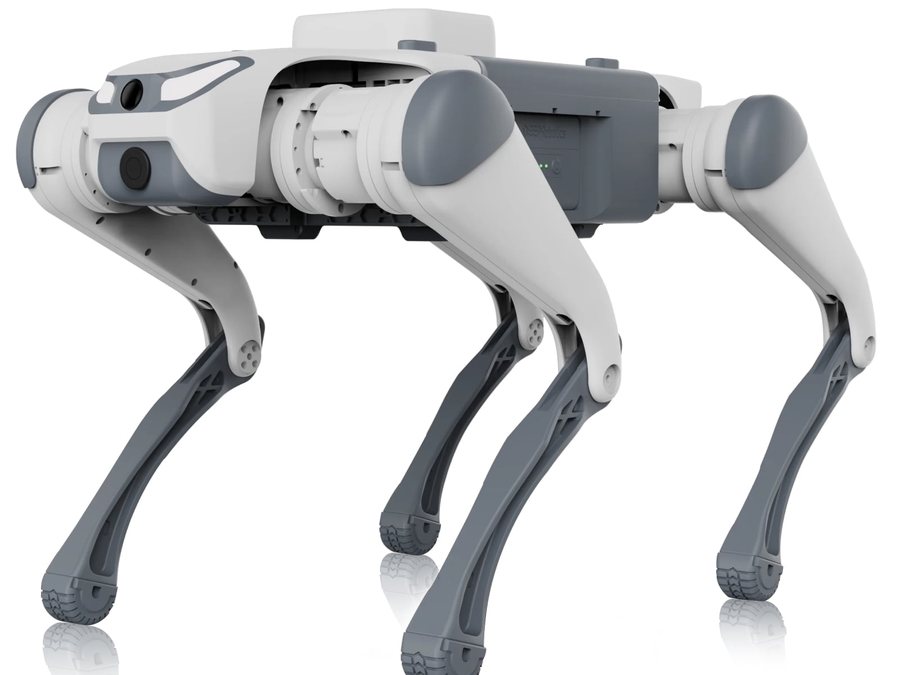
Deep Robotics Lite3
Basic / Venture / Pro / LiDAR · Occasion et neuf
- TailleStanding 610×370×406mm
- Poids12 kg
- DOF12
- Charge utileWalking payload 5
- Batterie / autonomie1.5–2 h
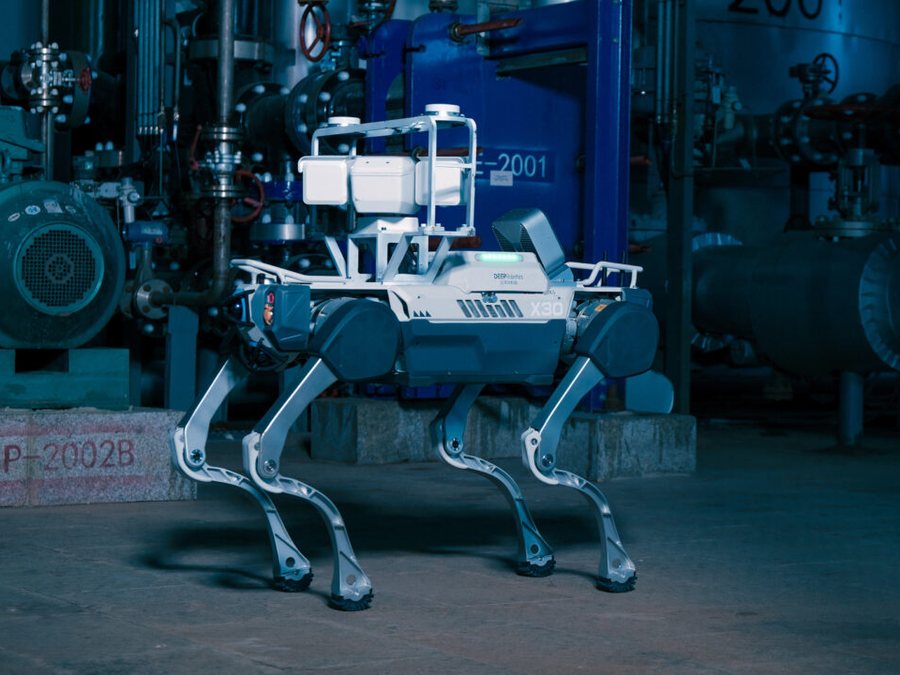
Deep Robotics X30
Basic / Pro · Occasion
- TailleStanding 1000×585×470mm
- Poids56 kg
- DOF12
- Charge utileRated payload ≥20 (max 85)
- Batterie / autonomie2.5–4 h
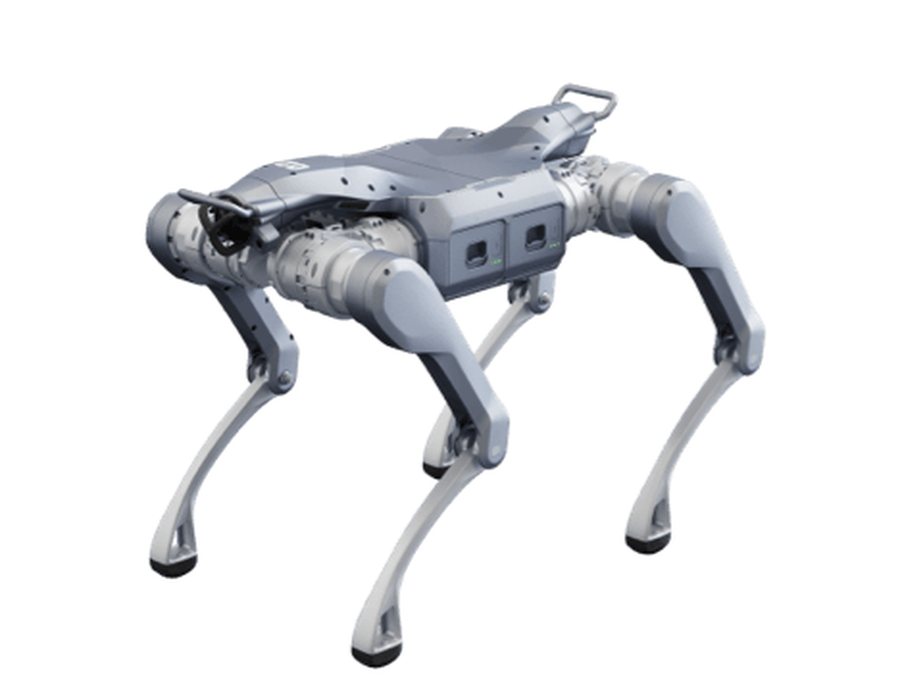
Unitree A2
Base · Nouveau
- Taille820×440×570mm
- Poids~37 (incl. dual batteries)
- DOF12
- Charge utile~25 (walking; standing max ~100)
- Batterie / autonomie~5 h unloaded / ~3 h with 25 kg payload
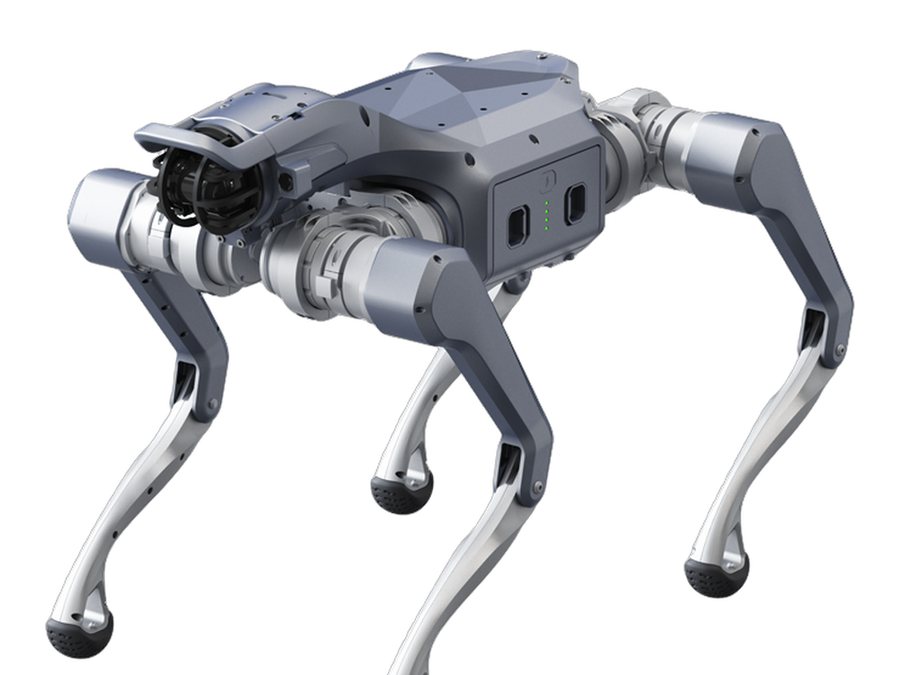
Unitree As2
EDU U1 / EDU U2 / EDU U3 / EDU U4 · Nouveau
- Poids18 kg
- DOF12
- Charge utile~15 (walking; standing max ~65)
- Batterie / autonomie>4 h unloaded
- Vitesse max.3.7 m/s (peak 5)
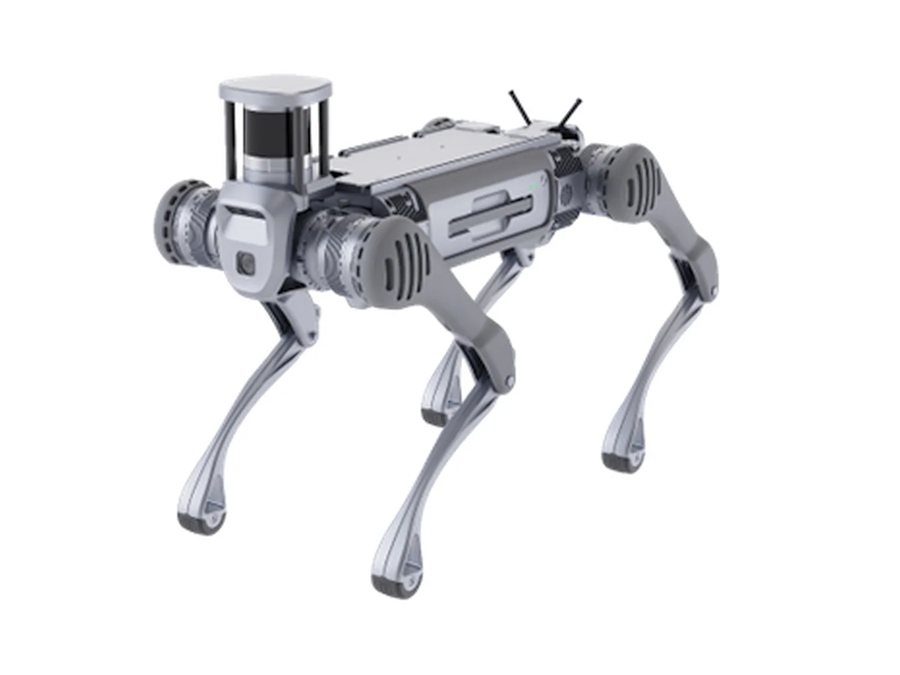
Unitree B2
Base · Occasion
- Taille~1098×450×645mm
- Poids~60 kg
- DOF12
- Charge utileWalking >40 (standing max 120)
- Batterie / autonomie~4–6 h
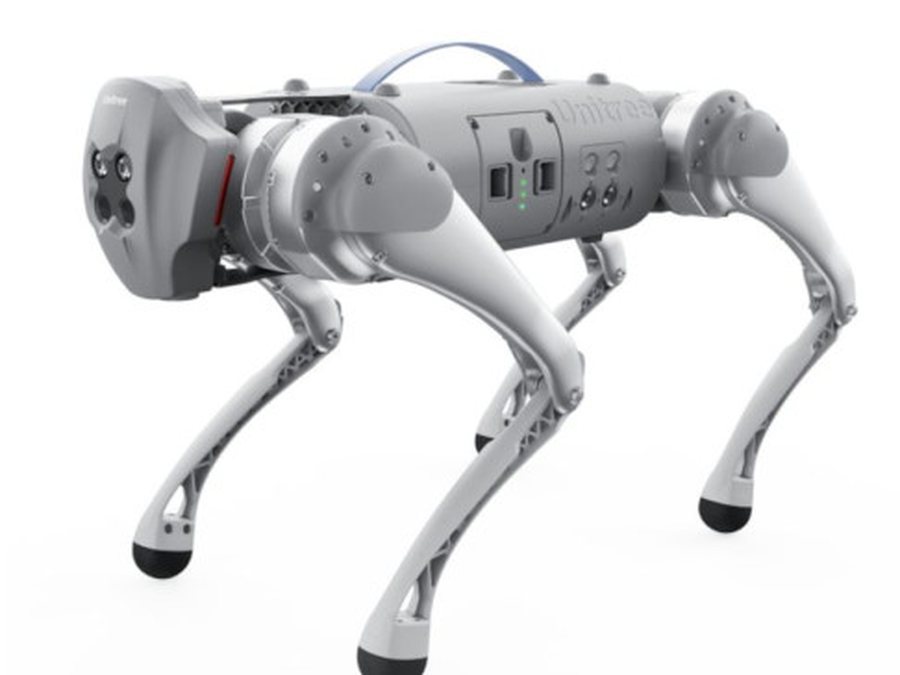
Unitree Go1 Air
Base · Occasion
- Taille645×280×400mm
- Poids12 kg
- DOF12
- Charge utile~3
- Batterie / autonomie~1 h
Unitree Go1 Pro
Base · Occasion
- Taille645×280×400mm
- Poids12 kg
- DOF12
- Charge utile~3
- Batterie / autonomie~1.5 h
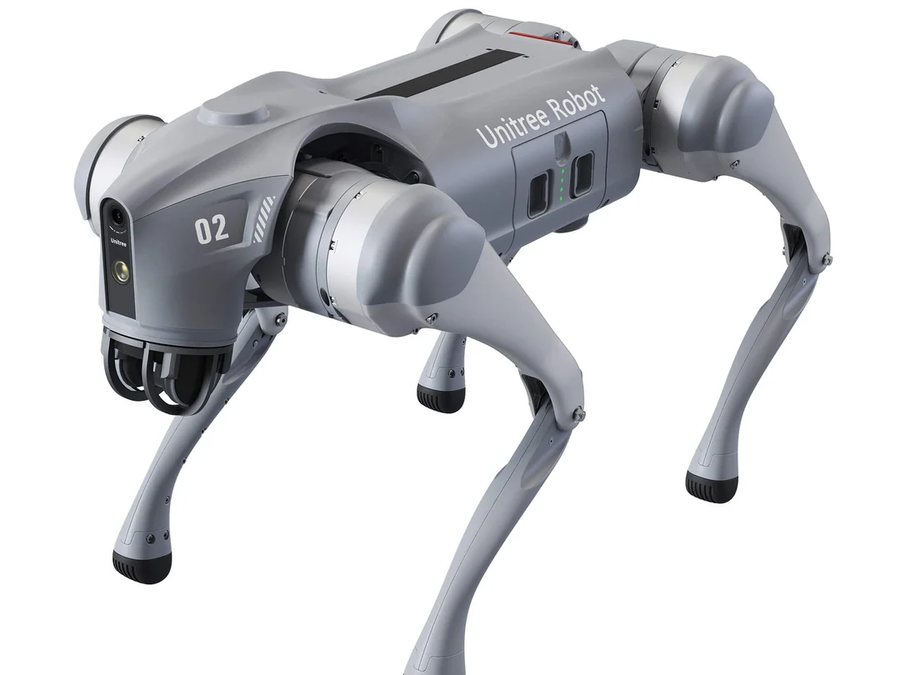
Unitree Go2 Air
Base · Occasion
- Taille700×310×400mm
- Poids15 kg
- DOF12
- Charge utile~7 (max ~10)
- Batterie / autonomie~1–2 h
Unitree Go2 Edu
Base · Occasion
- Taille700×310×400mm
- Poids15 kg
- DOF12
- Charge utile~8 (limit 10)
- Batterie / autonomie~2–4 h (15,000mAh long-life battery)
Unitree Go2 Pro
Base · Occasion
- Taille700×310×400mm
- Poids15 kg
- DOF12
- Charge utile~7 (max ~10)
- Batterie / autonomie~1–2 h
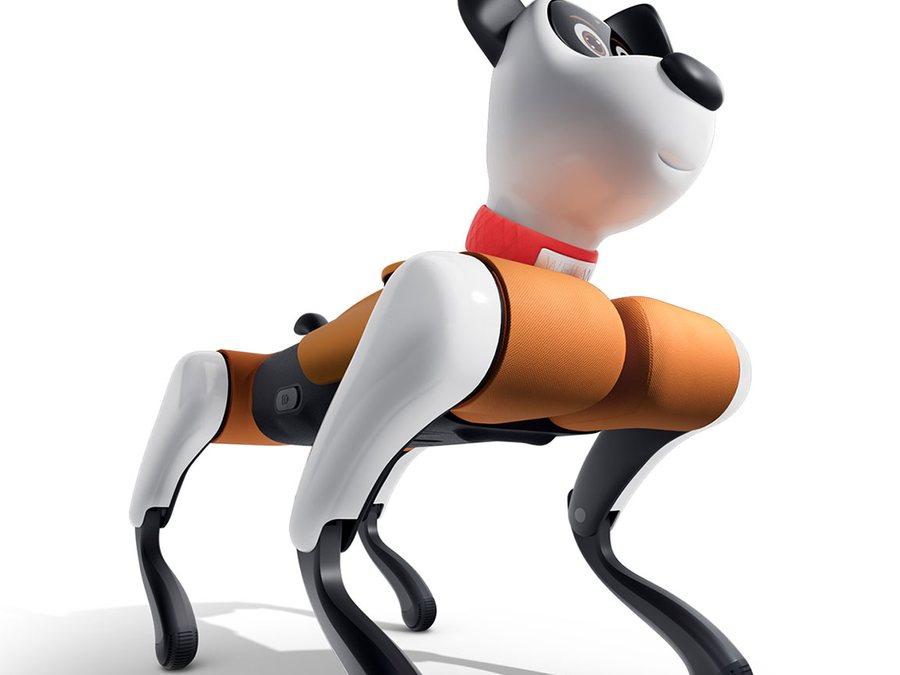
WEILAN Baby Alpha A2
Standard / Plus / Pro / Ultra · Occasion
- Batterie / autonomie~120 min (media report only; not published by manufacturer)
- Vitesse max.6.0 km/h (single media source, low–medium confidence)
Robots à roues et à pattes à roues
Quadrupèdes à pattes à roues qui roulent sur sol plat et franchissent les obstacles — pour le travail intérieur/extérieur où les roues seules ne suffisent pas.
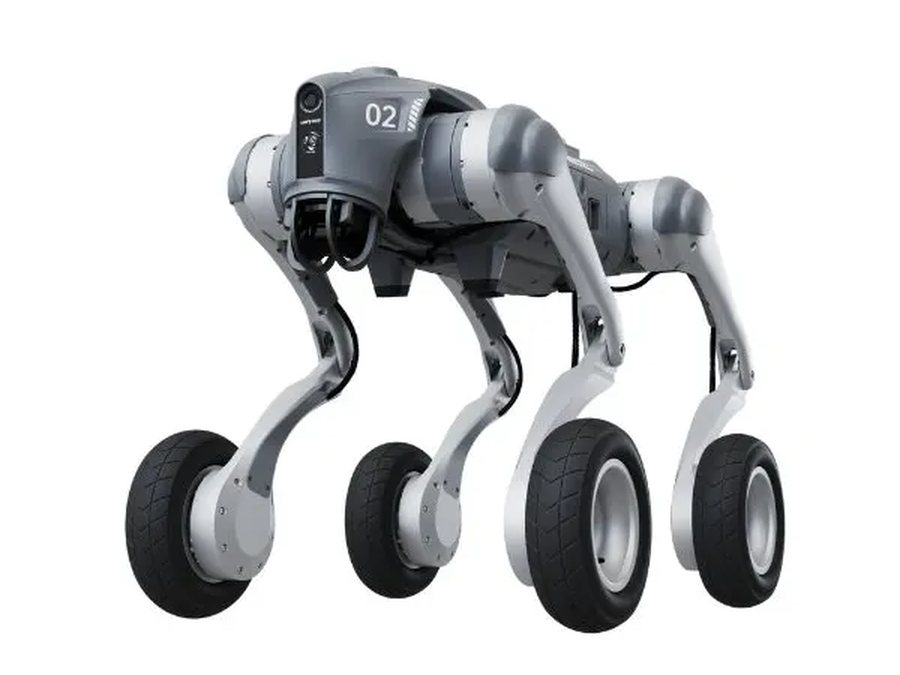
Les robots à roues et à pattes à roues échangent un peu de capacité tout-terrain contre vitesse, endurance et stabilité sur le sol que la plupart des sites ont réellement — sols, cours, trottoirs et rampes. Cette section couvre nos quadrupèdes à pattes à roues ; si votre site est surtout fait de surfaces dures avec une marche ou une pente occasionnelle, commencez ici.
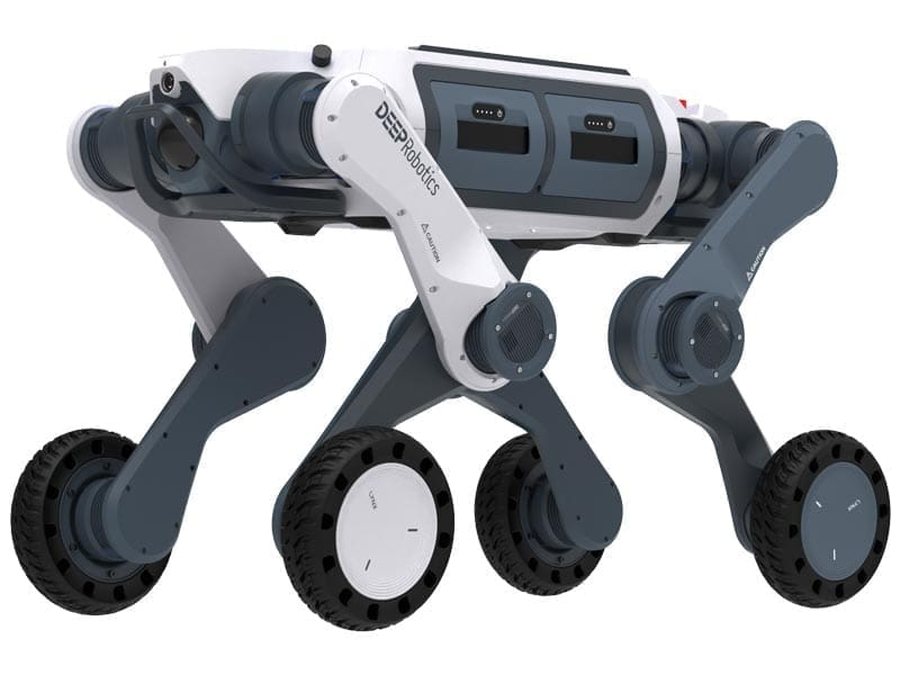
Deep Robotics M20
Basic / Pro · Nouveau
- TailleStanding 820×430×570mm
- Poids33 kg
- DOF16
- Charge utileRated payload 15 (max 50)
- Batterie / autonomie3 h unloaded / 2.5 h loaded
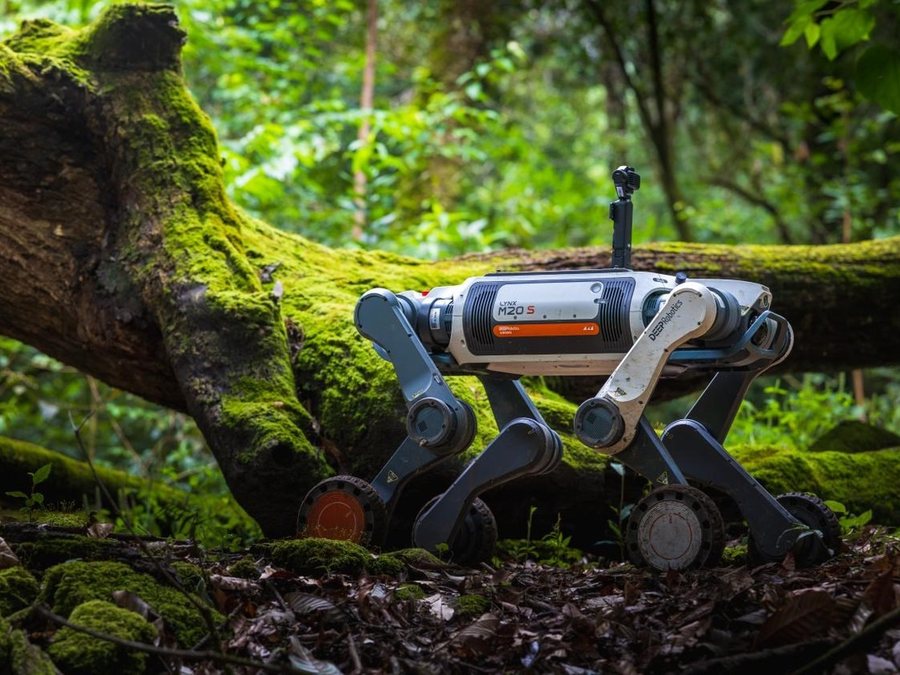
Deep Robotics M20S
New
- Poids33 (manufacturer states weight unchanged from M20 Pro)
- Charge utileContinuous payload 35 kg (flat terrain)
- Batterie / autonomie3.5–5 h unloaded / 2.5–3.5 h loaded
- Vitesse max.9 m/s
Unitree Go2-W
Standard Edition / Smart Edition / Laser Edition · Nouveau
- Taille700×430×500mm
- Poids18 kg
- DOF16 (12 leg joints + 4 hub motors)
- Charge utile~8 (max ~12)
- Batterie / autonomie~2–4 h
Bras robotiques
Bras pour plateformes de recherche humanoïdes et quadrupèdes, adaptés à votre robot et à vos exigences de charge utile.
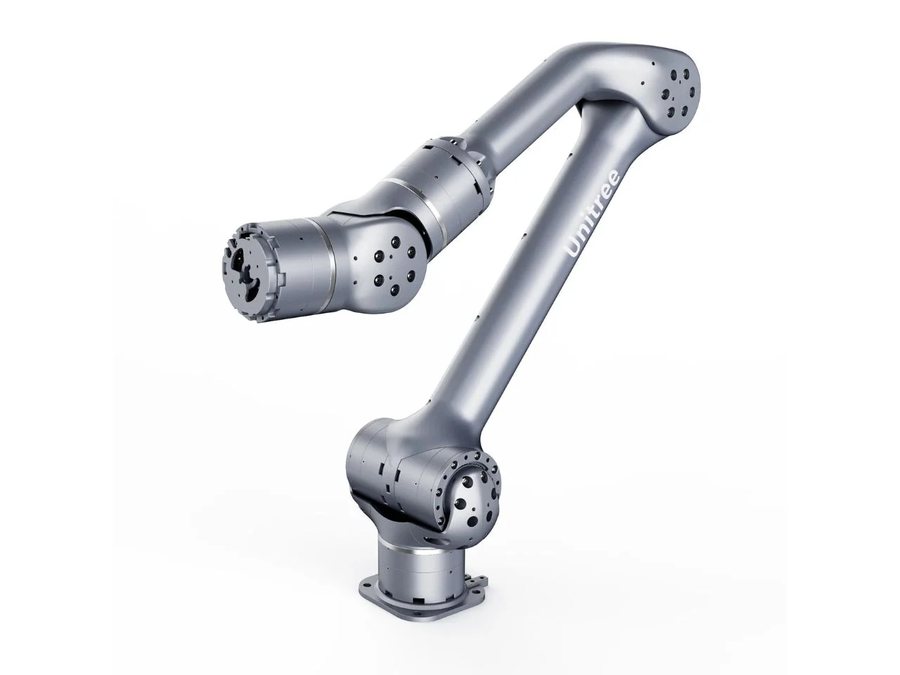
Bras robotiques
Dites-nous la plateforme sur laquelle vous le monterez et la charge utile qu’il vous faut — nous adapterons un bras et le chiffrerons par spécification, avec le robot ou seul.
Robots d’occasion
Les versions d’occasion de nombreux modèles ci-dessus sont en stock — chacune inspectée, avec un rapport d’état et une vidéo de l’unité réelle.
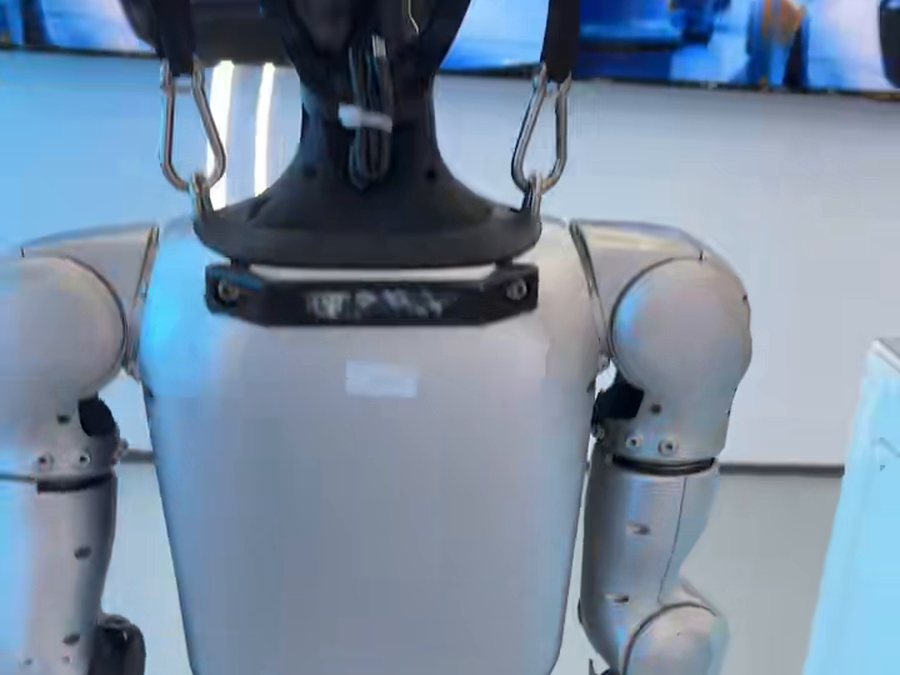
Stock d’occasion
Les prix d’occasion sont une fraction du prix du neuf pour le même modèle. Dites-nous le modèle que vous cherchez et nous vous enverrons le rapport d’état et le prix de l’unité en stock.
Comment fonctionne l’occasion · Demander le stock d’occasion
Pièces pour constructeurs de robots
Une gamme à part pour les équipes qui construisent leurs propres robots — des composants, pas des machines complètes.
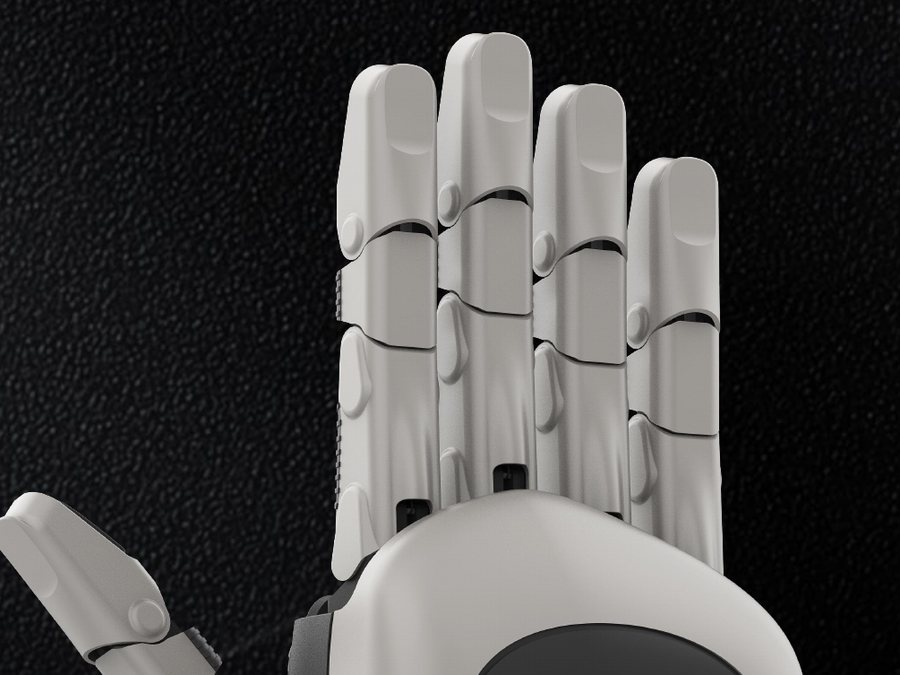
Si votre équipe développe ses propres robots, nous fournissons aussi les pièces qui les composent : moteurs d’articulation et modules d’articulation, mains dextres — la gamme BrainCo Revo 2 (Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 par main, les seuls prix catalogue de cette section) et les Dexrobot DexHand 021 et DexHand 021 S (prix à confirmer) — plus bras robotiques, batteries et contrôleurs. Dites-nous le type, les spécifications et la quantité qu’il vous faut — nous chiffrons par article.
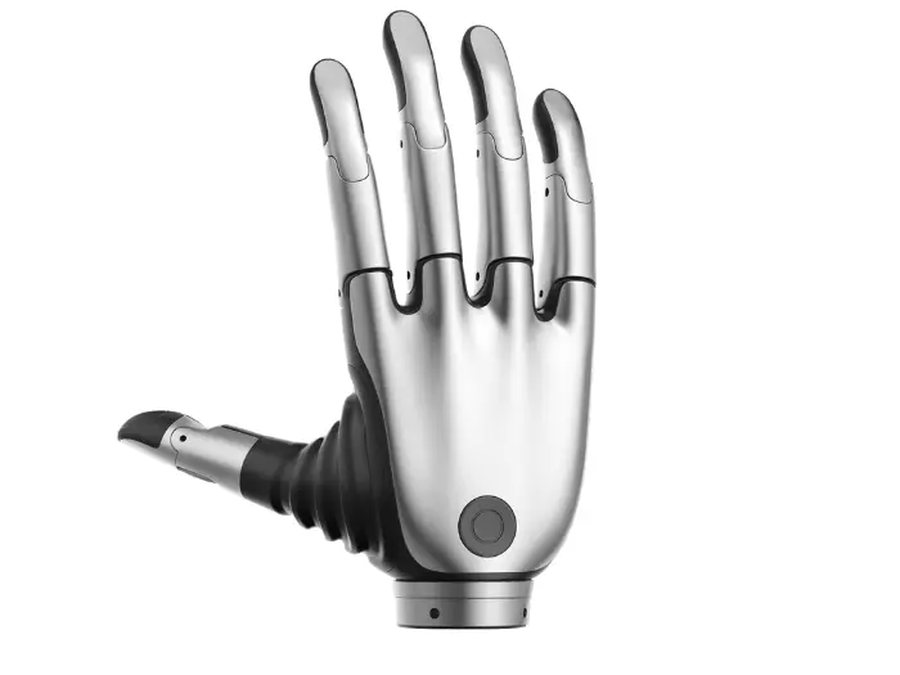
Mains dextres — Revo 2
Mains dextres de la série Revo 2 : Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 par main. D’autres mains dextres sont aussi disponibles — envoyez-nous votre spécification.
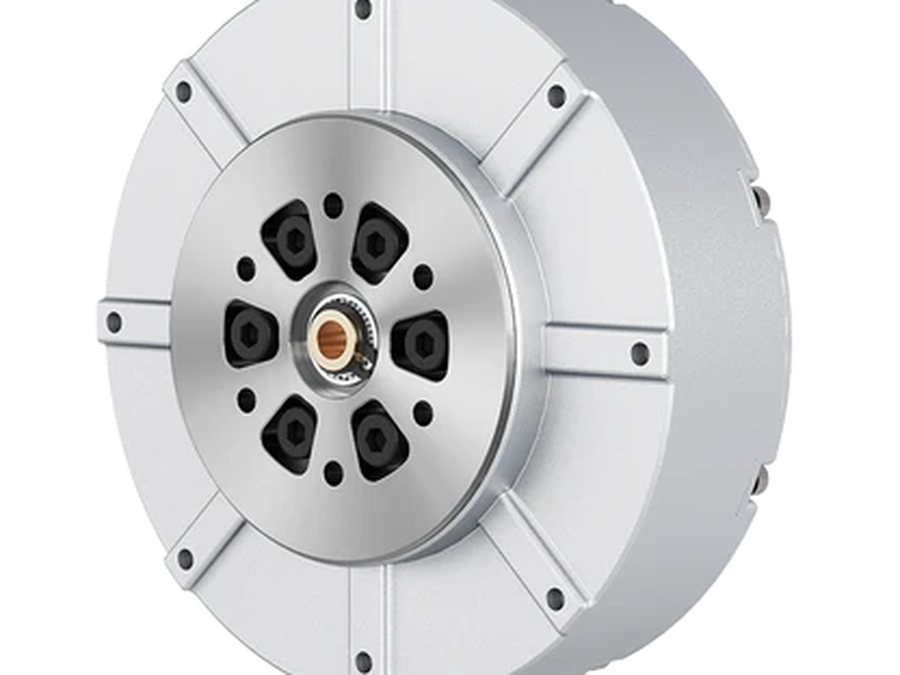
Moteurs et modules d’articulation
Moteurs d’articulation et modules d’articulation pour robots développés par vos soins. Envoyez-nous le type, la spécification et la quantité qu’il vous faut et nous chiffrerons article par article.
Batteries et contrôleurs
Batteries, télécommandes et autres accessoires pour les plateformes que nous fournissons — prix par spécification sur demande. Plus de pièces dans notre boutique dédiée : Robosparex — pièces et accessoires.
Liste complète des modèles avec spécifications
Tous les modèles que nous fournissons actuellement, avec leurs spécifications clés. L’état indique si la version listée est neuve ou d’occasion ; beaucoup de modèles sont disponibles dans les deux — demandez-nous. Vous pouvez aussi télécharger cette liste (Excel).
| Modèle | Variante | État | Type | Dimensions | Poids (kg) | DOF | Charge utile (kg) | Batterie / autonomie | Vitesse max. | Support de développement |
|---|---|---|---|---|---|---|---|---|---|---|
| AgiBot A2 | Young Edition | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 63 | 23 | ~2 kg per arm | Battery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet) | Max walking 0.8 m/s (dealer spec sheet) | AimMaster/AimDK choreography and interaction customization tools (performance & presentation use); full low-level SDK openness not clearly stated by the manufacturer |
| AgiBot A2 | Flagship | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 69 | 40+ (active DOF) | ~3 kg per arm | 700Wh; ~2 h (hot-swappable battery) | Max walking 1.2 m/s (after V1.3 OTA update) | Secondary development supported: AimDK (HTTP JSON-RPC + ROS2 Topic interfaces, AimRT framework) |
| AgiBot X2 | Basic Version | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 35 | 25 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh; ~2 h continuous walking (at 0.5 m/s) | 1.8m/s | No secondary development (no public SDK, locked system; development open on Ultra only) |
| AgiBot X2 | Ultra | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) |
| AgiBot X2 | Ultra | Used | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking (pre-owned unit; hardware identical to new) | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) (pre-owned unit; hardware identical to new) |
| AgiBot A3 | Basic Version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (AimDK development only on the Development version) |
| AgiBot A3 | Development version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open AimDK development SDK (HTTP JSON-RPC + ROS2 Topic interfaces) |
| AgiBot A3 Ultra | Basic Version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (Open SDK + ROS2 only on Development/EDU versions) |
| AgiBot A3 Ultra | Development version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK), full development documentation included |
| AgiBot A3 Ultra | Embodied version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | No separate official statement found on this version's software entitlements (hardware as A3 Ultra) |
| AgiBot A3 Ultra | EDU | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK); education/research software and support package |
| Booster K1 | Geek | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 2Ah; ~20 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (this version: 48 TOPS compute) |
| Booster K1 | Education | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~80 min | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (117 TOPS, Jetson Orin NX) |
| Booster K1 | Professional | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~70 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (200 TOPS, Jetson AGX Orin) |
| Booster T1 | Basic | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); no Intel host on this version (AGX Orin 200 TOPS only). Note: one third-party database claims the Basic version lacks SDK support, contradicting official developer docs — confirm with the manufacturer before ordering |
| Booster T1 | Standard | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); AGX Orin 200 TOPS + Intel i7-1370P host |
| Booster T1 | Customized | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 31 (gripper version) / 41 (dexterous-hand version) | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); 7-DOF arms, optional gripper or 6-DOF dexterous hands; compute as Standard |
| Booster T2 | P1 | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (base configuration, no end effector) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P2 Claw | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (standard gripper configuration) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P3 Nimble Hands | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (6-DOF dexterous hands) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Deep Robotics Lite3 | Basic | New | Quadruped | Standing 610×370×406mm | 12 | 12 | Walking payload 5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Venture | Used | Quadruped | Standing 610×370×445mm | 12.2 | 12 | Walking payload 4.5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Pro | Used | Quadruped | Standing 610×370×450mm | 12.9 | 12 | Walking payload 4 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | LiDAR | Used | Quadruped | Standing 610×370×496mm | 13.5 | 12 | Walking payload 2.5 | 1.5–2 h | 4 m/s | Motion control SDK, perception development sample code and communication protocols (ROS1/ROS2) |
| Deep Robotics M20 | Basic | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Business development interfaces (Gigabit Ethernet, 72V power interface) |
| Deep Robotics M20 | Pro | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Secondary development supported (Gigabit Ethernet, USB 3.0, 24V/72V power interfaces, SLAM mapping & navigation) |
| Deep Robotics X30 | Basic | Used | Quadruped | Standing 1000×585×470mm | 56 | 12 | Rated payload ≥20 (max 85) | 2.5–4 h | ≥4 m/s | Secondary development supported |
| Deep Robotics X30 | Pro | Used | Quadruped | Standing 1000×585×470mm | 59 | 12 | 20 (max 85) | 4 h unloaded / 2.5 h loaded | ≥4 m/s | Secondary development supported (industrial-grade SDK interfaces) |
| Deep Robotics M20S | — | New | Quadruped (wheeled-leg) | Not published | 33 (manufacturer states weight unchanged from M20 Pro) | Not published | Continuous payload 35 kg (flat terrain) | 3.5–5 h unloaded / 2.5–3.5 h loaded | 9 m/s | Not published |
| Dobot Atom | Base | New | Humanoid | Height ~1530mm | 62 | 41 (incl. dexterous hands; 29 without hands) | 3.5 kg per arm | ~2 h | 1.5 m/s (walking) | SDK secondary development supported (official SDK development guide available) |
| EngineAi PM01 | Commercial | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | No secondary development (manufacturer manual lists openness as "not supported"); the manufacturer also publishes EngineAI ROS (ROS2-based) open resources |
| EngineAi PM01 | Education | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | Open platform: x86 + NVIDIA Jetson Orin dual chips, open training/deployment code, secondary development supported; ROS2 (EngineAI ROS framework); native SDK (pm01_edu) via GitHub mirror, not directly from the official site |
| EngineAi T800 | Base | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery, per launch materials) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | No secondary development |
| EngineAi T800 | Education | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery; dealers cite 75–85 depending on version) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported (official Eco/open-source edition ≈ this Education version: stereo vision/LiDAR + AGX Orin 64G); dedicated official T800 SDK documentation not found |
| EngineAi T800 | Pro | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75–85 (varies by version, per dealers) | 43 (29 body + 7×2 hands) | Dexterous hand 5 kg per hand (whole-body / per-arm payload not published) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported |
| Leju Robotics Kuavo 4Pro | Base | New | Humanoid | Height ~1660mm | 55 | 40+ | Not published | Not published | >7 km/h (running) | Fully open motion-control and application development interfaces (open-source HarmonyOS) |
| LimX Dynamics Oli | Lite | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors) | Not published (same-series EDU/Super: max 3 kg per arm; no per-variant data for Lite) | ~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| LimX Dynamics Oli | Edu | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors; RobotShop lists 33 — unconfirmed) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development (plus C++/JavaScript examples); ROS2 (official GitHub); Isaac Sim/MuJoCo/Gazebo support |
| LimX Dynamics Oli | Super | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 33 (body only, excl. end effectors) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| Noteix N2 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | No secondary development; no official ROS2/Python statement found |
| Noteix N2 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | Secondary development supported (adds NVIDIA Jetson Orin Nano Super compute, depth camera; optional spherical hands / five-finger hands); no official ROS2/Python statement found |
| Noteix E1 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Base compute 6 TOPS (RK3588s); no open-SDK statement found; no official ROS2/Python statement found |
| Noteix E1 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Open SDK interfaces (velocity/motion commands and joint-level algorithm control), 6+67 TOPS compute (adds Jetson Orin Nano Super, depth camera); no official ROS2/Python statement found |
| Unitree G1 | Basic | Used | Humanoid | 1320×450×200mm (Standing ) | 35 | 23 | ~2 (per arm) | ~2 h | 2 m/s | No secondary development (no SDK; remote control / app demos only) |
| Unitree G1 | U1 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Jetson Orin compute module) |
| Unitree G1 | U2 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 (expandable) | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Orin NX 100 TOPS) |
| Unitree H2 | Basic | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | No official secondary-development support found (only the EDU version explicitly supports it) |
| Unitree H2 | EDU | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | Secondary development supported (EDU version; compute module customizable) |
| Unitree Go1 Air | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1 h | 2.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go1 Pro | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1.5 h | 3.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go2 Air | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 2.5 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Pro | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 3.7 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Edu | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~8 (limit 10) | ~2–4 h (15,000mAh long-life battery) | 3.7 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python; optional Jetson Orin expansion dock) |
| Unitree Go2-W | Standard Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Smart Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Laser Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree A2 | Base | New | Quadruped | 820×440×570mm | ~37 (incl. dual batteries) | 12 | ~25 (walking; standing max ~100) | ~5 h unloaded / ~3 h with 25 kg payload | 3.7 m/s (up to ~5) | Secondary development supported (Intel i7 development compute, ROS/ROS2) |
| Unitree As2 | EDU U1 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U2 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U3 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U4 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree B2 | Base | Used | Quadruped | ~1098×450×645mm | ~60 | 12 | Walking >40 (standing max 120) | ~4–6 h | >6 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python) |
| WEILAN Baby Alpha A2 | Standard | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 128GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Plus | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 256GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Pro | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 512GB storage, Premium Orange) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Ultra | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 1TB storage, Cyber Dream) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| MagicBot Z1 | Base | New | Bipedal humanoid (compact, high-dynamic; not a quadruped — the quadruped line is MagicDog) | ~140cm (Developer version 136.9 cm, 1369×422×200 mm) | ~40 (incl. battery) | 24 (base; expandable to 49/50 per different sources) | Max 3 kg per arm | ~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual) | ≥2.5m/s | Secondary development / OTA supported; official SDK magicbot-z1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
| MagicBot Gen1 | Base | New | Full-size general-purpose humanoid (nicknamed "Xiaomai") | 1740×580×280mm (174cm) | ~70 | 42 (active DOF) | 7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg) | 3–5 h (25Ah / 1.35kWh battery) | Official site ≥4 km/h; manual ≥2 m/s — sources differ | Secondary development / OTA supported; official SDK magicbot-gen1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
Vous avez trouvé votre modèle ?
Dites-nous le modèle et la quantité — nous confirmons prix, stock et délai, généralement sous 24 heures.
Demander un devis