产品
主线:Unitree、AgiBot、ENGINEAI——人形、四足、轮式机器人与机械臂,全新与二手。关节电机、关节模组与灵巧手也供应给自研机器人的团队。
价格按询盘确认——索取报价,我们确认价格、库存与交期,通常在 24 小时内。除了这里列出的型号,任何其他中国生产的机器人我们也能供应:您在找某个型号的话,告诉我们,我们帮您核查。
给美国访客的提示:面向美国我们只提供已获该市场准入的型号——向我们索取这份列表的美国版。
您需要哪一类?
人形机器人
双足人形机器人,用于科研、教育、展览与活动——全新与二手。关键参数见下方完整目录;向我们咨询适合您项目的版本。
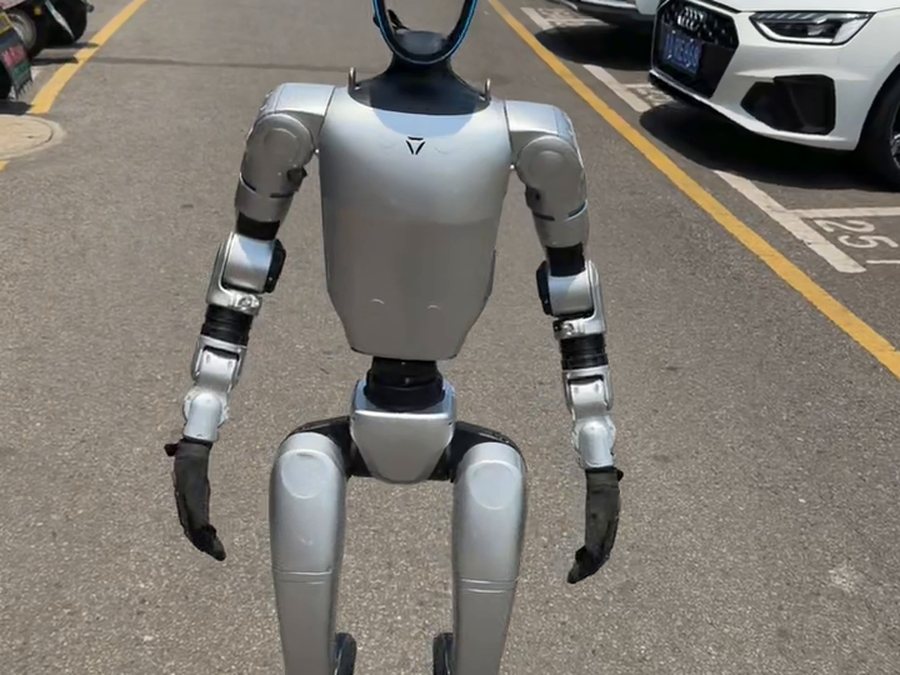
人形机器人是我们目录里走得最快的部分——全尺寸与紧凑型双足平台,供需要开发平台的实验室、需要教学机器人的学校、需要吸引人群的活动团队。大多数型号可供全新或二手;告诉我们机器人要做的工作,我们会指出合适的版本,并把参数差异讲清楚。
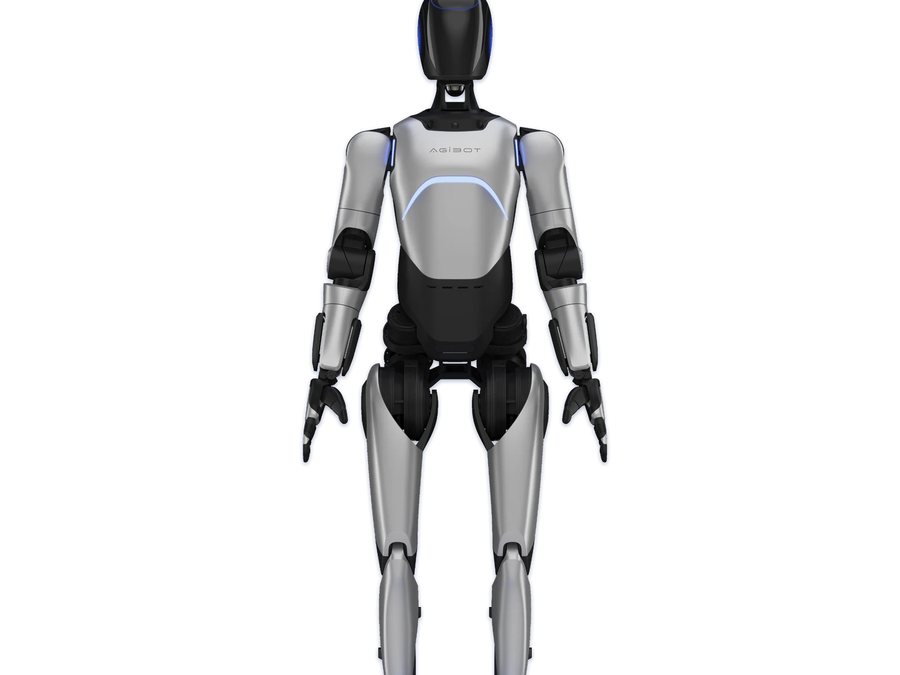
AgiBot A2
Young Edition / Flagship · 全新
- 尺寸169cm (169×75×30cm)
- 重量63 kg
- DOF23
- 负载~2 kg per arm
- 电池 / 续航Battery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet)
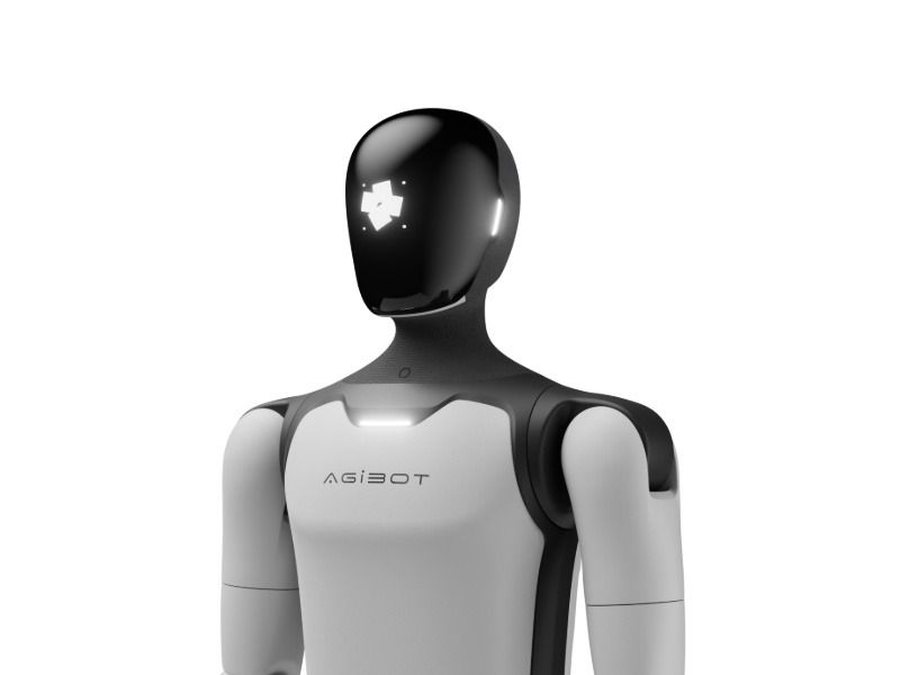
AgiBot A3
Basic Version / Development version · 全新
- 尺寸173cm (173×52×30cm)
- 重量55 kg
- DOF31 (active DOF)
- 负载5 kg per arm
- 电池 / 续航1152Wh dual battery; up to ~10 h in typical use (10-second battery swap)
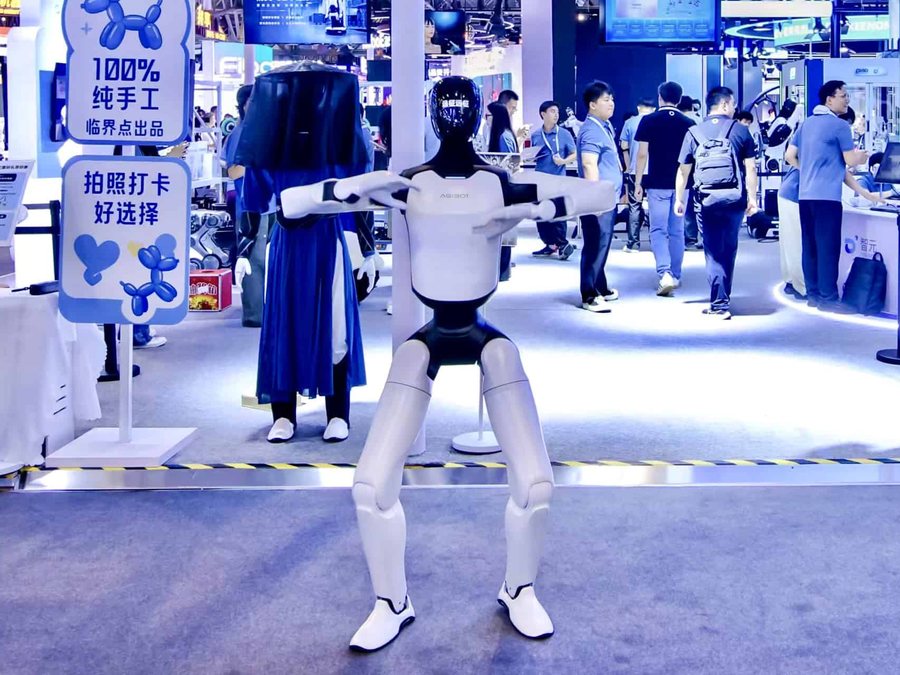
AgiBot A3 Ultra
Basic Version / Development version / Embodied version / EDU · 全新
- 尺寸174cm (174×52×30cm)
- 重量60 kg
- DOF51 (active DOF)
- 负载5 kg per arm
- 电池 / 续航1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap)
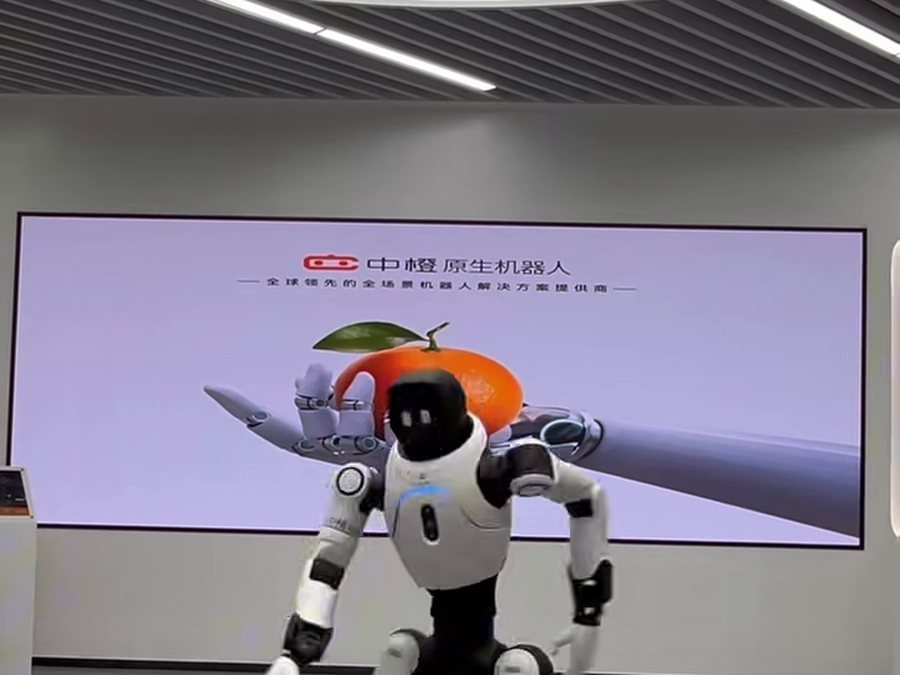
AgiBot X2
Basic Version / Ultra · 二手与全新
- 尺寸131cm (131×46×21cm)
- 重量35 kg
- DOF25
- 负载~3 kg in specific postures; ≤1 kg across full workspace
- 电池 / 续航~500Wh; ~2 h continuous walking (at 0.5 m/s)
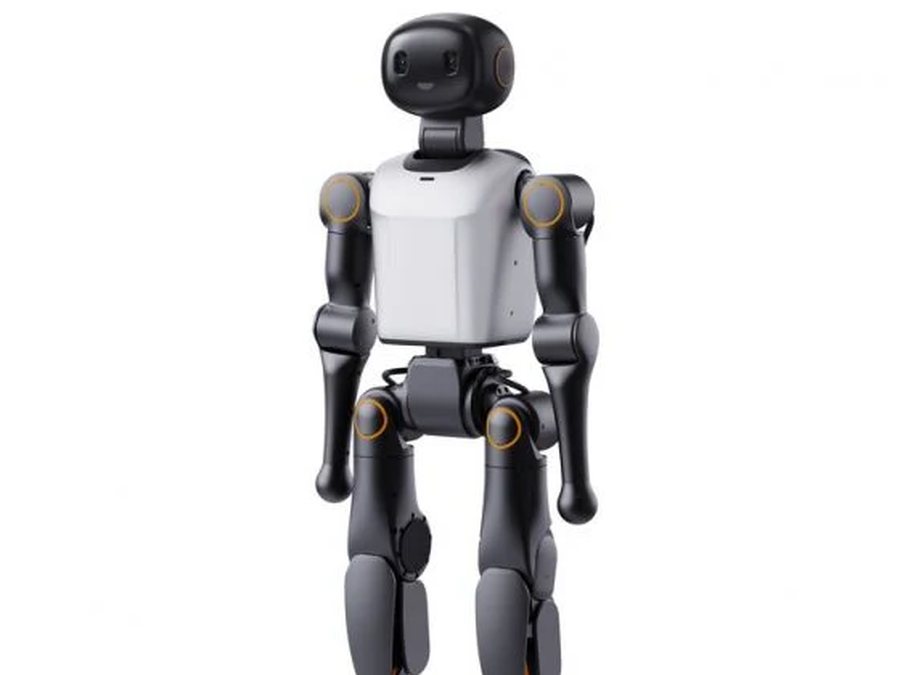
Booster K1
Geek / Education / Professional · 全新
- 尺寸~95cm
- 重量19.5 kg
- DOF22
- 电池 / 续航2Ah; ~20 min (official figure, walking at 1.1 m/s)
- 最高速度2 m/s (walking speed per official site)
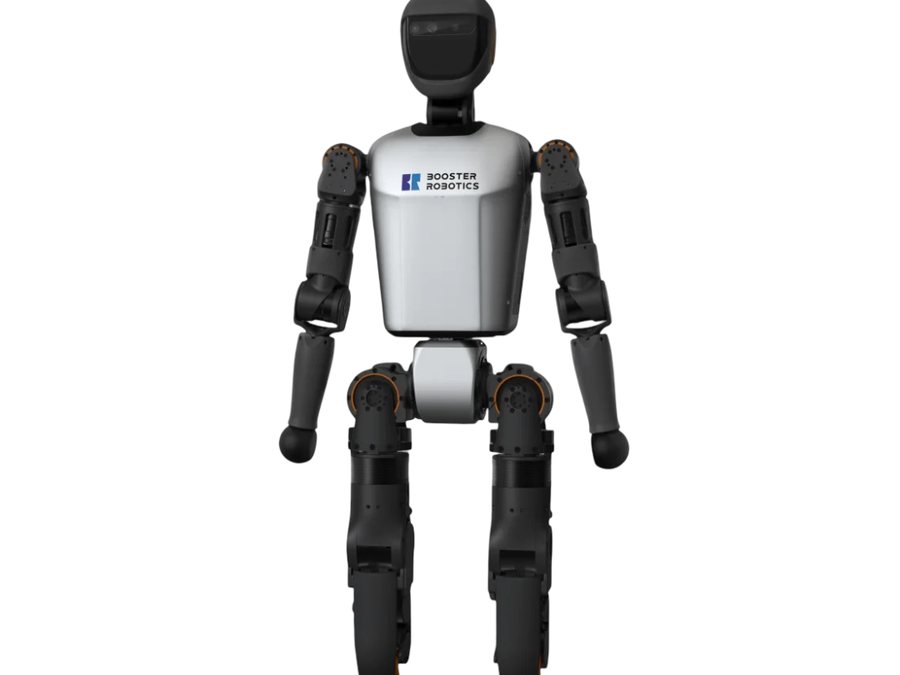
Booster T1
Basic / Standard / Customized · 全新
- 尺寸118cm (118×47×23cm)
- 重量30 kg
- DOF23
- 电池 / 续航10.5Ah battery; ~2 h walking, ~4 h standing
- 最高速度0.5 m/s (walking speed per manual; top speed not published)
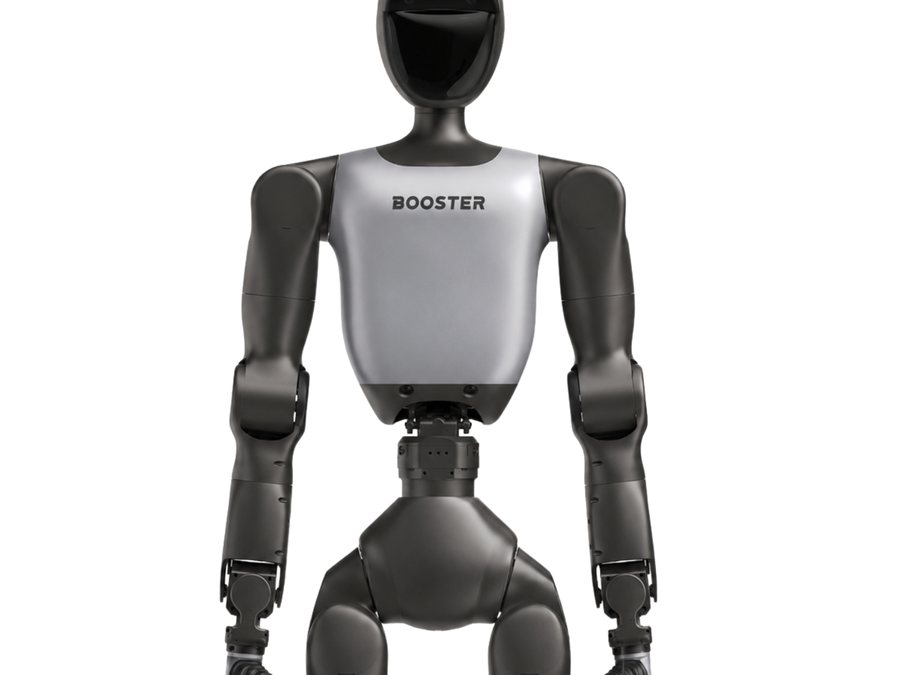
Booster T2
P1 / P2 Claw / P3 Nimble Hands · 全新
- 尺寸140cm
- 重量~42 kg
- DOF31
- 负载Max 10 kg both arms (base configuration, no end effector)
- 电池 / 续航48V 10Ah; ~2 h continuous walking
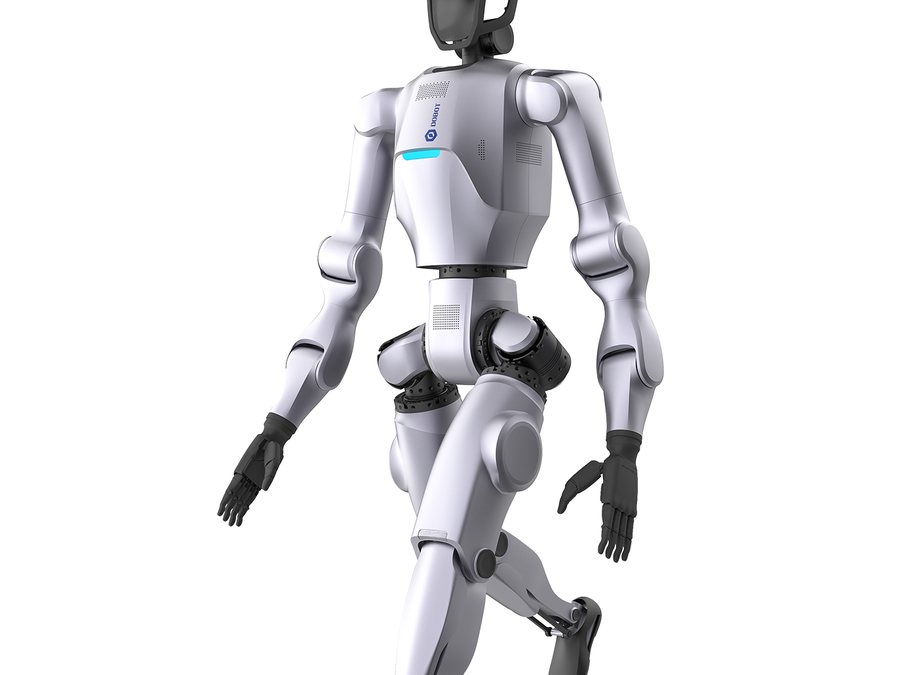
Dobot Atom
Base · 全新
- 尺寸Height ~1530mm
- 重量62 kg
- DOF41 (incl. dexterous hands; 29 without hands)
- 负载3.5 kg per arm
- 电池 / 续航~2 h
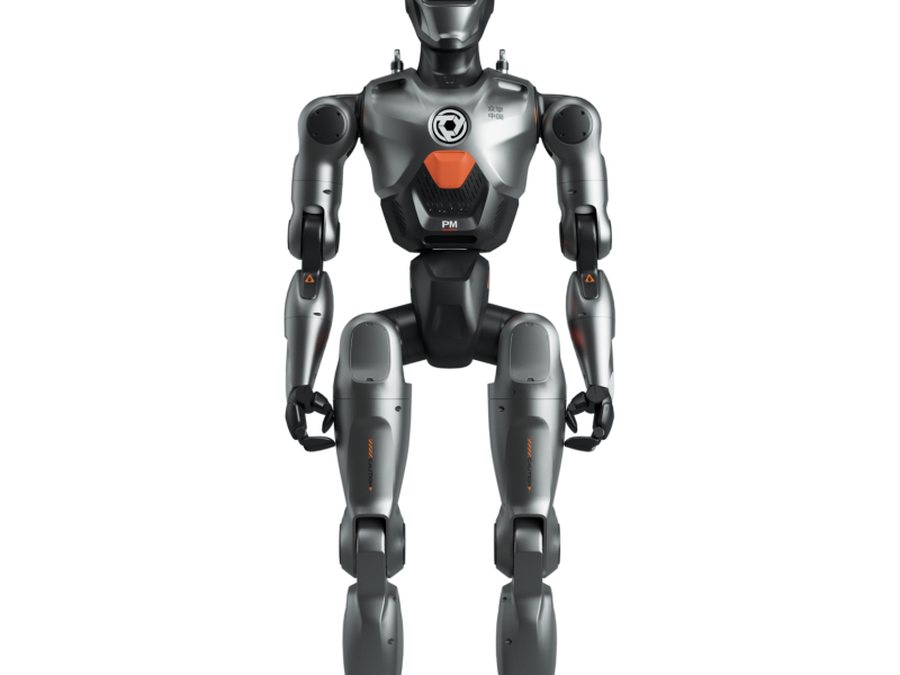
EngineAi PM01
Commercial / Education · 二手
- 尺寸138cm (manual: 1388×490×220 mm)
- 重量~40 (manual spec table ~43 incl. battery — sources differ)
- DOF23 (manufacturer headline says 24-DOF)
- 电池 / 续航~2 h (10,000mAh quick-release battery)
- 最高速度2m/s
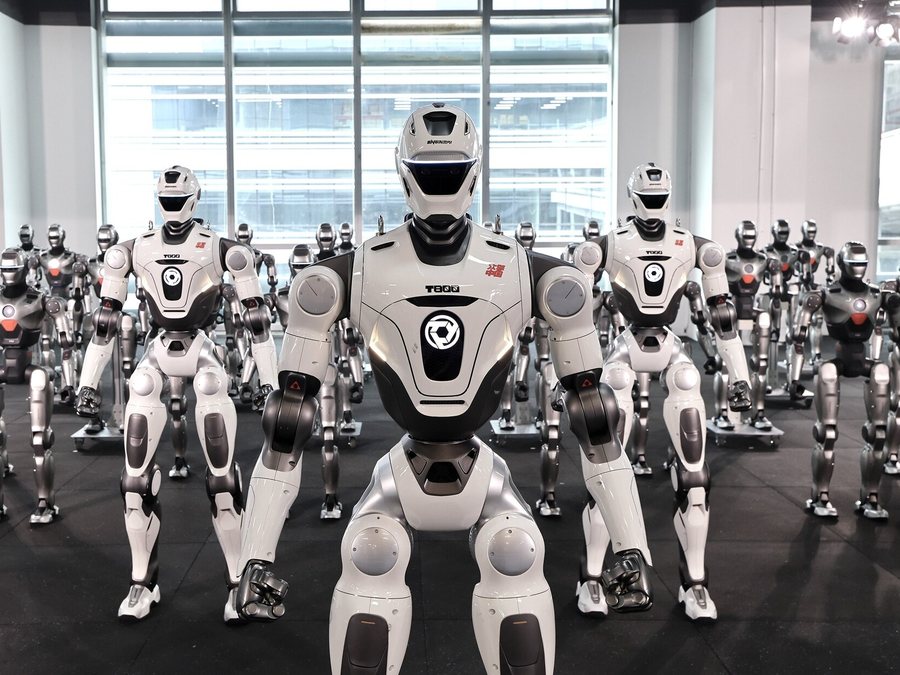
EngineAi T800
Base / Education / Pro · 全新
- 尺寸173cm (legs 91 cm, arms 60 cm)
- 重量75 (incl. battery, per launch materials)
- DOF25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands)
- 电池 / 续航4–5 h (solid-state battery, per manufacturer launch)
- 最高速度≥3 m/s (hardware-capable)
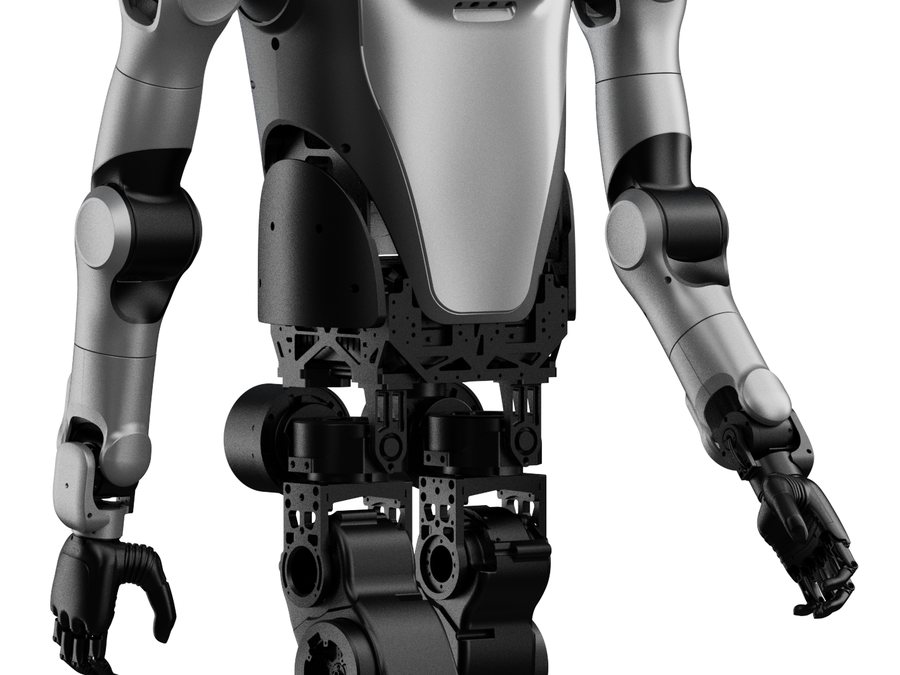
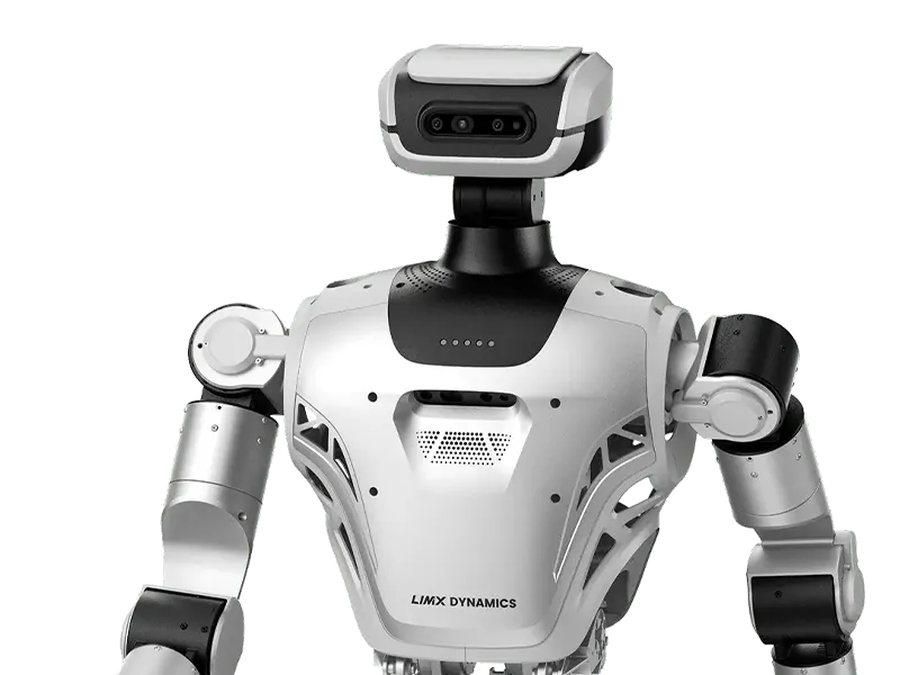
LimX Dynamics Oli
Lite / Edu / Super · 全新
- 尺寸165cm (shoulder width ≈55 cm, arm length ≈70 cm)
- 重量≤55 (incl. battery)
- DOF31 (body only, excl. end effectors)
- 电池 / 续航~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery)
- 最高速度Max walking speed 5 km/h
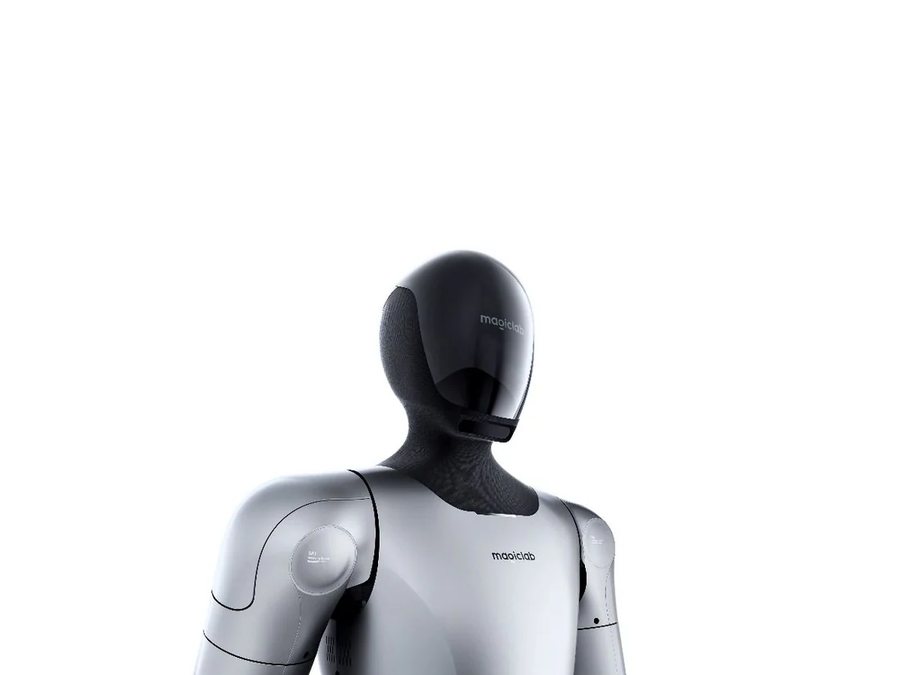
MagicBot Gen1
Base · 全新
- 尺寸1740×580×280mm (174cm)
- 重量~70 kg
- DOF42 (active DOF)
- 负载7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg)
- 电池 / 续航3–5 h (25Ah / 1.35kWh battery)
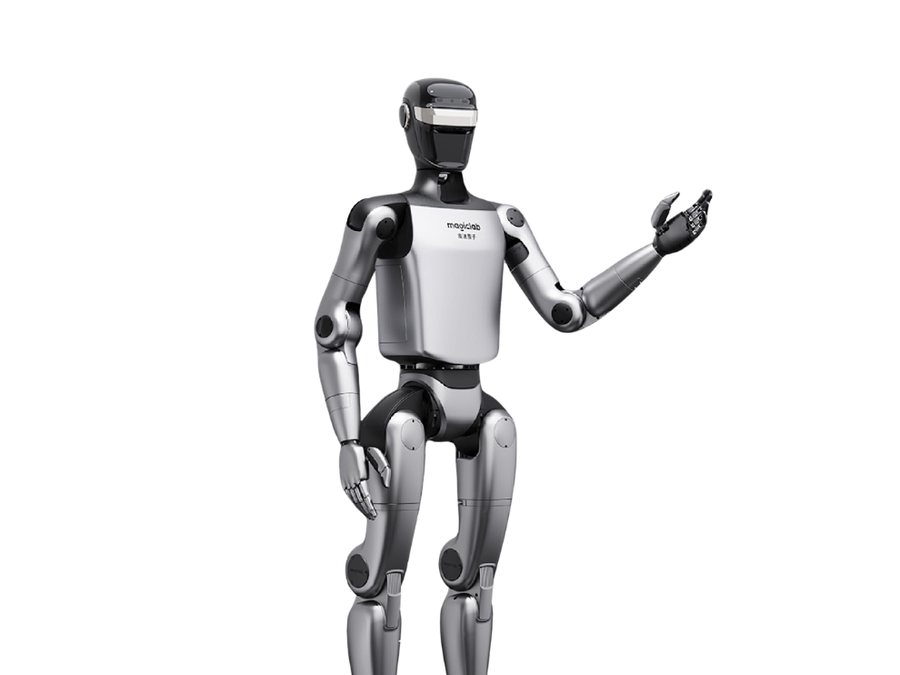
MagicBot Z1
Base · 全新
- 尺寸~140cm (Developer version 136.9 cm, 1369×422×200 mm)
- 重量~40 (incl. battery)
- DOF24 (base; expandable to 49/50 per different sources)
- 负载Max 3 kg per arm
- 电池 / 续航~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual)
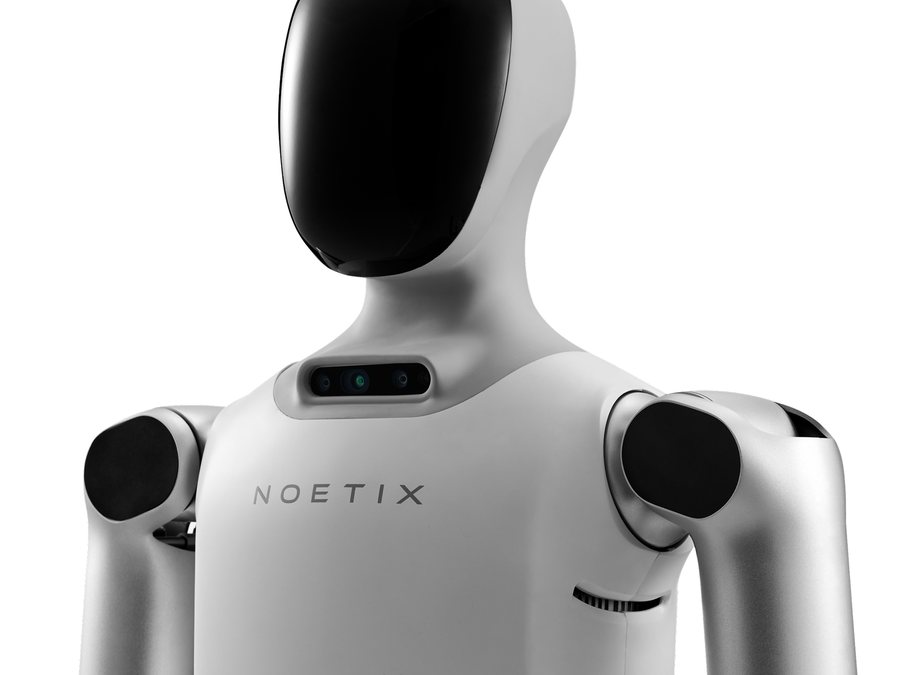
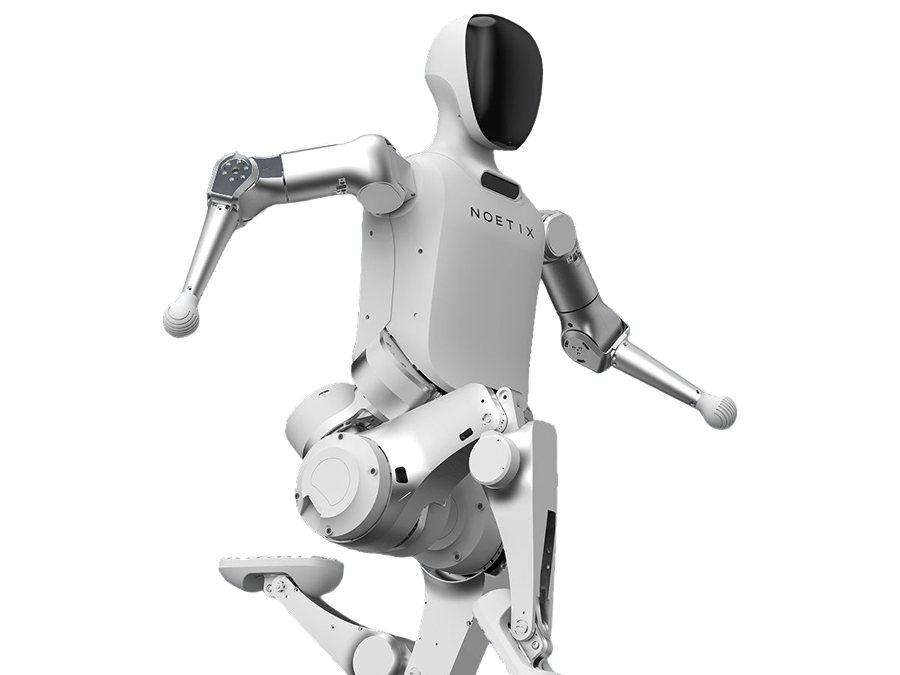
Noteix E1
Standard / Edu · 二手
- 尺寸136×47×29cm
- 重量~36 kg
- DOF23 (manufacturer manual) / 21 (press release) — sources conflict
- 电池 / 续航1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict
- 最高速度Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence)
Noteix N2
Standard / Edu · 二手
- 尺寸118 cm H × 47 cm W
- 重量~30 (another compilation lists 29)
- DOF18
- 负载~5 (carried while walking continuously)
- 电池 / 续航1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min)
四足机器人
四足平台,用于科研、巡检实践、教育与演示——全新与二手。
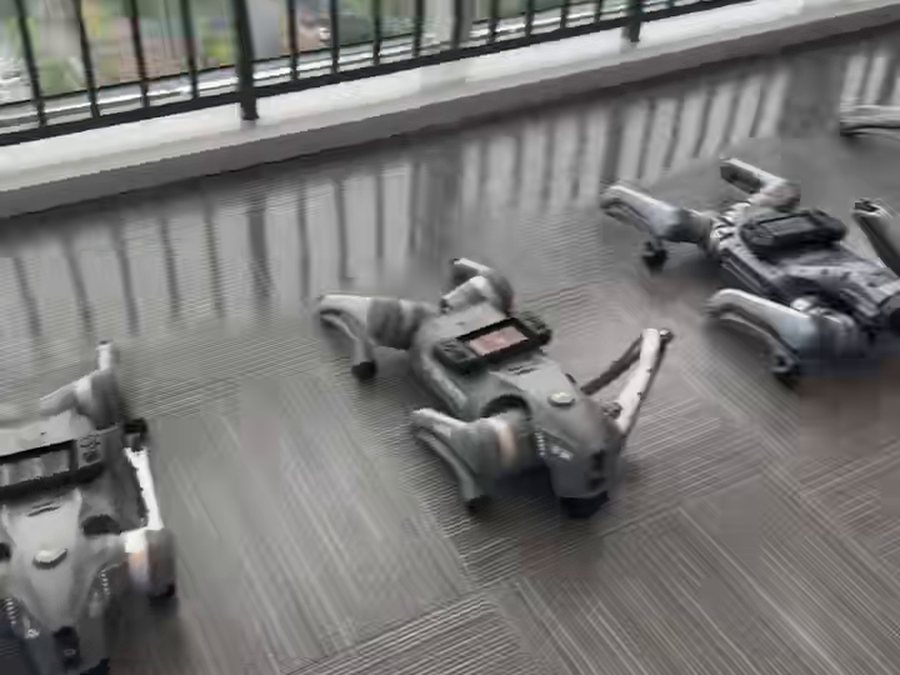
四足机器人用在轮子去不了的地方:楼梯、碎石、草地和破损地面。我们的四足产品线从紧凑型教育平台到工业巡检机,全新与二手均有。如果拿不准需要哪个尺寸级别,告诉我们地形和负载——这两点决定一切。
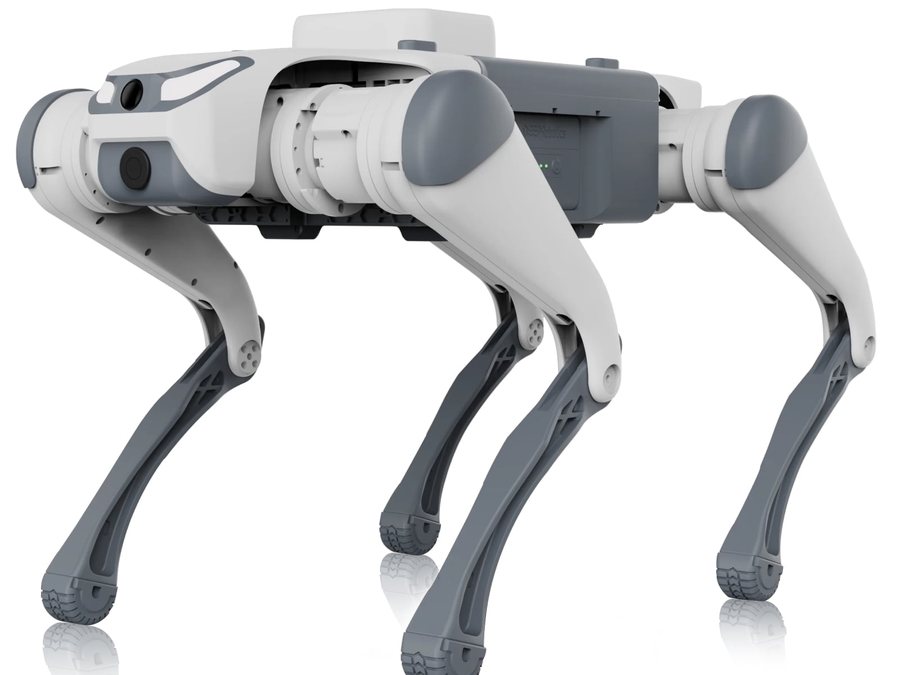
Deep Robotics Lite3
Basic / Venture / Pro / LiDAR · 二手与全新
- 尺寸Standing 610×370×406mm
- 重量12 kg
- DOF12
- 负载Walking payload 5
- 电池 / 续航1.5–2 h
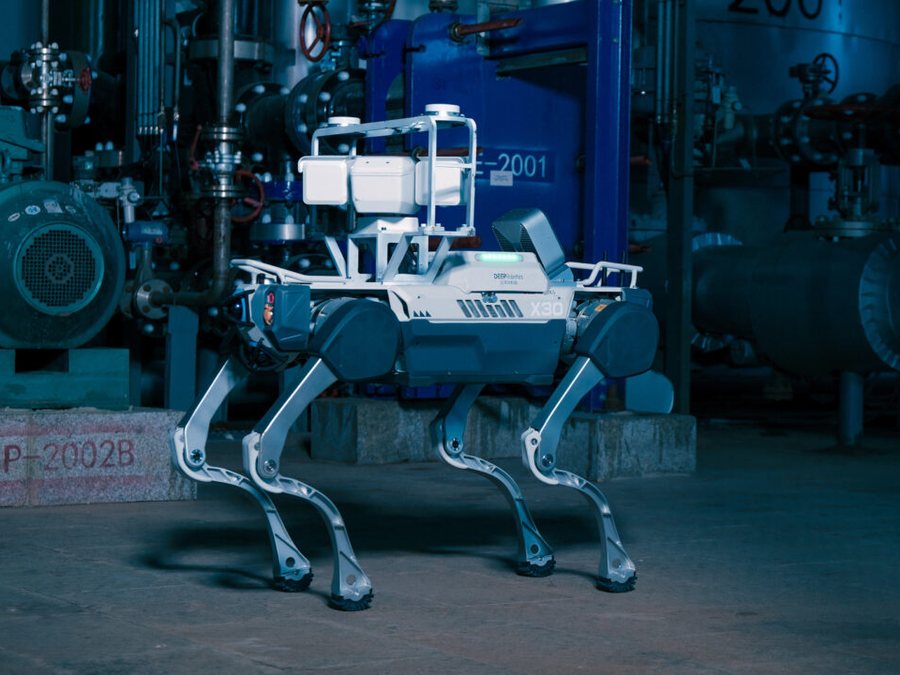
Deep Robotics X30
Basic / Pro · 二手
- 尺寸Standing 1000×585×470mm
- 重量56 kg
- DOF12
- 负载Rated payload ≥20 (max 85)
- 电池 / 续航2.5–4 h
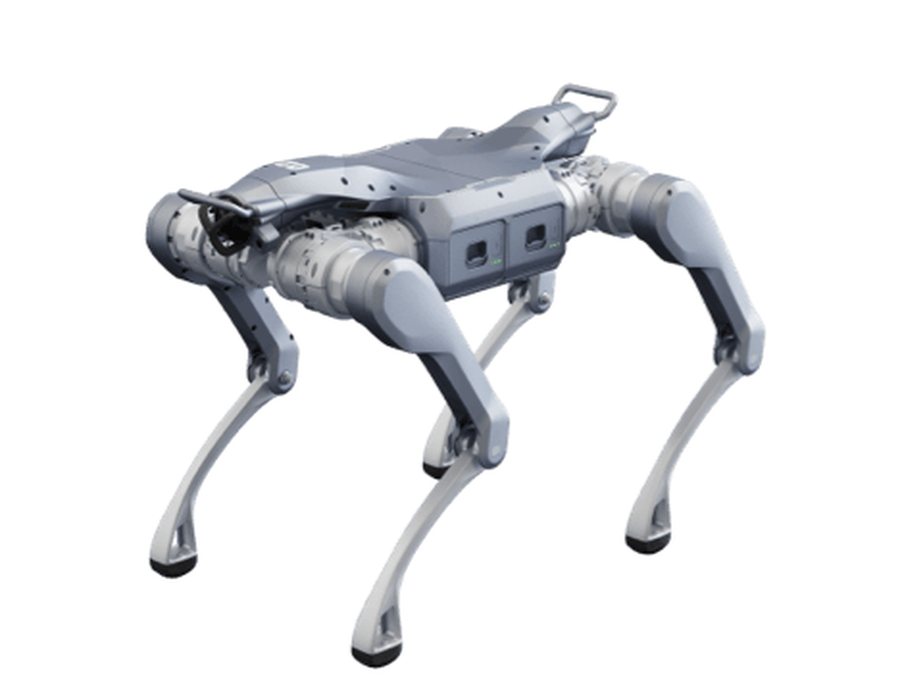
Unitree A2
Base · 全新
- 尺寸820×440×570mm
- 重量~37 (incl. dual batteries)
- DOF12
- 负载~25 (walking; standing max ~100)
- 电池 / 续航~5 h unloaded / ~3 h with 25 kg payload
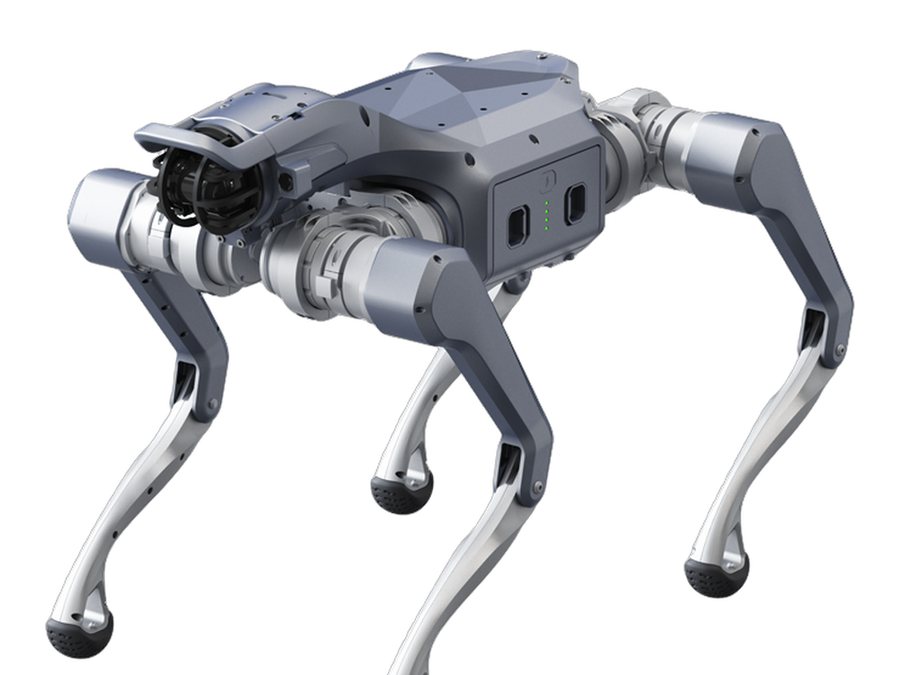
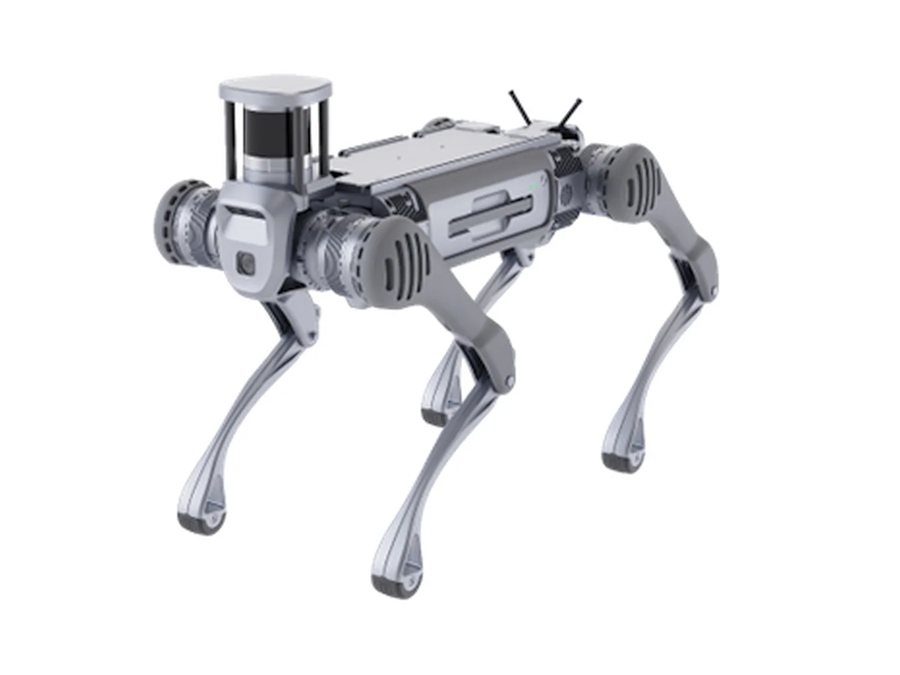
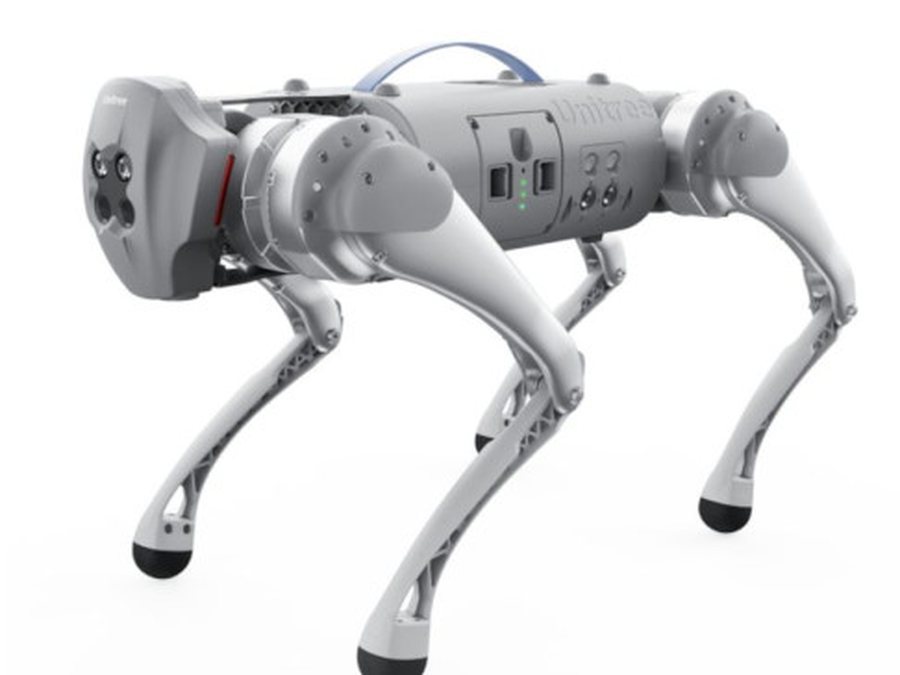
Unitree As2
EDU U1 / EDU U2 / EDU U3 / EDU U4 · 全新
- 重量18 kg
- DOF12
- 负载~15 (walking; standing max ~65)
- 电池 / 续航>4 h unloaded
- 最高速度3.7 m/s (peak 5)
Unitree Go2 Edu
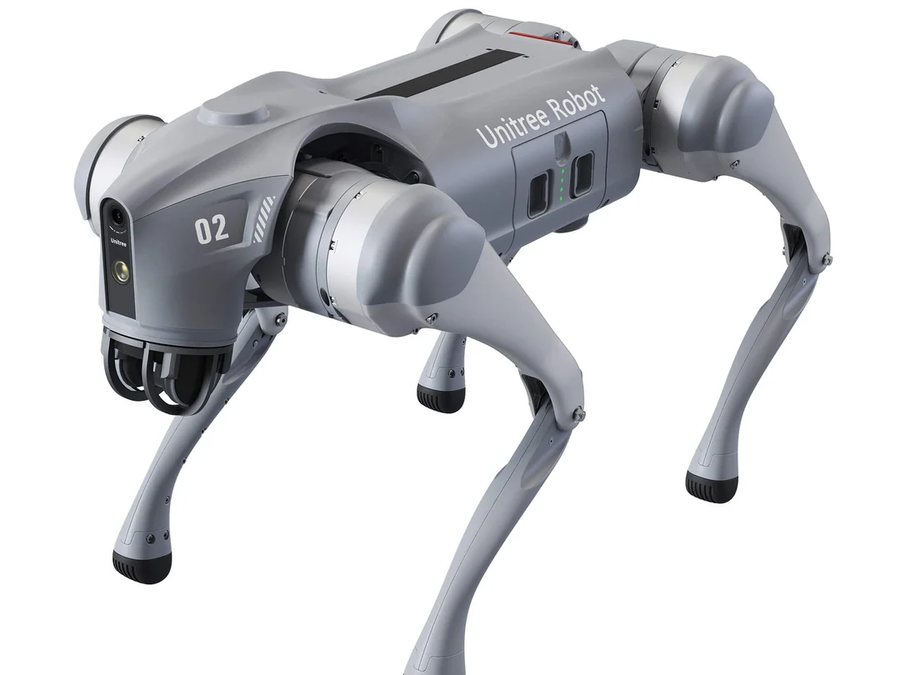
Base · 二手
- 尺寸700×310×400mm
- 重量15 kg
- DOF12
- 负载~8 (limit 10)
- 电池 / 续航~2–4 h (15,000mAh long-life battery)
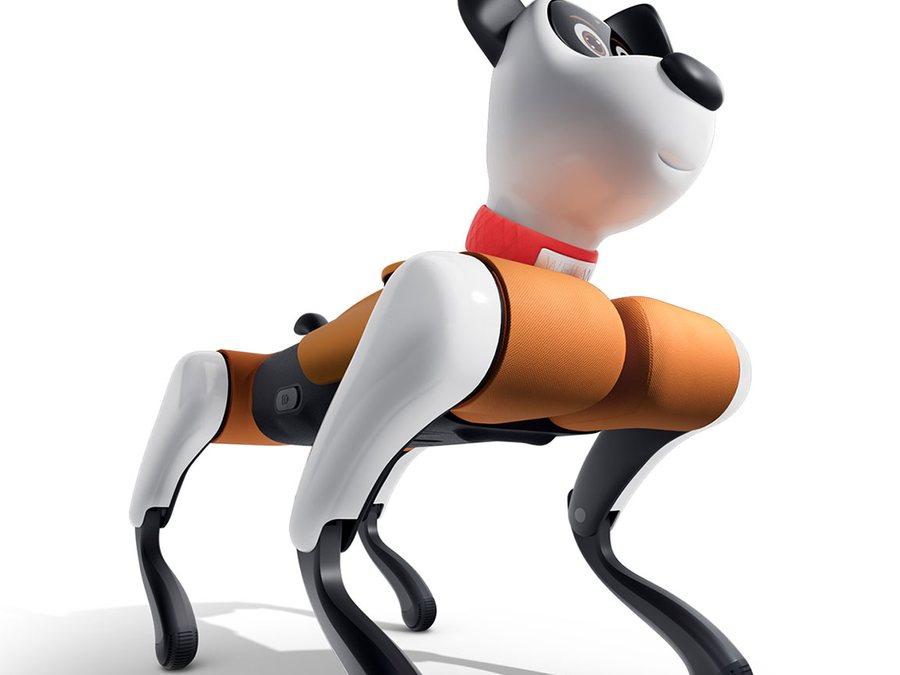
WEILAN Baby Alpha A2
Standard / Plus / Pro / Ultra · 二手
- 电池 / 续航~120 min (media report only; not published by manufacturer)
- 最高速度6.0 km/h (single media source, low–medium confidence)
轮式与轮足机器人
轮足四足机器人,在平地上滚动、能迈过障碍——用于轮子单独不够用的室内外工作。
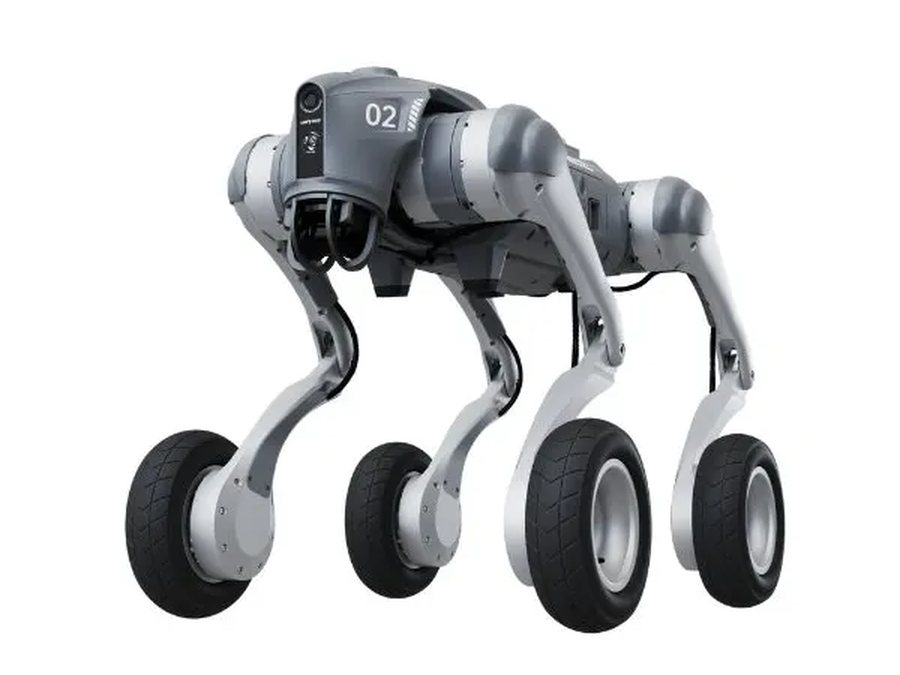
轮式与轮足机器人用一点越野能力换取速度、续航与稳定性,跑的是大多数场地实际有的地面——地板、场院、人行道和坡道。本区是我们的轮足四足机器人;如果您的场地以硬地面为主、偶有台阶或斜坡,从这里开始。
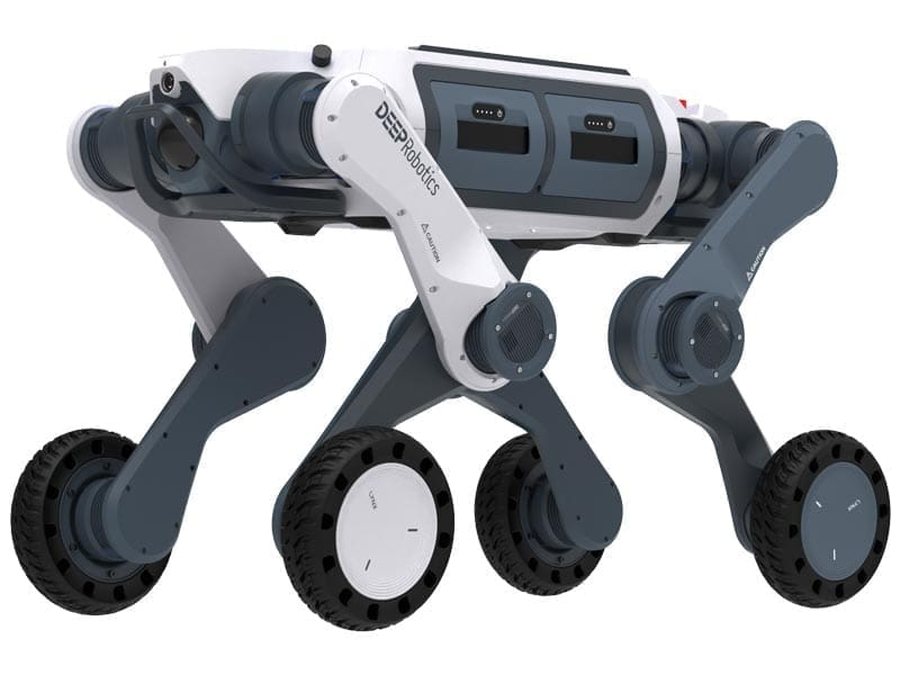
Deep Robotics M20
Basic / Pro · 全新
- 尺寸Standing 820×430×570mm
- 重量33 kg
- DOF16
- 负载Rated payload 15 (max 50)
- 电池 / 续航3 h unloaded / 2.5 h loaded
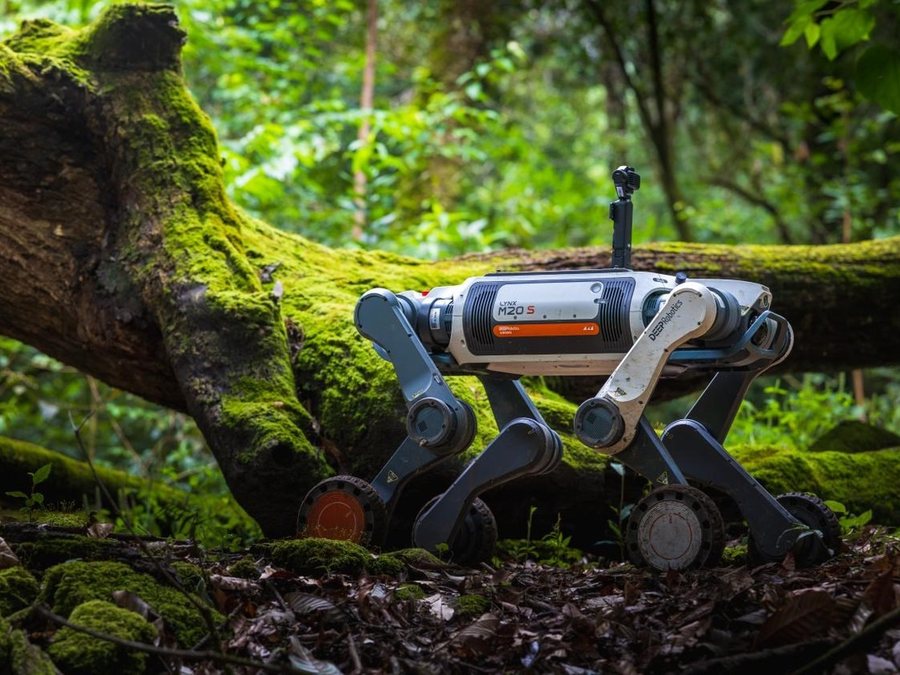
Deep Robotics M20S
New
- 重量33 (manufacturer states weight unchanged from M20 Pro)
- 负载Continuous payload 35 kg (flat terrain)
- 电池 / 续航3.5–5 h unloaded / 2.5–3.5 h loaded
- 最高速度9 m/s
Unitree Go2-W
Standard Edition / Smart Edition / Laser Edition · 全新
- 尺寸700×430×500mm
- 重量18 kg
- DOF16 (12 leg joints + 4 hub motors)
- 负载~8 (max ~12)
- 电池 / 续航~2–4 h
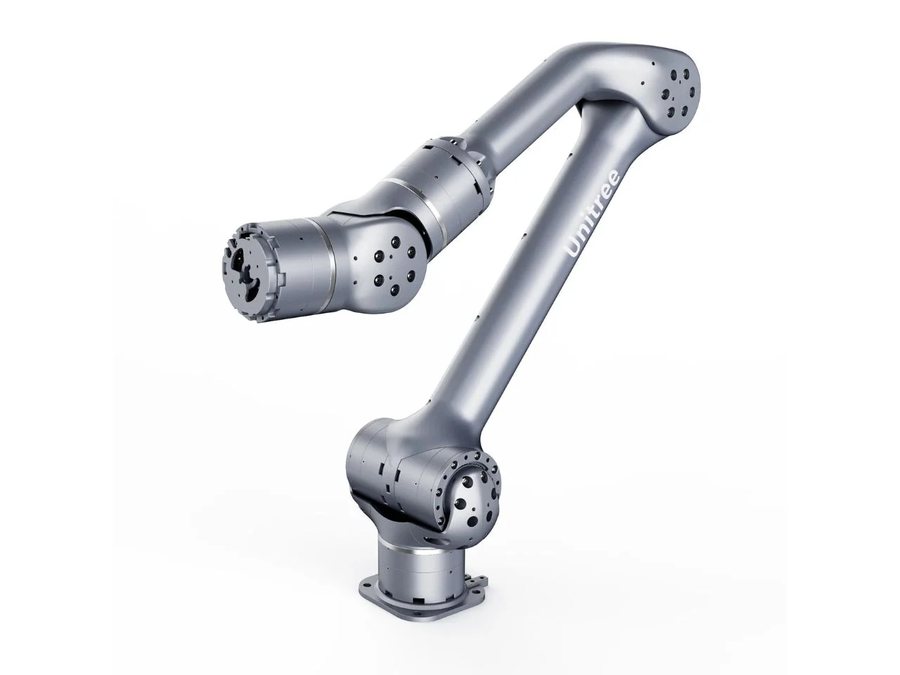
机械臂
用于人形与四足科研平台的机械臂,按您的机器人与负载需求匹配。
二手机器人
上面许多型号的二手版本都有库存——每台经过检验,附成色报告和那台实机的视频。
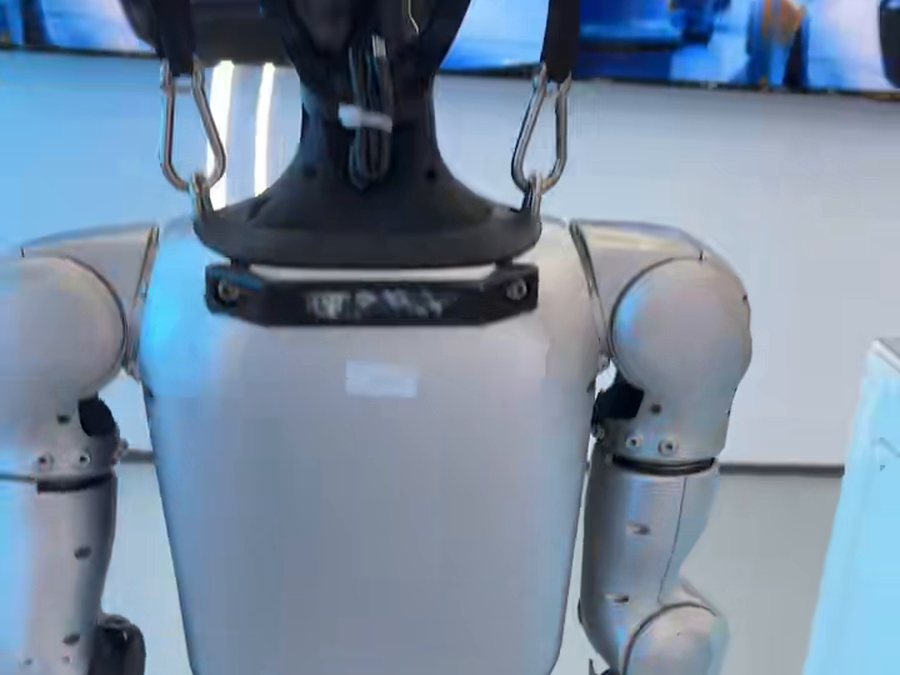
给机器人自研者的零部件
给自研机器人团队的独立产品线——是零部件,不是整机。
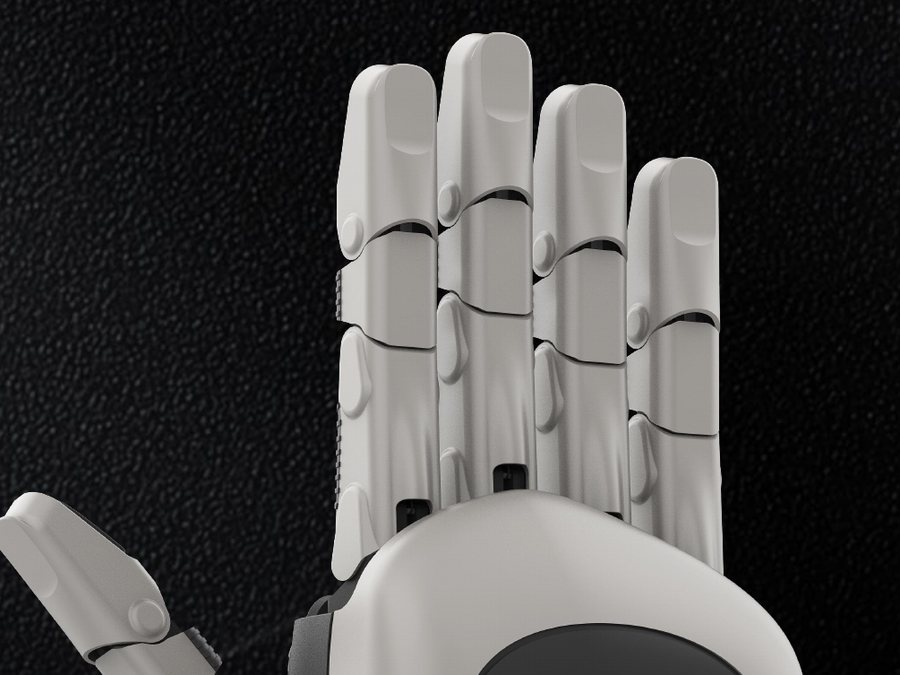
如果您的团队自研机器人,我们也供应装进它们里面的零部件:关节电机与关节模组、灵巧手——强脑 Revo 2 系列(Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 每支,本区唯一的标价)与灵巧智能 DexHand 021 和 DexHand 021 S(价格待确认)——还有机械臂、电池与控制器。告诉我们需要的类型、规格与数量——我们逐项报价。
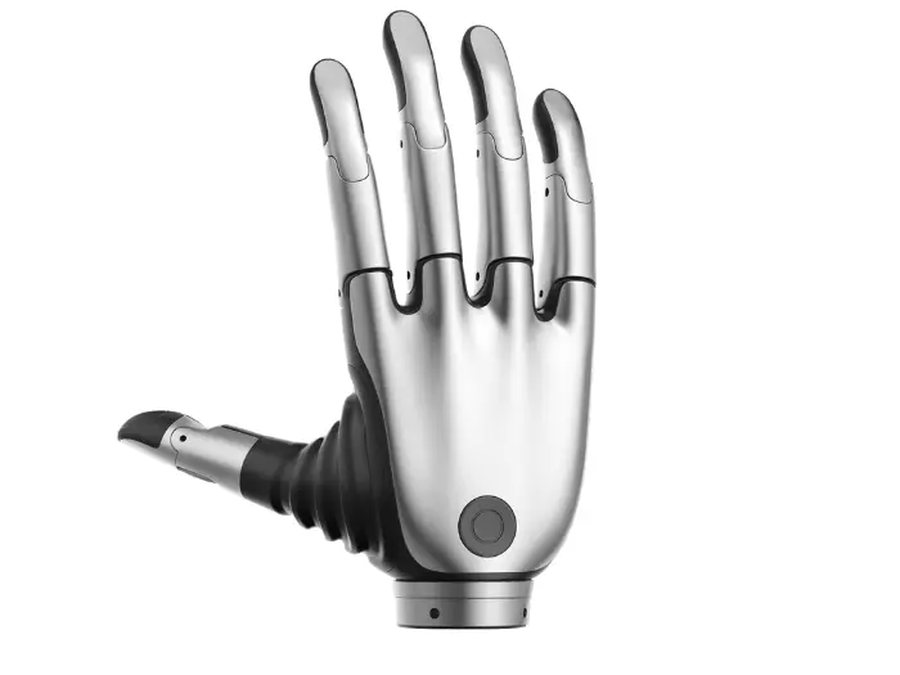
灵巧手——Revo 2
Revo 2 系列灵巧手:Basic USD 3,000 / Pro USD 3,700 / Touch USD 5,200 每支。其他灵巧手也有——把您的规格发给我们。
附参数的完整型号列表
我们目前供应的全部型号,附关键参数。状态一列说明所列版本是全新还是二手;许多型号两者都有——问我们即可。您也可以下载这份列表(Excel)。
| 型号 | 版本 | 状态 | 类型 | 尺寸 | 重量 (kg) | 自由度 | 负载 (kg) | 电池 / 续航 | 最高速度 | 开发支持 |
|---|---|---|---|---|---|---|---|---|---|---|
| AgiBot A2 | Young Edition | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 63 | 23 | ~2 kg per arm | Battery 14.4Ah; ~2 h walking, ~4.5 h standing (dealer spec sheet) | Max walking 0.8 m/s (dealer spec sheet) | AimMaster/AimDK choreography and interaction customization tools (performance & presentation use); full low-level SDK openness not clearly stated by the manufacturer |
| AgiBot A2 | Flagship | New | Humanoid (bipedal) | 169cm (169×75×30cm) | 69 | 40+ (active DOF) | ~3 kg per arm | 700Wh; ~2 h (hot-swappable battery) | Max walking 1.2 m/s (after V1.3 OTA update) | Secondary development supported: AimDK (HTTP JSON-RPC + ROS2 Topic interfaces, AimRT framework) |
| AgiBot X2 | Basic Version | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 35 | 25 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh; ~2 h continuous walking (at 0.5 m/s) | 1.8m/s | No secondary development (no public SDK, locked system; development open on Ultra only) |
| AgiBot X2 | Ultra | New | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) |
| AgiBot X2 | Ultra | Used | Humanoid (bipedal) | 131cm (131×46×21cm) | 39 | 30 | ~3 kg in specific postures; ≤1 kg across full workspace | ~500Wh (product page) / ~421Wh (SDK docs); ~2 h continuous walking (pre-owned unit; hardware identical to new) | 1.8m/s | Secondary development supported: AimDK SDK (ROS2-based, Python/C++ APIs), NVIDIA Orin NX dev board (157 TOPS) (pre-owned unit; hardware identical to new) |
| AgiBot A3 | Basic Version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (AimDK development only on the Development version) |
| AgiBot A3 | Development version | New | Humanoid (bipedal) | 173cm (173×52×30cm) | 55 | 31 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~10 h in typical use (10-second battery swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open AimDK development SDK (HTTP JSON-RPC + ROS2 Topic interfaces) |
| AgiBot A3 Ultra | Basic Version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Basic version: SDK not open (Open SDK + ROS2 only on Development/EDU versions) |
| AgiBot A3 Ultra | Development version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK), full development documentation included |
| AgiBot A3 Ultra | Embodied version | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | No separate official statement found on this version's software entitlements (hardware as A3 Ultra) |
| AgiBot A3 Ultra | EDU | New | Humanoid (bipedal) | 174cm (174×52×30cm) | 60 | 51 (active DOF) | 5 kg per arm | 1152Wh dual battery; up to ~8 h (walking/standing 1:1, 10-second swap) | Max 1.8 m/s everyday walking (2.5 m/s lab max) | Open SDK + ROS2 interfaces (AimDK); education/research software and support package |
| Booster K1 | Geek | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 2Ah; ~20 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (this version: 48 TOPS compute) |
| Booster K1 | Education | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~80 min | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (117 TOPS, Jetson Orin NX) |
| Booster K1 | Professional | New | Humanoid (bipedal) | ~95cm | 19.5 | 22 | Not published | 5Ah; ~70 min (official figure, walking at 1.1 m/s) | 2 m/s (walking speed per official site) | Secondary development supported: BoosterOS Python/C++ SDK, ROS2 (200 TOPS, Jetson AGX Orin) |
| Booster T1 | Basic | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); no Intel host on this version (AGX Orin 200 TOPS only). Note: one third-party database claims the Basic version lacks SDK support, contradicting official developer docs — confirm with the manufacturer before ordering |
| Booster T1 | Standard | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 23 | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); AGX Orin 200 TOPS + Intel i7-1370P host |
| Booster T1 | Customized | New | Humanoid (bipedal) | 118cm (118×47×23cm) | 30 | 31 (gripper version) / 41 (dexterous-hand version) | Not published | 10.5Ah battery; ~2 h walking, ~4 h standing | 0.5 m/s (walking speed per manual; top speed not published) | Secondary development supported (BoosterOS Python/C++ SDK, ROS2); 7-DOF arms, optional gripper or 6-DOF dexterous hands; compute as Standard |
| Booster T2 | P1 | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (base configuration, no end effector) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P2 Claw | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (standard gripper configuration) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Booster T2 | P3 Nimble Hands | New | Humanoid (bipedal) | 140cm | ~42 | 31 | Max 10 kg both arms (6-DOF dexterous hands) | 48V 10Ah; ~2 h continuous walking | 2m/s | Secondary development supported: Booster Studio platform + BoosterOS Python SDK, ROS2 interfaces (Jetson Thor T5000, 2070 TFLOPS) |
| Deep Robotics Lite3 | Basic | New | Quadruped | Standing 610×370×406mm | 12 | 12 | Walking payload 5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Venture | Used | Quadruped | Standing 610×370×445mm | 12.2 | 12 | Walking payload 4.5 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | Pro | Used | Quadruped | Standing 610×370×450mm | 12.9 | 12 | Walking payload 4 | 1.5–2 h | 4 m/s | Motion development SDK/API and perception development interfaces (ROS1/ROS2 secondary development) |
| Deep Robotics Lite3 | LiDAR | Used | Quadruped | Standing 610×370×496mm | 13.5 | 12 | Walking payload 2.5 | 1.5–2 h | 4 m/s | Motion control SDK, perception development sample code and communication protocols (ROS1/ROS2) |
| Deep Robotics M20 | Basic | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Business development interfaces (Gigabit Ethernet, 72V power interface) |
| Deep Robotics M20 | Pro | New | Quadruped (wheeled-leg) | Standing 820×430×570mm | 33 | 16 | Rated payload 15 (max 50) | 3 h unloaded / 2.5 h loaded | 5 m/s (limit test; max working speed 2 m/s) | Secondary development supported (Gigabit Ethernet, USB 3.0, 24V/72V power interfaces, SLAM mapping & navigation) |
| Deep Robotics X30 | Basic | Used | Quadruped | Standing 1000×585×470mm | 56 | 12 | Rated payload ≥20 (max 85) | 2.5–4 h | ≥4 m/s | Secondary development supported |
| Deep Robotics X30 | Pro | Used | Quadruped | Standing 1000×585×470mm | 59 | 12 | 20 (max 85) | 4 h unloaded / 2.5 h loaded | ≥4 m/s | Secondary development supported (industrial-grade SDK interfaces) |
| Deep Robotics M20S | — | New | Quadruped (wheeled-leg) | Not published | 33 (manufacturer states weight unchanged from M20 Pro) | Not published | Continuous payload 35 kg (flat terrain) | 3.5–5 h unloaded / 2.5–3.5 h loaded | 9 m/s | Not published |
| Dobot Atom | Base | New | Humanoid | Height ~1530mm | 62 | 41 (incl. dexterous hands; 29 without hands) | 3.5 kg per arm | ~2 h | 1.5 m/s (walking) | SDK secondary development supported (official SDK development guide available) |
| EngineAi PM01 | Commercial | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | No secondary development (manufacturer manual lists openness as "not supported"); the manufacturer also publishes EngineAI ROS (ROS2-based) open resources |
| EngineAi PM01 | Education | Used | Humanoid (bipedal, general-purpose embodied agent) | 138cm (manual: 1388×490×220 mm) | ~40 (manual spec table ~43 incl. battery — sources differ) | 23 (manufacturer headline says 24-DOF) | Not published | ~2 h (10,000mAh quick-release battery) | 2m/s | Open platform: x86 + NVIDIA Jetson Orin dual chips, open training/deployment code, secondary development supported; ROS2 (EngineAI ROS framework); native SDK (pm01_edu) via GitHub mirror, not directly from the official site |
| EngineAi T800 | Base | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery, per launch materials) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | No secondary development |
| EngineAi T800 | Education | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75 (incl. battery; dealers cite 75–85 depending on version) | 25 (per dealer tier data; manufacturer headline 29-DOF excl. dexterous hands) | Not published (no dexterous hands on this version) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported (official Eco/open-source edition ≈ this Education version: stereo vision/LiDAR + AGX Orin 64G); dedicated official T800 SDK documentation not found |
| EngineAi T800 | Pro | New | Humanoid (full-size, general-purpose) | 173cm (legs 91 cm, arms 60 cm) | 75–85 (varies by version, per dealers) | 43 (29 body + 7×2 hands) | Dexterous hand 5 kg per hand (whole-body / per-arm payload not published) | 4–5 h (solid-state battery, per manufacturer launch) | ≥3 m/s (hardware-capable) | Secondary development supported |
| Leju Robotics Kuavo 4Pro | Base | New | Humanoid | Height ~1660mm | 55 | 40+ | Not published | Not published | >7 km/h (running) | Fully open motion-control and application development interfaces (open-source HarmonyOS) |
| LimX Dynamics Oli | Lite | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors) | Not published (same-series EDU/Super: max 3 kg per arm; no per-variant data for Lite) | ~1.5 h (series figure; no per-variant data for Lite; 9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| LimX Dynamics Oli | Edu | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 31 (body only, excl. end effectors; RobotShop lists 33 — unconfirmed) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development (plus C++/JavaScript examples); ROS2 (official GitHub); Isaac Sim/MuJoCo/Gazebo support |
| LimX Dynamics Oli | Super | New | Full-size general-purpose humanoid | 165cm (shoulder width ≈55 cm, arm length ≈70 cm) | ≤55 (incl. battery) | 33 (body only, excl. end effectors) | Max 3 kg per arm | ~1.5 h (9,500mAh quick-swap battery) | Max walking speed 5 km/h | Modular SDK + open high-/low-level APIs + full URDF; all-Python development; ROS2 (official GitHub: humanoid-rl-deploy-ros2); Isaac Sim/MuJoCo/Gazebo simulation support |
| Noteix N2 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | No secondary development; no official ROS2/Python statement found |
| Noteix N2 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 118 cm H × 47 cm W | ~30 (another compilation lists 29) | 18 | ~5 (carried while walking continuously) | 1–2 h (48V quick-swap battery; Chinese launch reports say 70–80 min) | 3.2 m/s (running; Chinese reports cite 3.5 m/s peak) | Secondary development supported (adds NVIDIA Jetson Orin Nano Super compute, depth camera; optional spherical hands / five-finger hands); no official ROS2/Python statement found |
| Noteix E1 | Standard | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Base compute 6 TOPS (RK3588s); no open-SDK statement found; no official ROS2/Python statement found |
| Noteix E1 | Edu | Used | Bipedal humanoid (brand correctly spelled Noetix; listed as "Noteix" in the price list) | 136×47×29cm | ~36 | 23 (manufacturer manual) / 21 (press release) — sources conflict | Not published | 1–2 h (press release) / >2 h (manual, 48V 9Ah quick-swap lithium battery) — sources conflict | Walking 1.2 m/s (press release); manual claims running up to >3.5 m/s (extraction incomplete, low confidence) | Open SDK interfaces (velocity/motion commands and joint-level algorithm control), 6+67 TOPS compute (adds Jetson Orin Nano Super, depth camera); no official ROS2/Python statement found |
| Unitree G1 | Basic | Used | Humanoid | 1320×450×200mm (Standing ) | 35 | 23 | ~2 (per arm) | ~2 h | 2 m/s | No secondary development (no SDK; remote control / app demos only) |
| Unitree G1 | U1 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Jetson Orin compute module) |
| Unitree G1 | U2 | Used | Humanoid | 1320×450×200mm (Standing ) | ~35 | 23 (expandable) | ~3 (per arm) | ~2 h | 2 m/s | Secondary development supported (EDU version: unitree_sdk2 / ROS2 / Python, Orin NX 100 TOPS) |
| Unitree H2 | Basic | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | No official secondary-development support found (only the EDU version explicitly supports it) |
| Unitree H2 | EDU | New | Humanoid | ~182cm | 70 | 31 | ~7 (peak 21) | ~3 h | Not published | Secondary development supported (EDU version; compute module customizable) |
| Unitree Go1 Air | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1 h | 2.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go1 Pro | Base | Used | Quadruped | 645×280×400mm | 12 | 12 | ~3 | ~1.5 h | 3.5 m/s | Not supported (no research programming API / Python; graphical programming only) |
| Unitree Go2 Air | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 2.5 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Pro | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~7 (max ~10) | ~1–2 h | 3.7 m/s | No secondary development (app / graphical programming only) |
| Unitree Go2 Edu | Base | Used | Quadruped | 700×310×400mm | 15 | 12 | ~8 (limit 10) | ~2–4 h (15,000mAh long-life battery) | 3.7 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python; optional Jetson Orin expansion dock) |
| Unitree Go2-W | Standard Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Smart Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree Go2-W | Laser Edition | New | Wheeled-leg quadruped | 700×430×500mm | 18 | 16 (12 leg joints + 4 hub motors) | ~8 (max ~12) | ~2–4 h | 2.5 m/s | Secondary development supported (SDK; the three editions differ in compute dock / LiDAR configuration, not listed separately by the manufacturer) |
| Unitree A2 | Base | New | Quadruped | 820×440×570mm | ~37 (incl. dual batteries) | 12 | ~25 (walking; standing max ~100) | ~5 h unloaded / ~3 h with 25 kg payload | 3.7 m/s (up to ~5) | Secondary development supported (Intel i7 development compute, ROS/ROS2) |
| Unitree As2 | EDU U1 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U2 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U3 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree As2 | EDU U4 | New | Quadruped | Not published (full dimensions not released) | 18 | 12 | ~15 (walking; standing max ~65) | >4 h unloaded | 3.7 m/s (peak 5) | Secondary development supported (EDU open platform; U1–U4 tier differences not published by the manufacturer) |
| Unitree B2 | Base | Used | Quadruped | ~1098×450×645mm | ~60 | 12 | Walking >40 (standing max 120) | ~4–6 h | >6 m/s | Secondary development supported (unitree_sdk2 / ROS2 / Python) |
| WEILAN Baby Alpha A2 | Standard | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 128GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Plus | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 256GB storage, Starlight White) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Pro | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 512GB storage, Premium Orange) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| WEILAN Baby Alpha A2 | Ultra | Used | Consumer quadruped robot dog (home companion AI pet bot) | Not published (this version: 1TB storage, Cyber Dream) | Not published | Not published | Not published | ~120 min (media report only; not published by manufacturer) | 6.0 km/h (single media source, low–medium confidence) | Consumer product; no public motion-control SDK (motion SDK only on the Dev series); the A series offers agentos_sdk for voice/vision/smart-app development only |
| MagicBot Z1 | Base | New | Bipedal humanoid (compact, high-dynamic; not a quadruped — the quadruped line is MagicDog) | ~140cm (Developer version 136.9 cm, 1369×422×200 mm) | ~40 (incl. battery) | 24 (base; expandable to 49/50 per different sources) | Max 3 kg per arm | ~2 h (10,000mAh quick-release; aggregated/media sources, not stated in manual) | ≥2.5m/s | Secondary development / OTA supported; official SDK magicbot-z1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |
| MagicBot Gen1 | Base | New | Full-size general-purpose humanoid (nicknamed "Xiaomai") | 1740×580×280mm (174cm) | ~70 | 42 (active DOF) | 7.5 kg per arm; whole-body static 40 kg; both-arms carrying 15 kg (media also cite 20 kg) | 3–5 h (25Ah / 1.35kWh battery) | Official site ≥4 km/h; manual ≥2 m/s — sources differ | Secondary development / OTA supported; official SDK magicbot-gen1_sdk (GitHub, incl. URDF/MJCF); no explicit ROS2/Python statement found |